Labs, companies, and the things that shipped

Experience

Five robotics labs and the projects that came out of each, and the companies I have built things in — cinema robotics, a logistics startup, an LLM product team, a display-tech lab, a shipyard, and a design-tools ambassadorship.

Research Experience

Five labs, and the projects that came out of each
Space & Terrestrial Autonomous Robotic Systems Lab Ph.D. Researcher — Prof. Jonathan Kelly University of Toronto Institute for Aerospace Studies · Toronto Sep 2021 – Aug 2025Sep 2026 – present
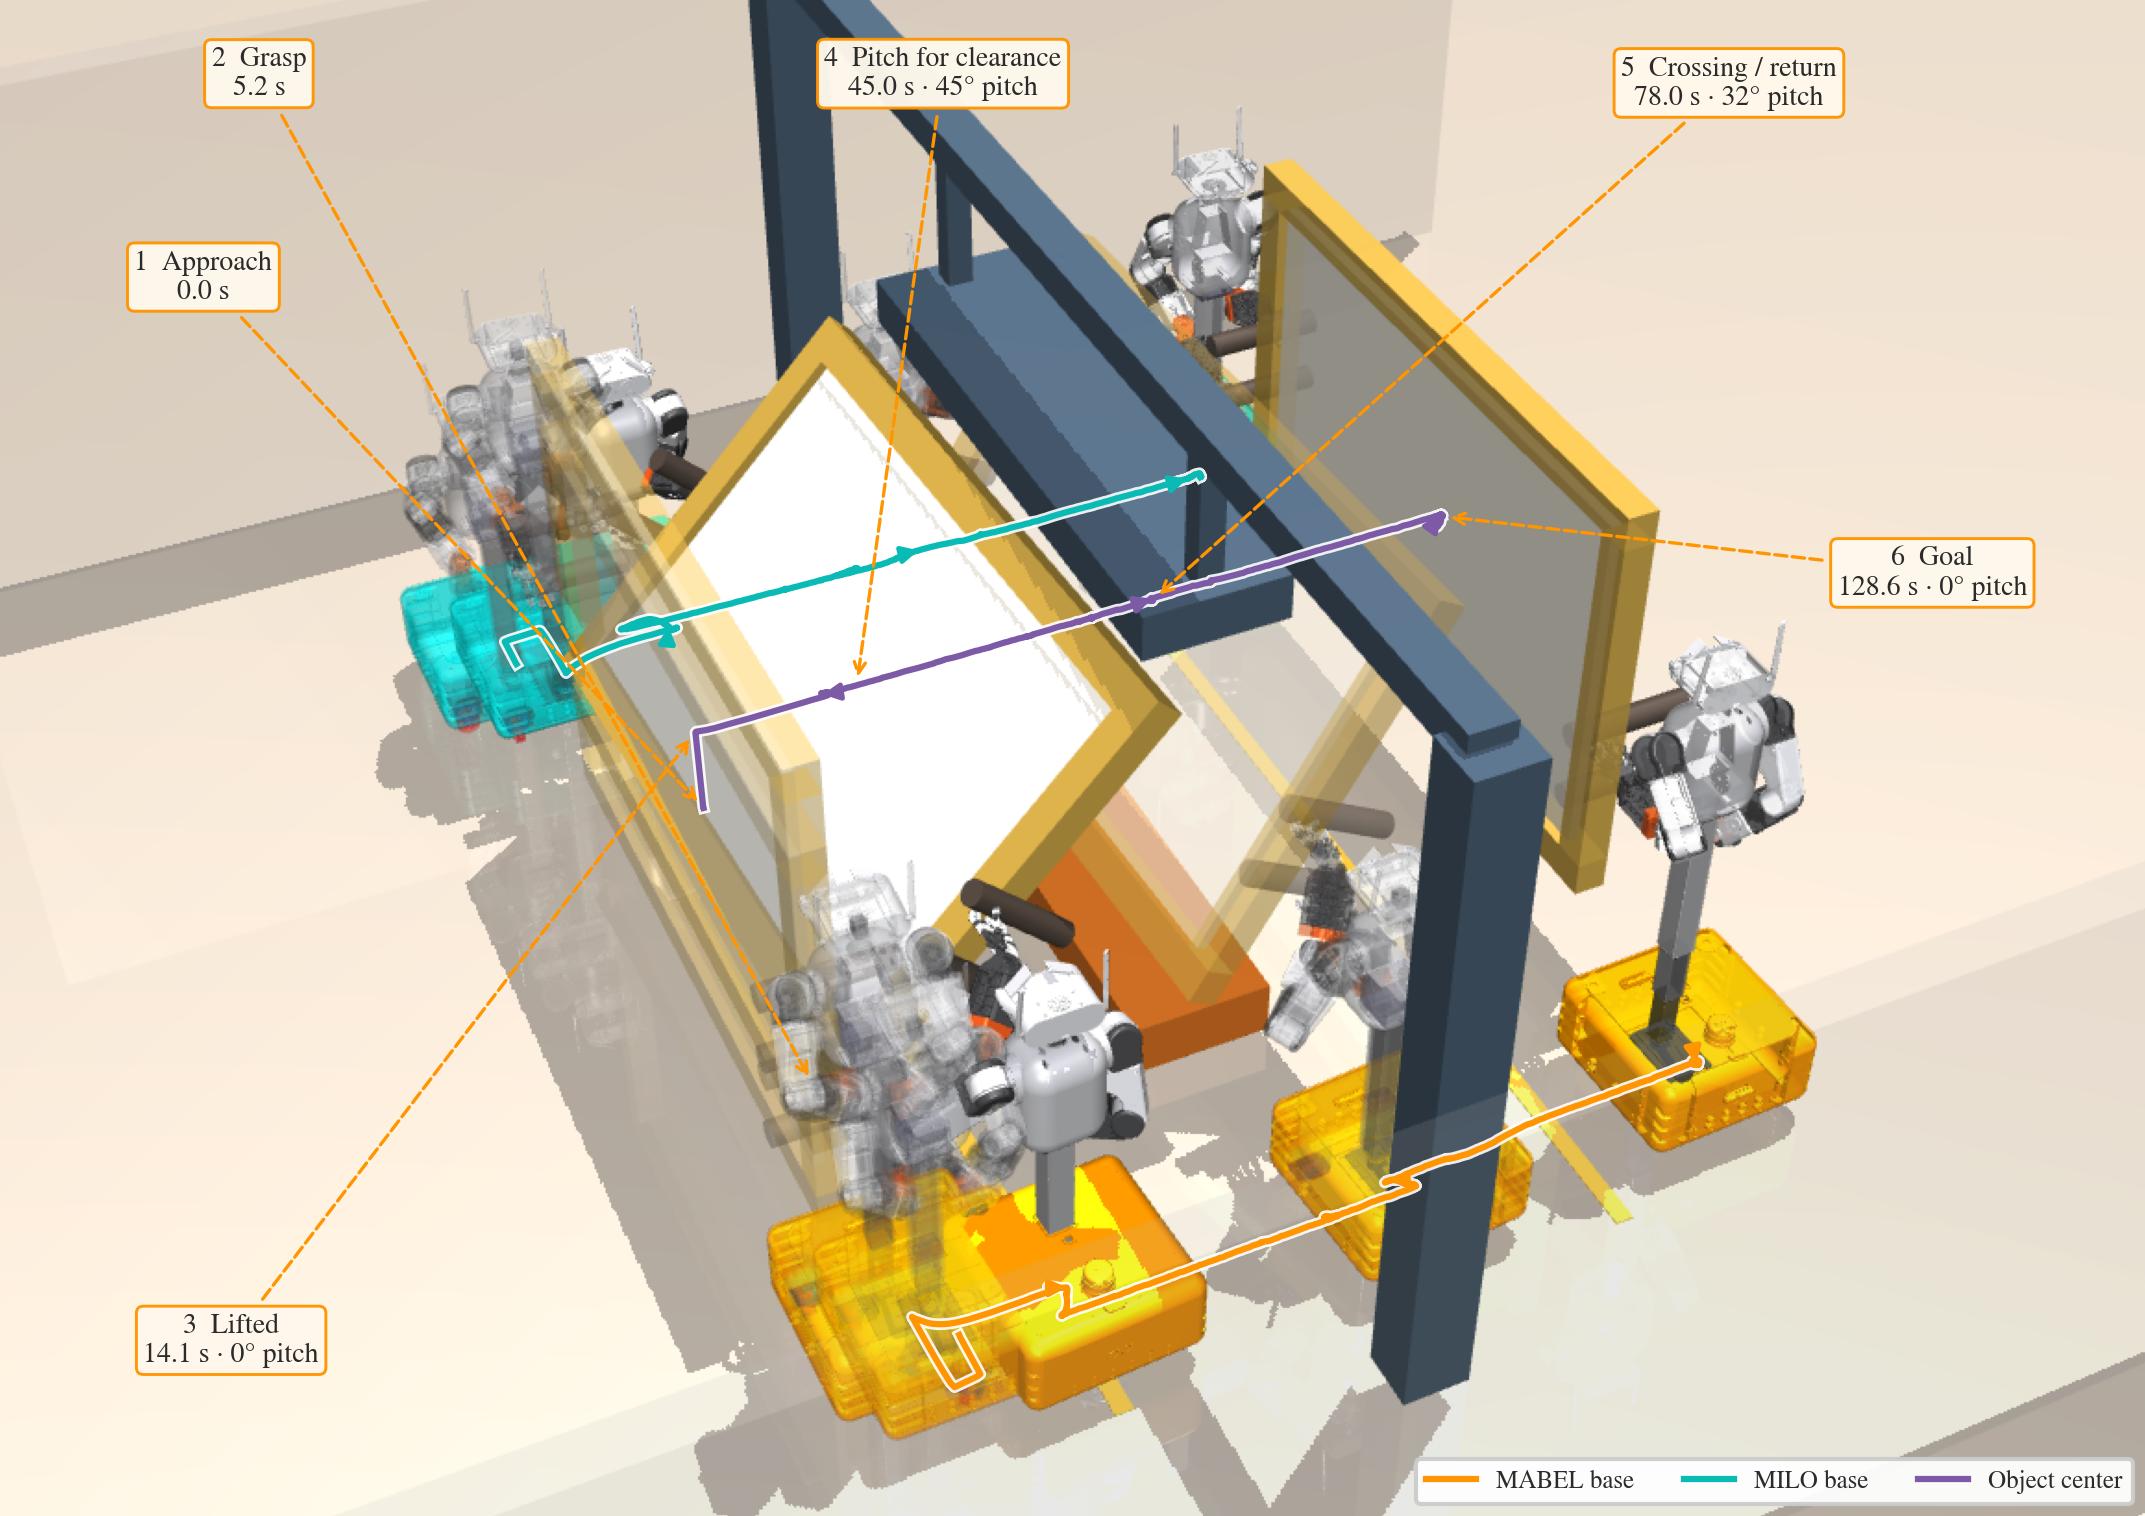
Two mobile manipulators carrying a shared load through a doorway
Read the Room — Cooperative Multi-Robot Transport Ph.D. · Aug 2026 – present · paper in preparation

Two mobile manipulators carry one load. Planning over the grasped assembly rather than the payload alone narrows admissible yaw through an aperture from 25.8° to 5.5°; 35/40 frozen missions across ten MuJoCo scenes.
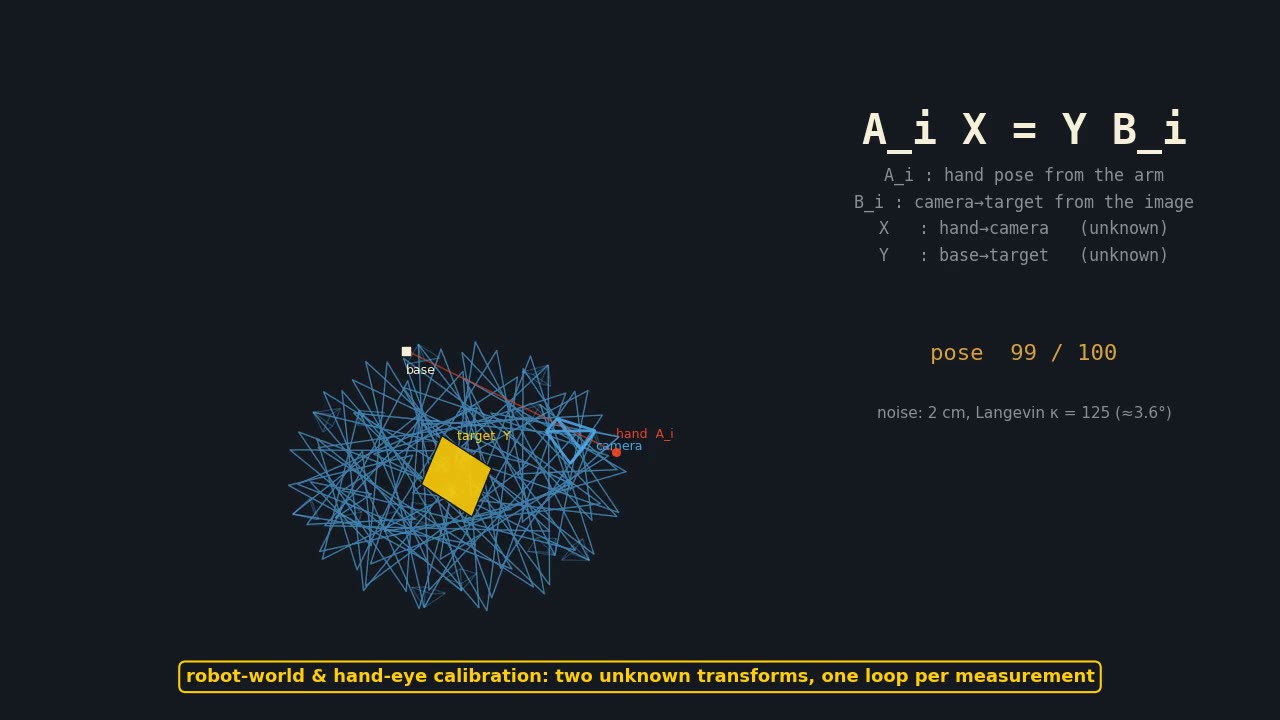
Robot-world and hand-eye calibration setup
Certifiably Correct Robot–World & Hand–Eye Calibration M.Eng. · IJRR 2025

A generalized robot–world and hand–eye calibration that returns a certificate of global optimality instead of a local minimum you have to trust, verified on simulated and real camera–robot data.
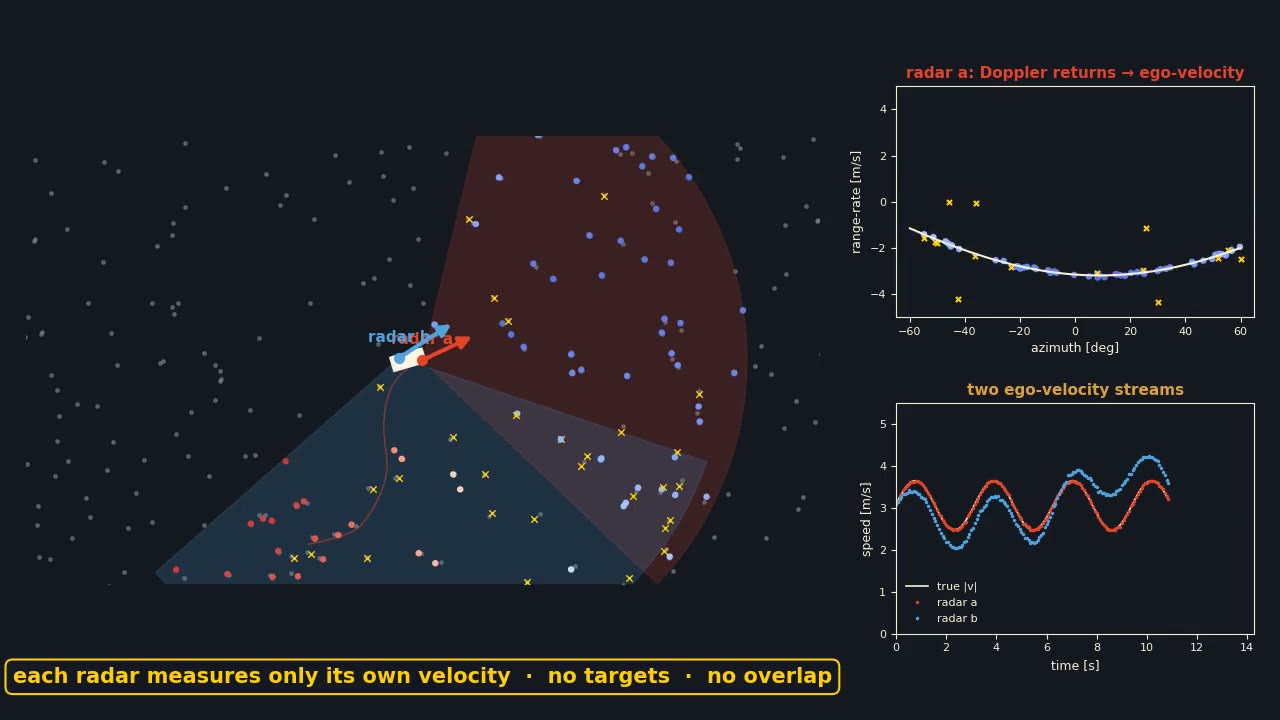
Two millimetre-wave radars mounted for extrinsic calibration
Extrinsic Calibration of 2D Radar Pairs from Ego-Velocity B.A.Sc. · IEEE AIM 2023 · first author

Two radars that never see the same scene can still be calibrated: each one's ego-velocity estimate constrains the transform between them, so no overlapping field of view and no targets are needed.
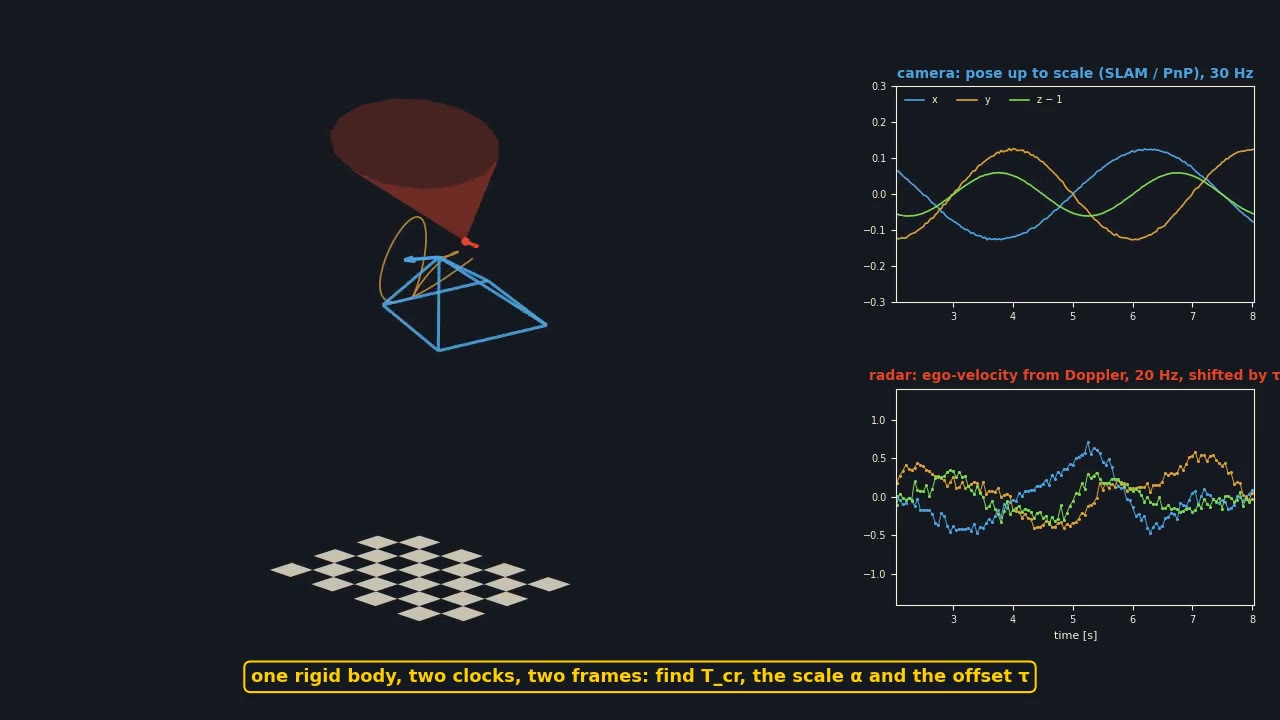
Radar and camera rig used for spatiotemporal calibration
Spatiotemporal Calibration of 3D Radar–Camera Pairs B.A.Sc. · IEEE T-RO 2022

Targetless calibration of both the transform and the time offset between a 3D radar and a camera, fitting continuous-time B-spline trajectories to the two asynchronous sensor streams.
Multi-robot manipulationMotion planningExtrinsic calibrationContinuous-time estimationCertifiable optimization
Machine in Motion Lab Ph.D. Research Fellow — Prof. Ludovic Righetti and Prof. Katsuo Kurabayashi New York University, Tandon School of Engineering · New York Sep 2025 – Aug 2026
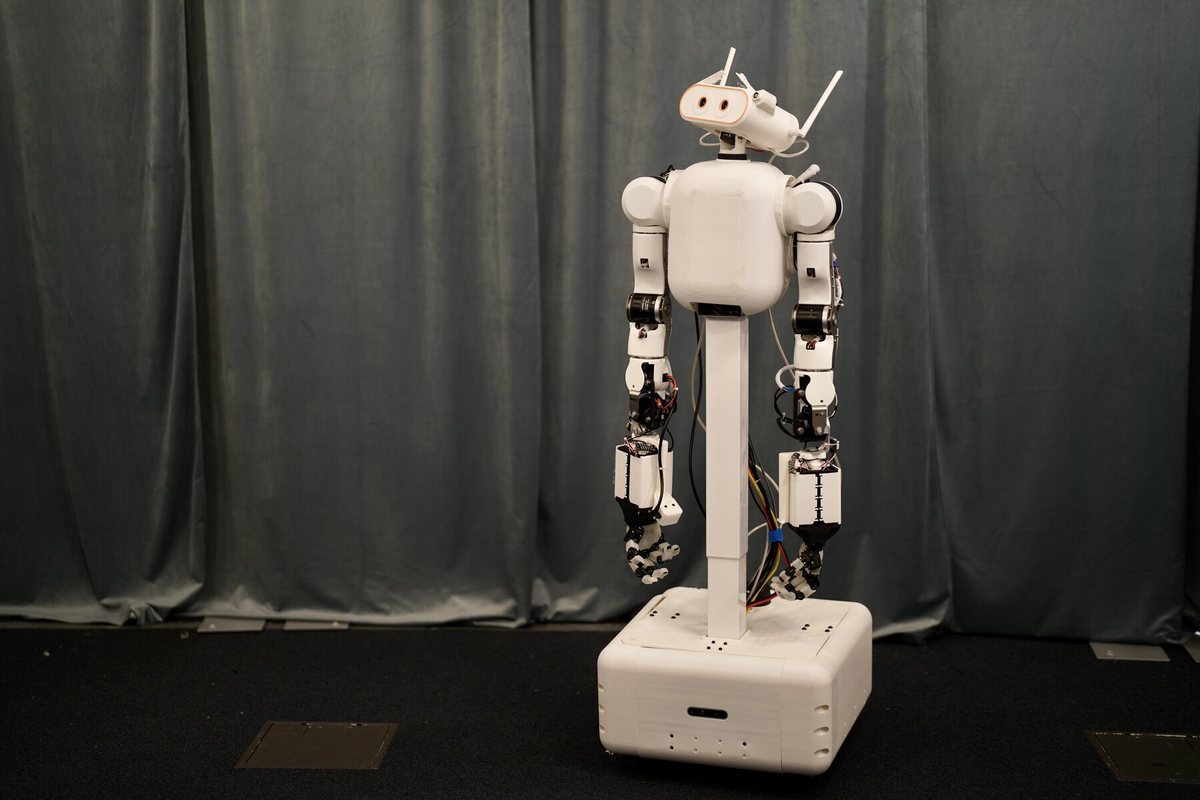
MABEL, an open-source anthropomorphic mobile bimanual robot
MABEL — Mobile Anthropomorphic Bimanual Embodiment Project lead · Apr 2026 – present · system paper under review

A 56-DOF open-source mobile bimanual robot built for $8,722 with no machine shop: swerve base, lifting torso, two 7-DOF arms, two 17-DOF tendon-driven hands, compliant whole-body control, Vision Pro teleoperation.
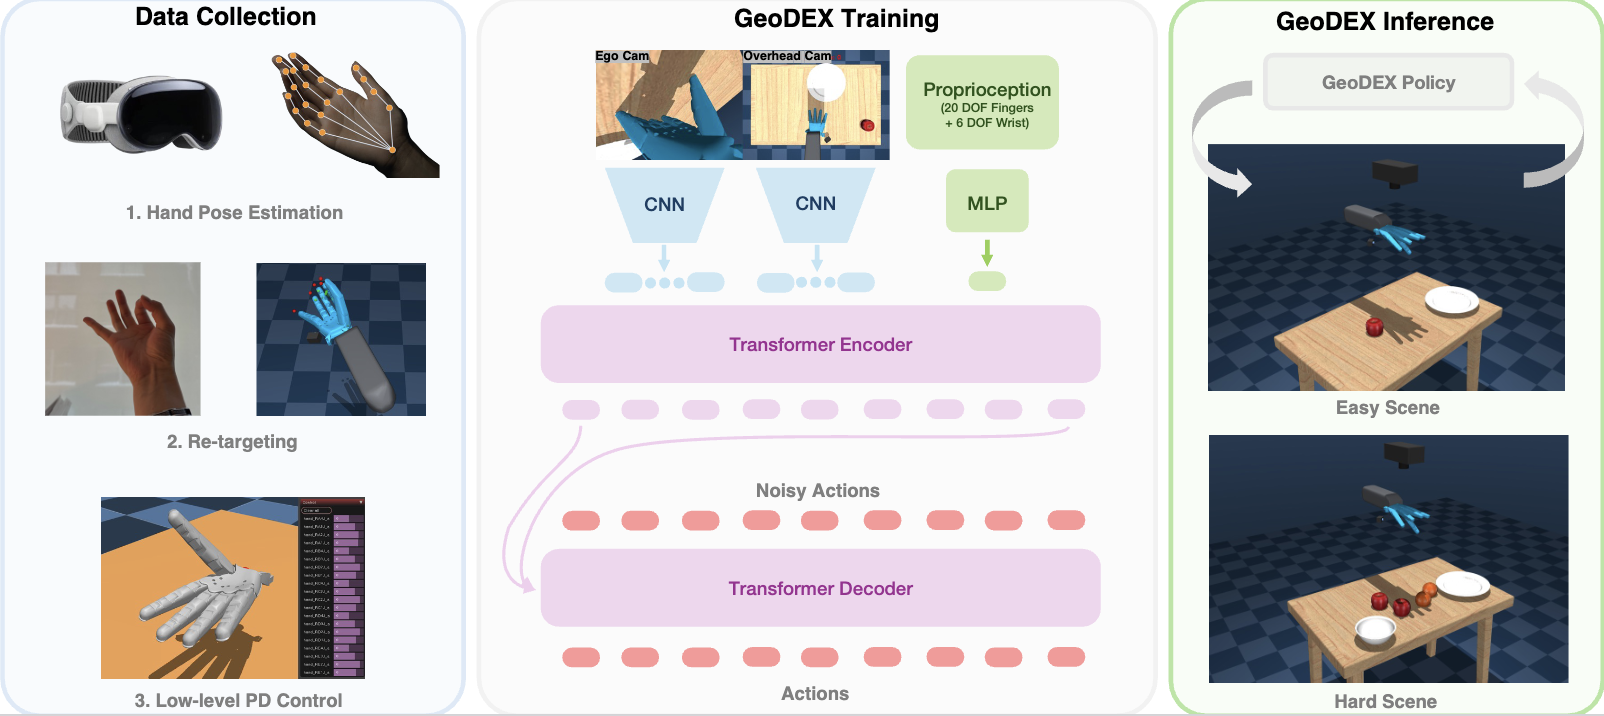
Dexterous hand performing a pick-and-place task
GeoDEX — Geometric Diffusion Policies for Dexterous Manipulation 2025 – 2026

A geometric diffusion-transformer policy for 26-DOF dexterous pick-and-place: dual-view RGB-D to action chunks under geodesic SO(3) and contact-aware fingertip losses, trained on Vision Pro demonstrations.

Dexterous manipulationDiffusion policyWhole-body controlTeleoperationSim-to-real

Also in the lab: mixture-of-experts RL controllers for user-adaptive hip exoskeletons in musculoskeletal simulation.
Dynamic Graphics Project Lab HCI Researcher — Prof. Daniel Wigdor University of Toronto, Department of Computer Science · Toronto Sep 2022 – Aug 2025
VibraForge vibrotactile prototyping toolkit
VibraForge — Spatialized Vibrotactile Prototyping Toolkit ACM CHI 2025

A 128-actuator, high-bandwidth toolkit for spatialized vibrotactile feedback, built so that a haptic prototype does not have to start with a soldering iron and a custom driver board.
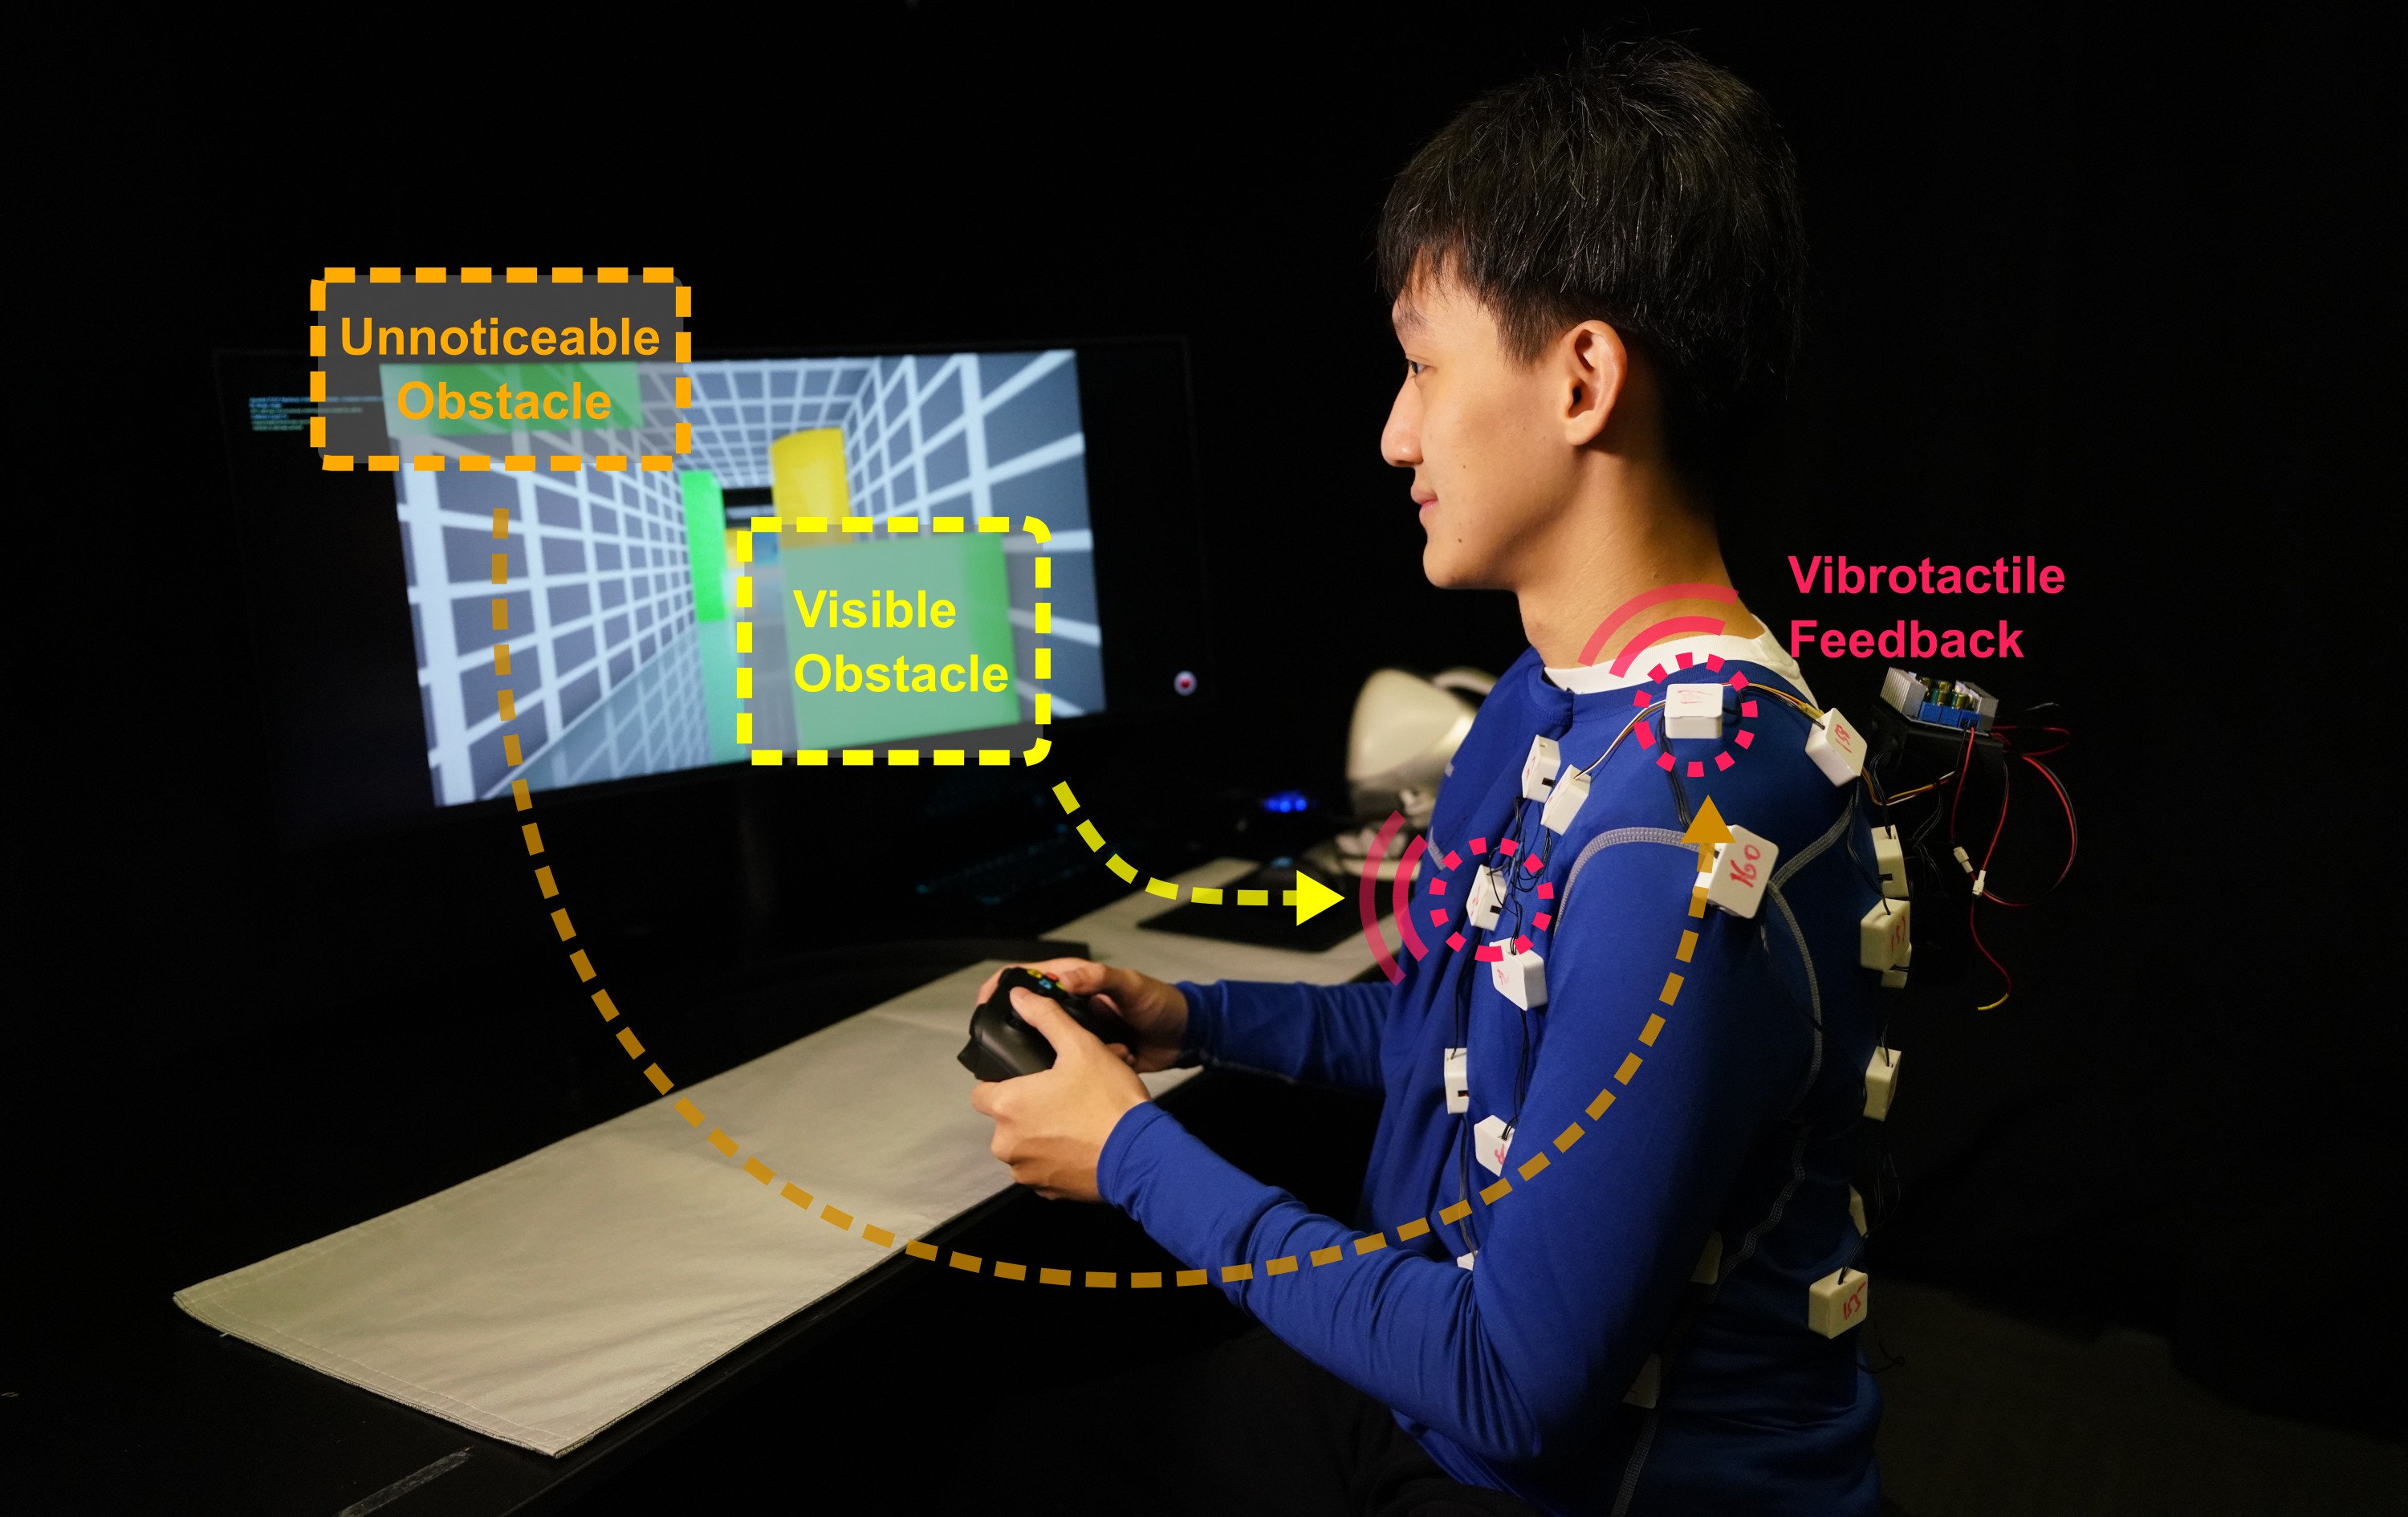
Wearable haptic vest used for UAV teleoperation
AeroHaptix — Wearable Haptics for UAV Teleoperation IEEE RA-L 2024

Wearable vibrotactile feedback for UAV teleoperation, paired with multi-CBF collision avoidance so the pilot is informed about the obstacles around the drone rather than overruled by the controller.

HapticsTeleoperationWearablesCBF safetyMultisensory interfaces
University of Toronto Robotics Institute M.Eng. Researcher — Prof. Matthew Mackay and Prof. Ali Bereyhi Master's thesis · Toronto Sep 2024 – Aug 2025
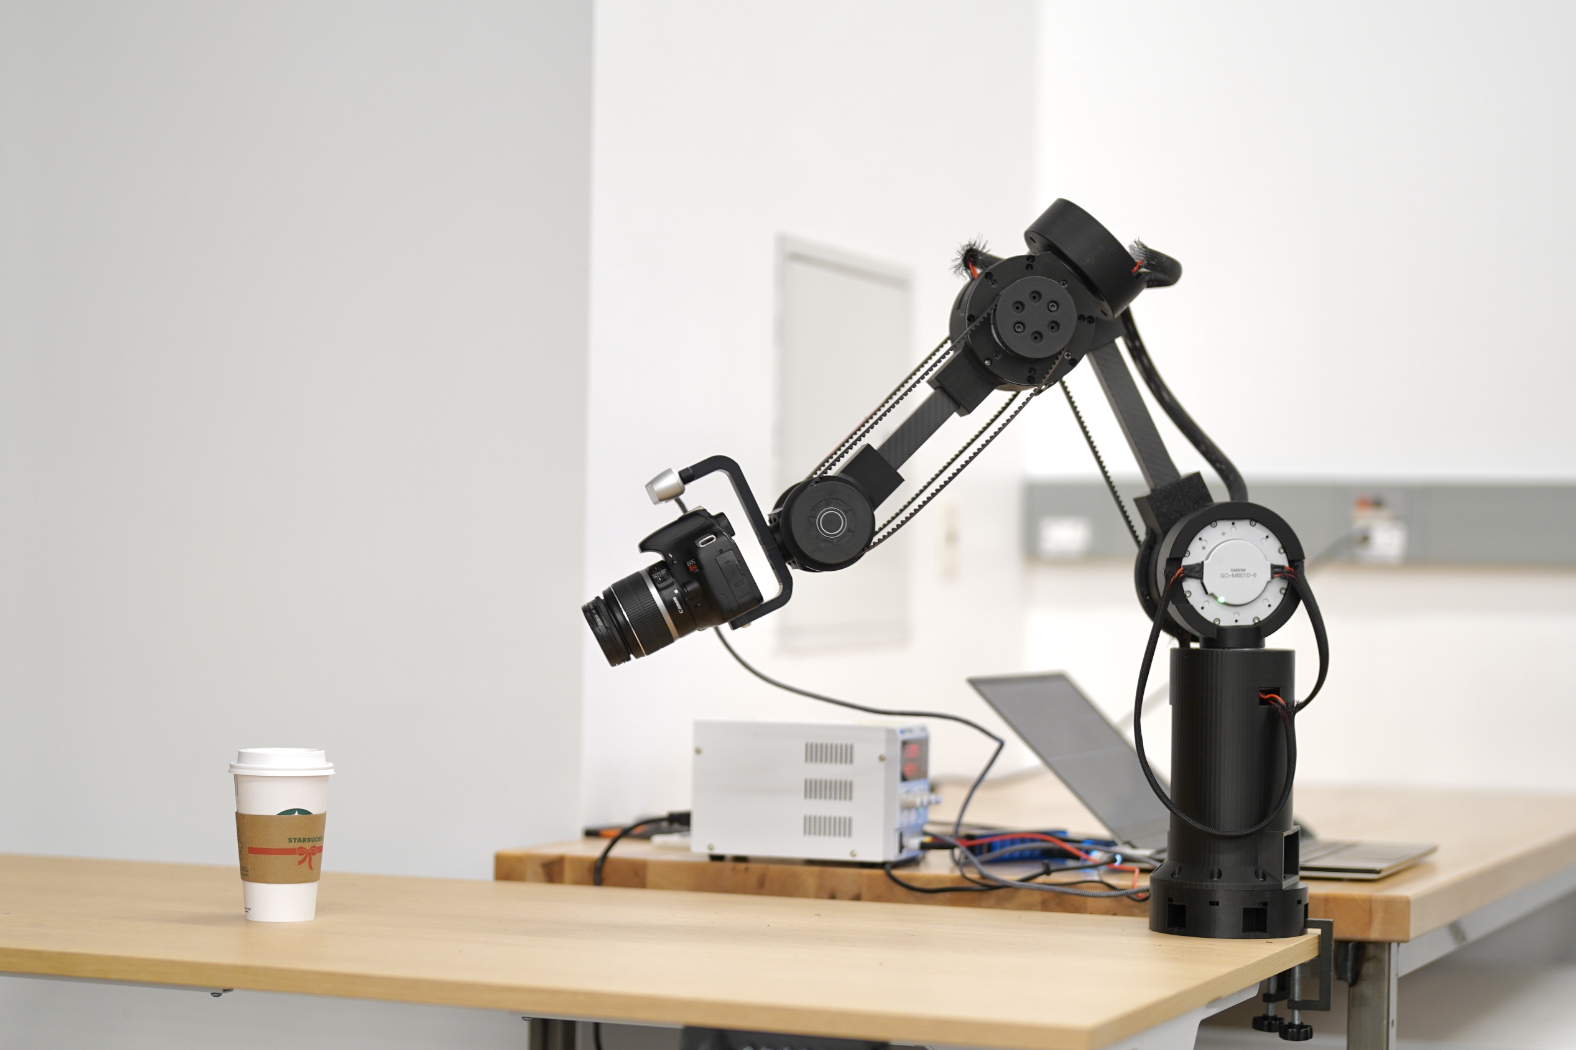
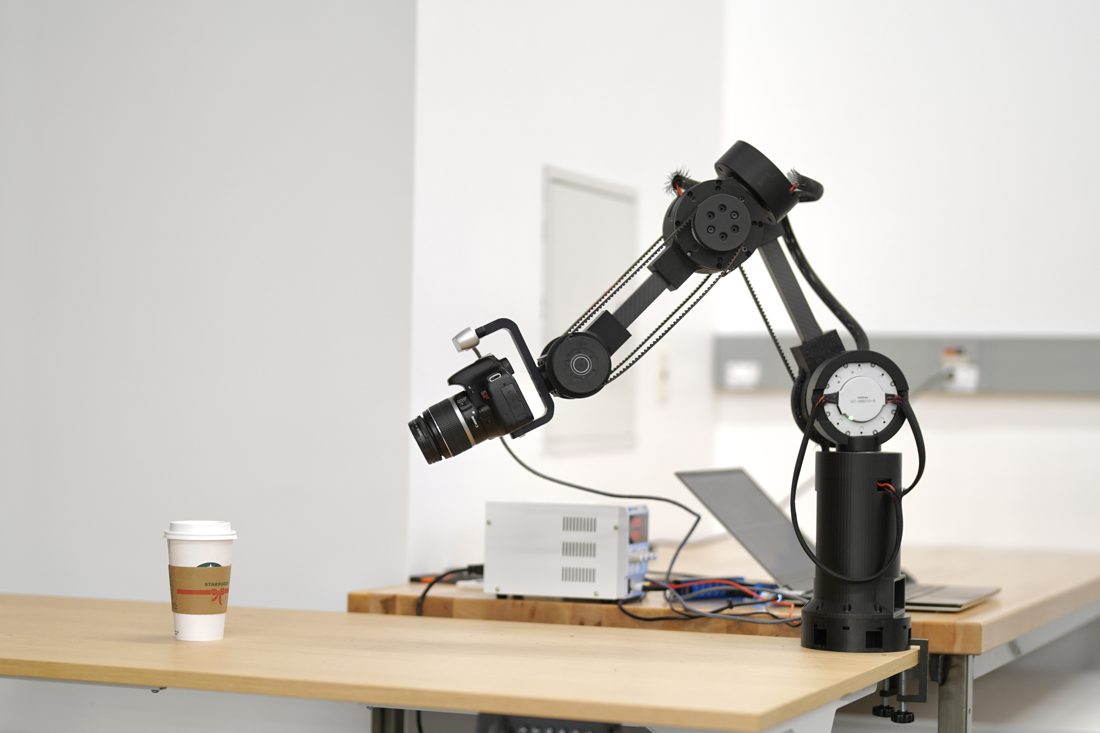
IRIS, a 3D-printed 6-DOF cinema robot arm
IRIS — Intelligent Robotic Imaging System M.Eng. thesis · CRV 2026 (oral, top 10%)

A low-cost 6-DOF 3D-printed cinema robot arm on quasi-direct-drive actuation, with a MuJoCo digital twin and a goal-conditioned ACT–CVAE policy that learns cinematic camera motion from demonstrations.
Task-specific designQDD actuationImpedance controlImitation learningROS
Neural Robotics Lab Robotics Researcher — Prof. Brokoslaw Laschowski KITE Research Institute, University Health Network · Toronto Sep 2023 – Sep 2024
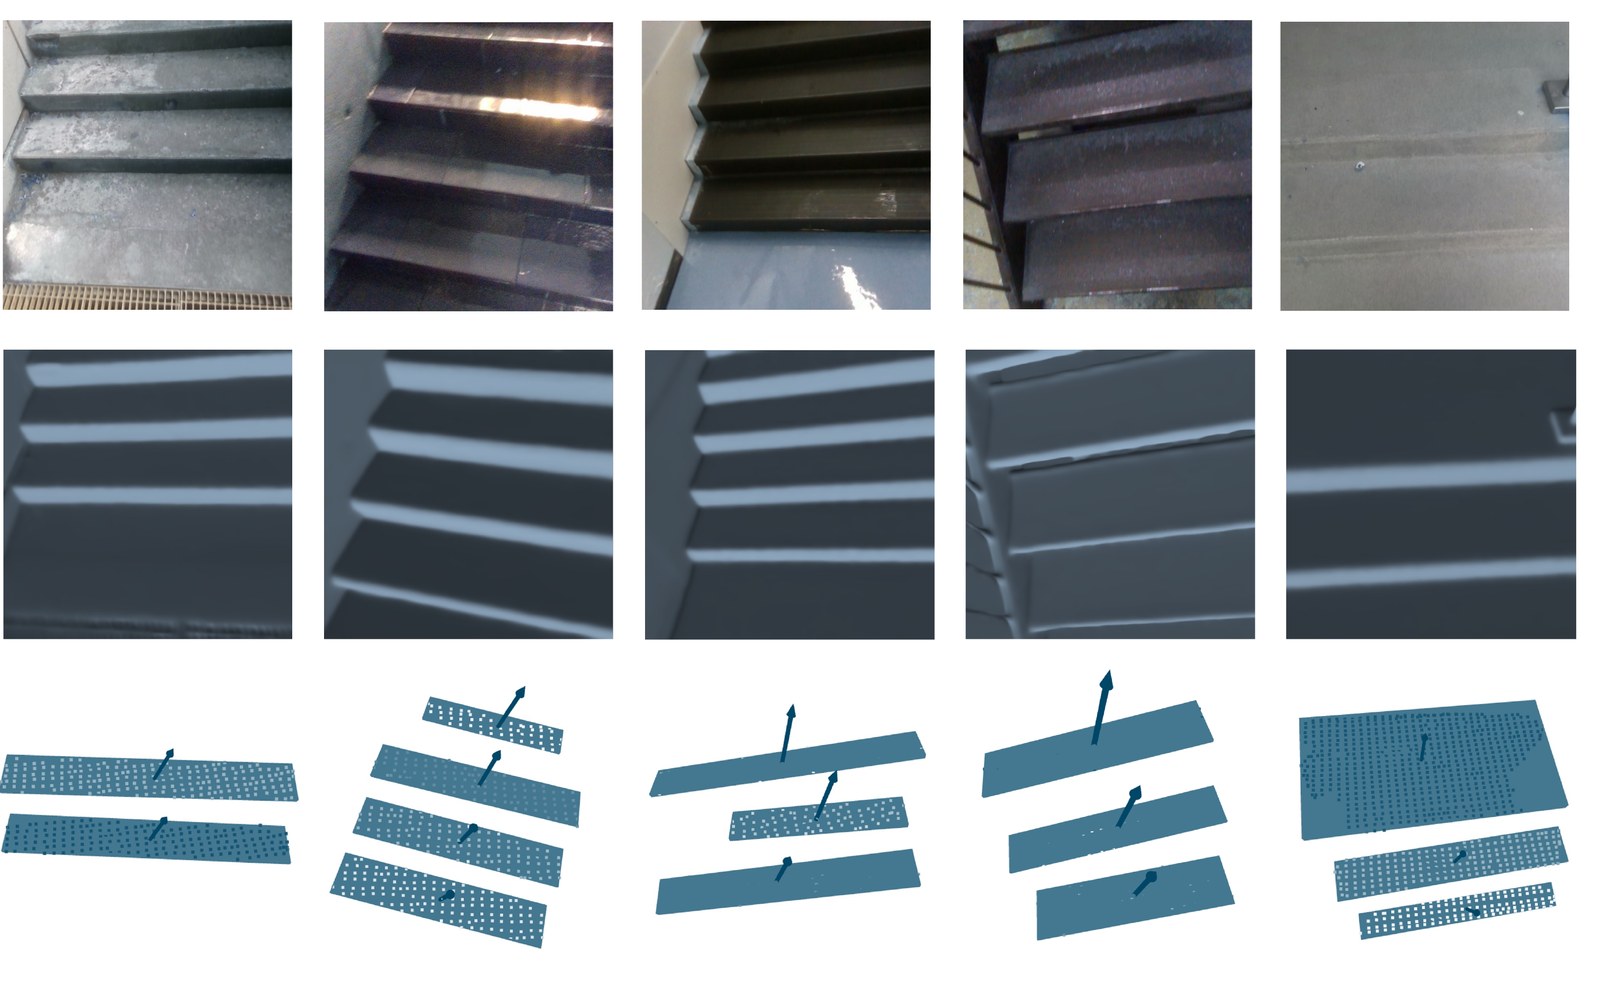
Monocular depth estimation of stairs for a walking robot
BipedNav — Stair Perception for Adaptive Walking TRC poster 2024

Monocular perception joined to virtual-holonomic-constraint control for stair walking, with a Metric3D depth pipeline whose normal maps recover stair rise, run and edge from a single camera.
Exoskeleton controlVHC locomotionMonocular depthStair perception

Industry Experience

Motion Picture Robotics Founder — cinema robotics motion picture robotics · Toronto / New York 2025 – present
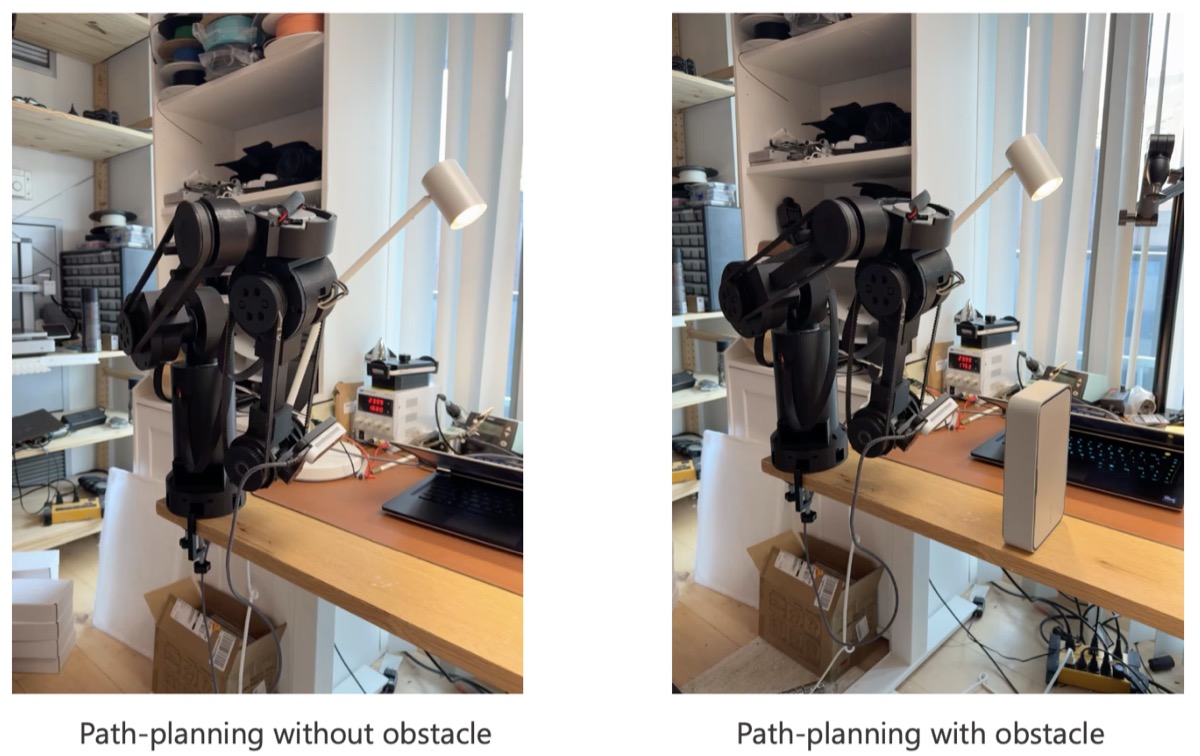
  • Film-grade robotic camera motion is astonishing, and priced out of reach — professional camera-motion rigs run well into six figures. I am building a mobile cinema robot arm: portable enough to carry onto any set, affordable enough for independent creators, simple enough to run without a technical crew.
  • The work spans the whole stack — quasi-direct-drive actuators and firmware, kinematics and shot planning, and the company around them.
MechatronicsQDD actuationMotion planningProduct
The cinema robot arm on a desk, holding a camera Shot planning with and without an obstacle
The arm on a desk with a camera on it, and shot planning around an obstacle.
GouPals Inc. Cofounder / CEO — cross-border commerce linkedin.com/company/goupals · Toronto Aug 2024 – Apr 2025
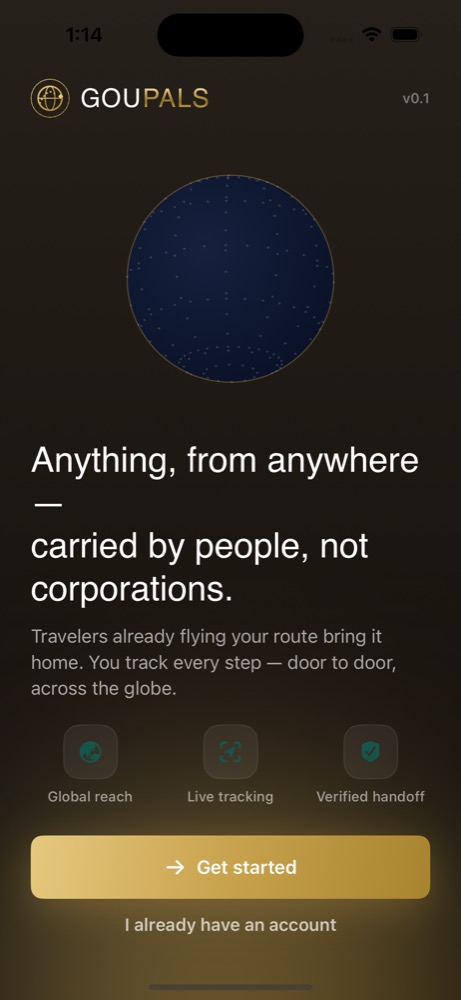
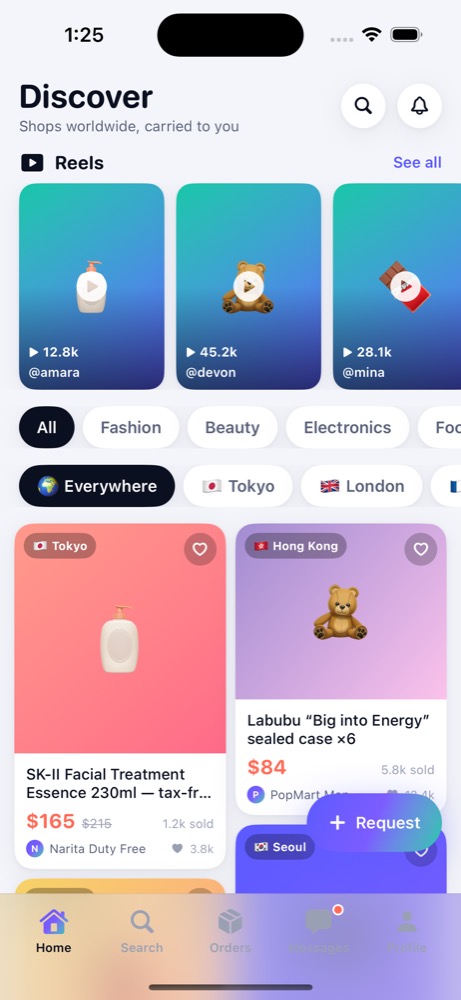
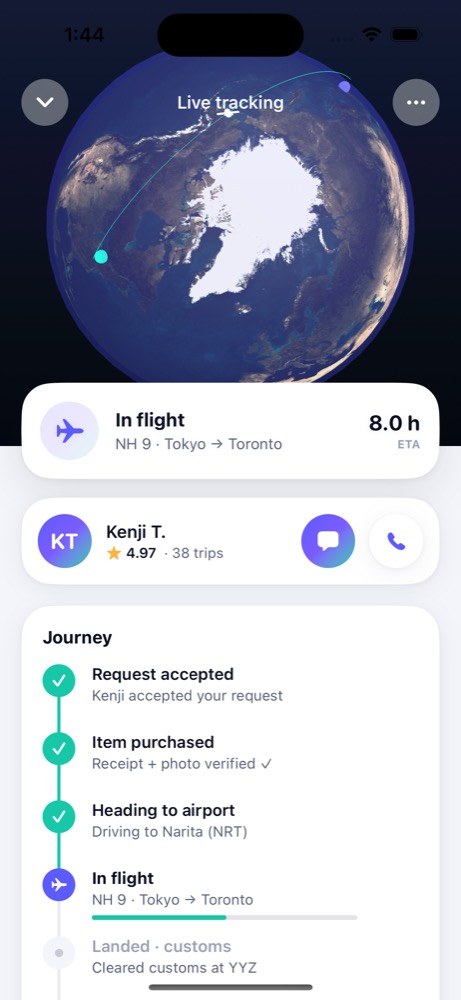
  • A peer-to-peer international logistics platform on one idea: anything, from anywhere — carried by people, not corporations. Buyers request items from any city; travellers already flying that route bring them home, with live door-to-door tracking and a verified handoff.
  • Built and launched the iOS MVP in under two months on Swift, React and Firebase, with GPS tracking, push notifications and a backend tuned for traveller–buyer pairing.
  • Led a team of three cofounders across product, marketing and finance for China–North America–Europe trade routes.
ProductSwiftUIReactFirebaseFundraising
GouPals — landing screen GouPals — global marketplace GouPals — live door-to-door tracking
The shipped iOS app: landing, marketplace, live tracking.
ONE800 Inc. Software Engineer / Machine Learning Engineer 3.230.3.191 · LLM products · Toronto Apr 2023 – Dec 2023
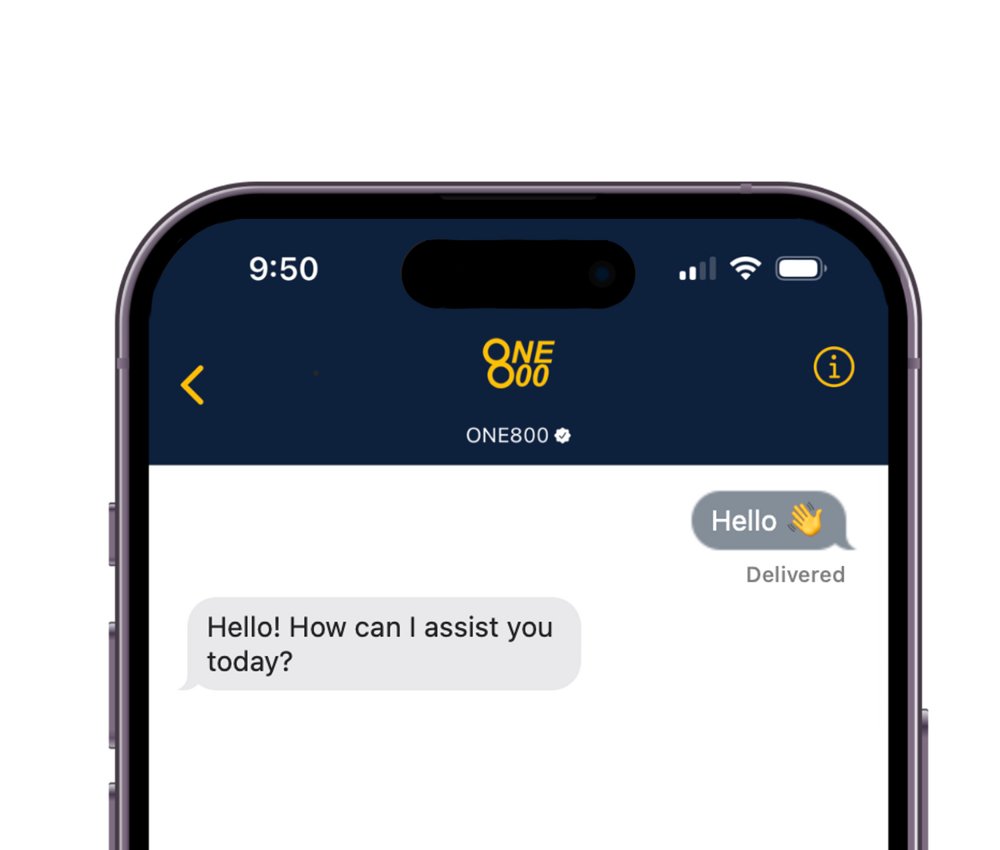
  • Put a large language model where older users already are: inside iMessage, with no app to install. With a ten-person engineering team I built the Apple-approved integration, handling text, images and voice memos.
  • Developed multilingual LLM pipelines for transcription, translation, OCR and generation.
  • Built a LangChain + Redis memory layer that gave the conversational agents both short- and long-term recall.
LLM pipelinesLangChainRedisOCRiMessage / Apple review
The ONE800 assistant answering inside an iMessage thread
The shipped product: an LLM answering inside iMessage. Image: ONE800.
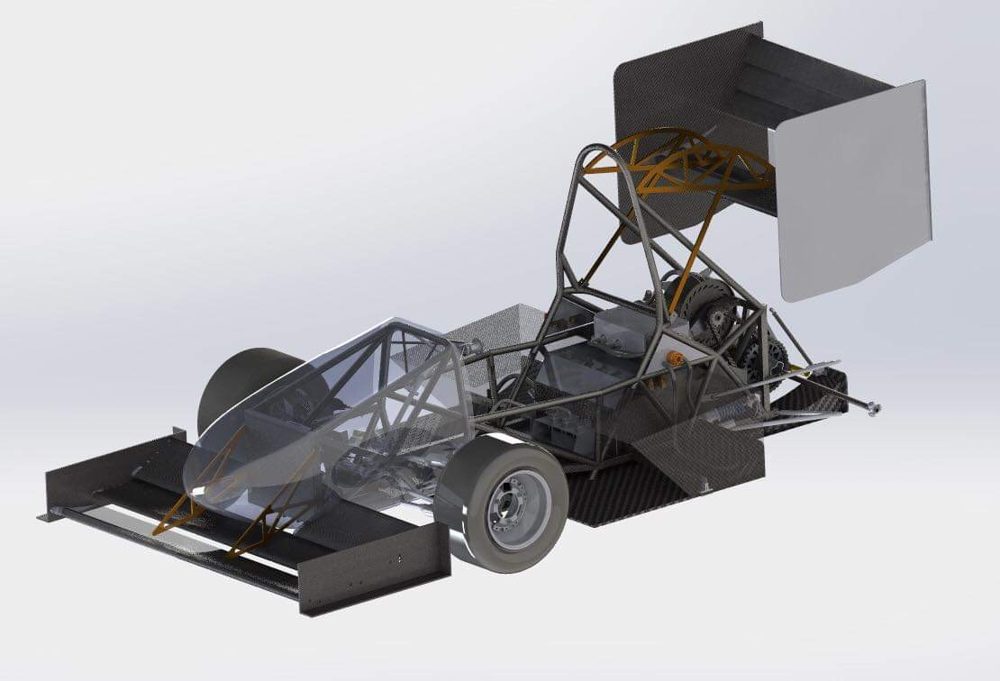
University of Toronto Formula Racing Drivetrain Team Lead — FSAE electric race car the gearbox write-up · Toronto Sep 2021 – Jun 2022
  • Designed a compact 4:1 planetary gearbox for the FSAE electric car, replacing a chain-and-sprocket drivetrain and pulling 176 mm out of the wheelbase.
  • Optimised gears, housing, lubrication and vibration with KISSsoft, ISO standards, FEA and lap simulations, at 92% efficiency and four times the torque.
  • Delivered a full-scale prototype with manufacturing, assembly and dyno test plans — worth over two seconds off the endurance event.
Gearbox designKISSsoftFEASolidWorksManufacturing
The University of Toronto Formula Racing electric car
The car the drivetrain went into.
BOE Technology Group Co. Machine Learning Engineer Intern boe.com · Beijing Jun 2021 – Aug 2021
  • Designed, trained and evaluated two CNNs in TensorFlow and PyTorch to distinguish pedestrian features, supporting BOE's IoT and semiconductor-display machine-learning pipeline.
  • Built the data-collection tools and web scrapers behind it: 3,000+ crawled videos and images and 20,000+ annotated samples, taking model accuracy from 64.3% to 89.1%.
CNNsTensorFlowPyTorchData pipelinesComputer vision
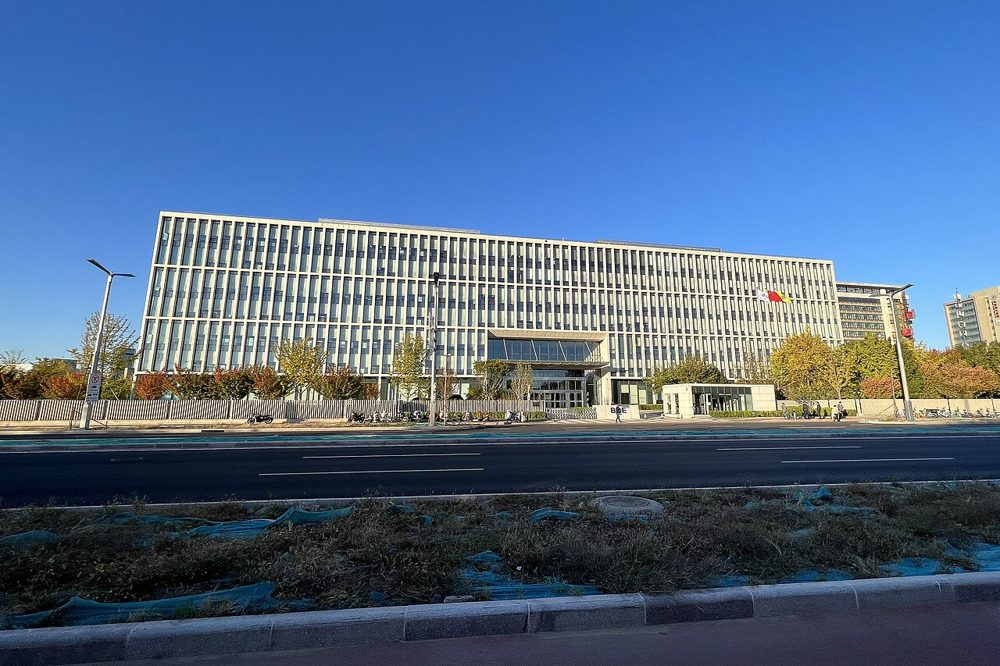
BOE Technology headquarters in Beijing
BOE's Beijing headquarters. Photo: N509FZ, CC BY-SA 4.0.
China State Shipbuilding Corporation Mechanical Engineer Intern — marine HVAC & fire systems chinaships.com · Shanghai Sep 2020 – May 2021
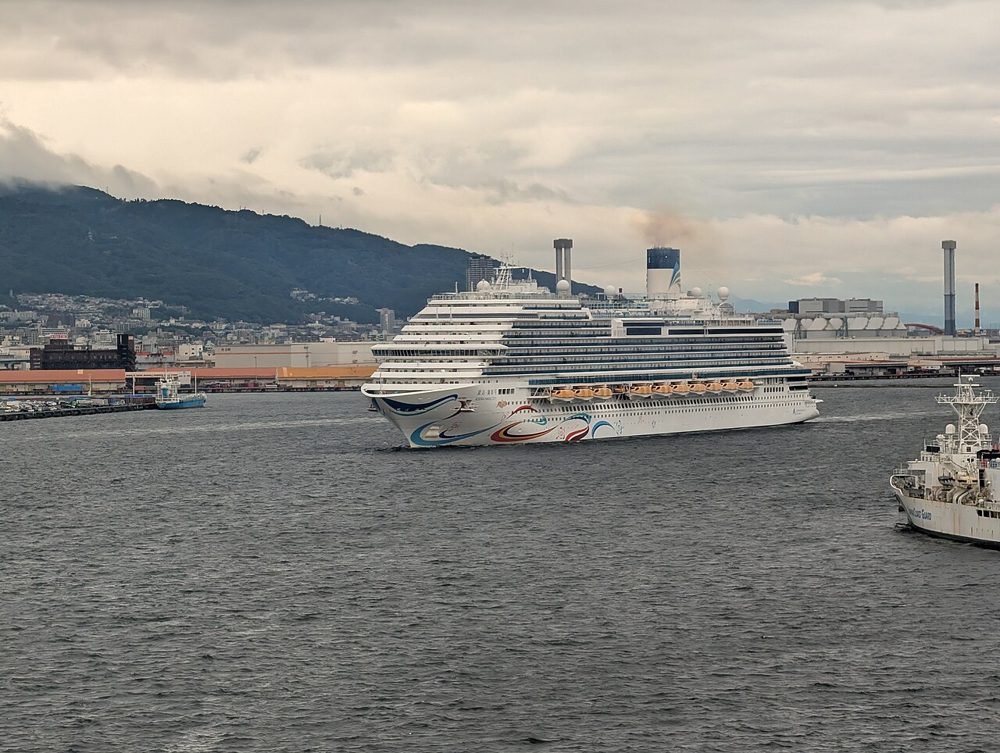
  • Designed HVAC subsystems for China's first domestically built 12-deck cruise ship, working in CADMATIC and Bentley alongside the shipyard's engineering teams.
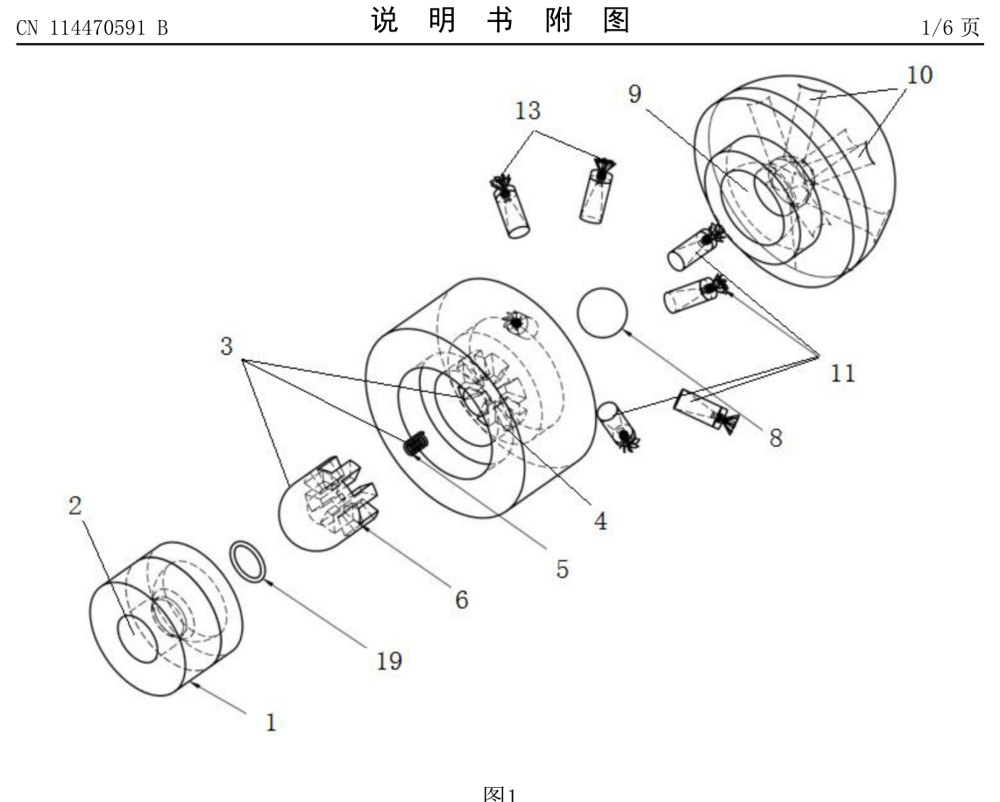
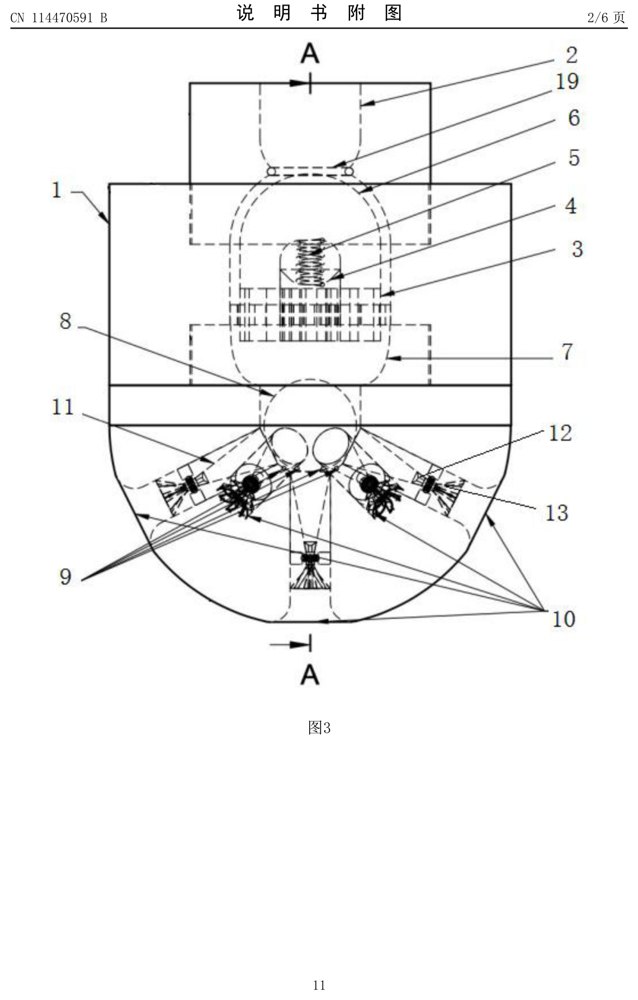
  • Patented a high-efficiency spray-nozzle fire pipeline: CFD tests showed 80% water savings and 67% faster fire response than the baseline system.
HVAC designCFDCADMATICBentley
Adora Magic City, the first cruise ship built in China, leaving port Fig. 1 of patent CN 114470591 B — exploded view of the water mist nozzle Fig. 3 of patent CN 114470591 B — cross-section through the valve and swirl chamber
Adora Magic City — the first cruise ship built in China, under construction at CSSC while I was there. Photo: Masahiko OHKUBO, CC BY 4.0. Below: figures 1 and 3 of patent CN 114470591 B, the centrifugal mist nozzle for the fire main.
Autodesk Inc. Student Ambassador — design tools & teaching autodesk.com · Toronto Sep 2019 – May 2020
  • Founded and led the Fusion Design Association, teaching students Fusion 360 — CAD, CAM and generative design — and the manufacturing workflows around them.
  • Mentored 30+ students and ran an annual 3D-printed glider competition, including the custom engineered launch system it flew from.
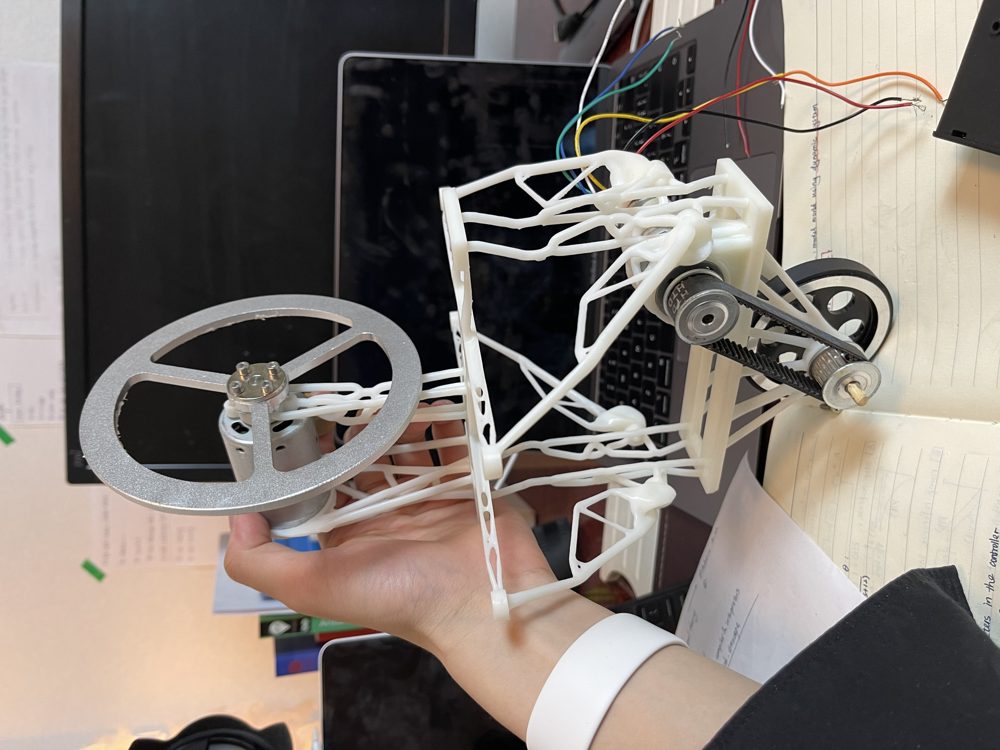
  • The generative-design habit stuck: it shows up in the unicycle robot and in every printed bracket since.
Generative designFusion 360CAMTeaching
A 3D-printed generative-design chassis held in one hand
Generative design, printed: the unicycle chassis that came out of the Fusion 360 habit.

Education, the ventures I have started, and the full toolbox live on the CV. The résumé PDF has the same history on three pages.