Robotics Ph.D. candidate ◆ University of Toronto Made in NYC

Jerry (Qǐlóng)
Chéng

程启龙

Robots for the home, built end to end.

Jerry (Qilong) Cheng

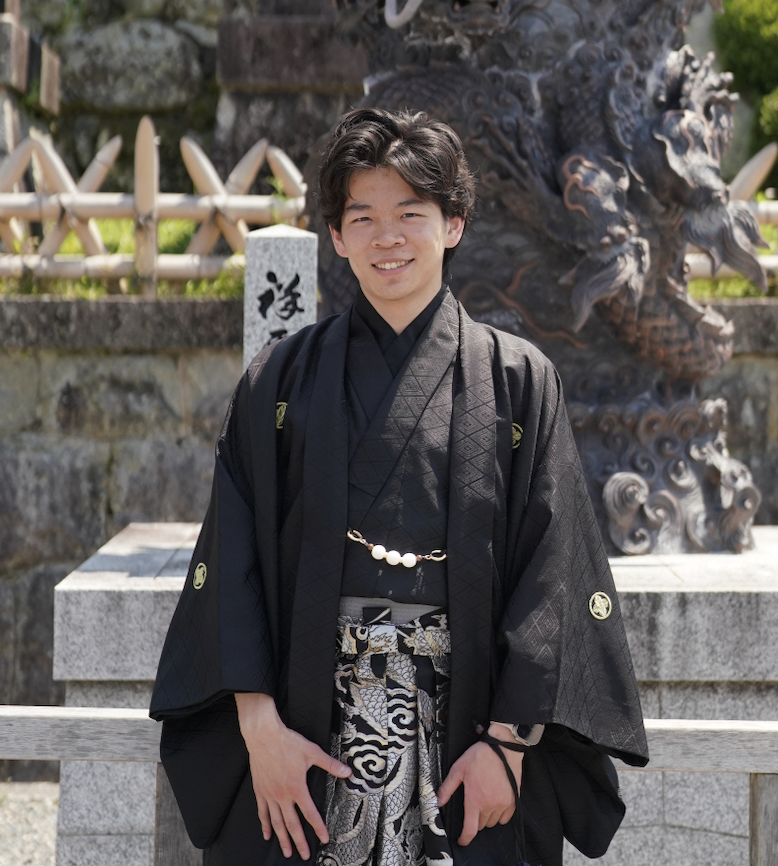
I’m Jerry (Qilong) Cheng, a Robotics Ph.D. Candidate at the University of Toronto building the next generation of Embodied Intelligence — machines that move, sense, and think. I work with Prof. Jonathan Kelly in the STARS Lab (UTIAS), and began my Ph.D. at New York University with Prof. Ludovic Righetti (Machines in Motion). My mission is to engineer generalized, highly articulate robots for the home—vertically integrated systems designed to automate daily tasks, save us time, and seamlessly enrich our lives.

Research Vision

“We are born too late to explore the Earth and too early to explore the stars — but just in time to solve AI and robotics.” — Jim Fan

Robotics is nearing the scaling inflection that reshaped language and vision — and the binding constraint is large-scale, diverse action data, not new methods. I build one full-stack pipeline aimed at that bottleneck, connecting hardware co-design, learning from human video, and real-world reinforcement learning — toward general-purpose robots for the home.

“Those who are truly serious about software should design their own hardware.” — Steve Jobs
Publications
All publications
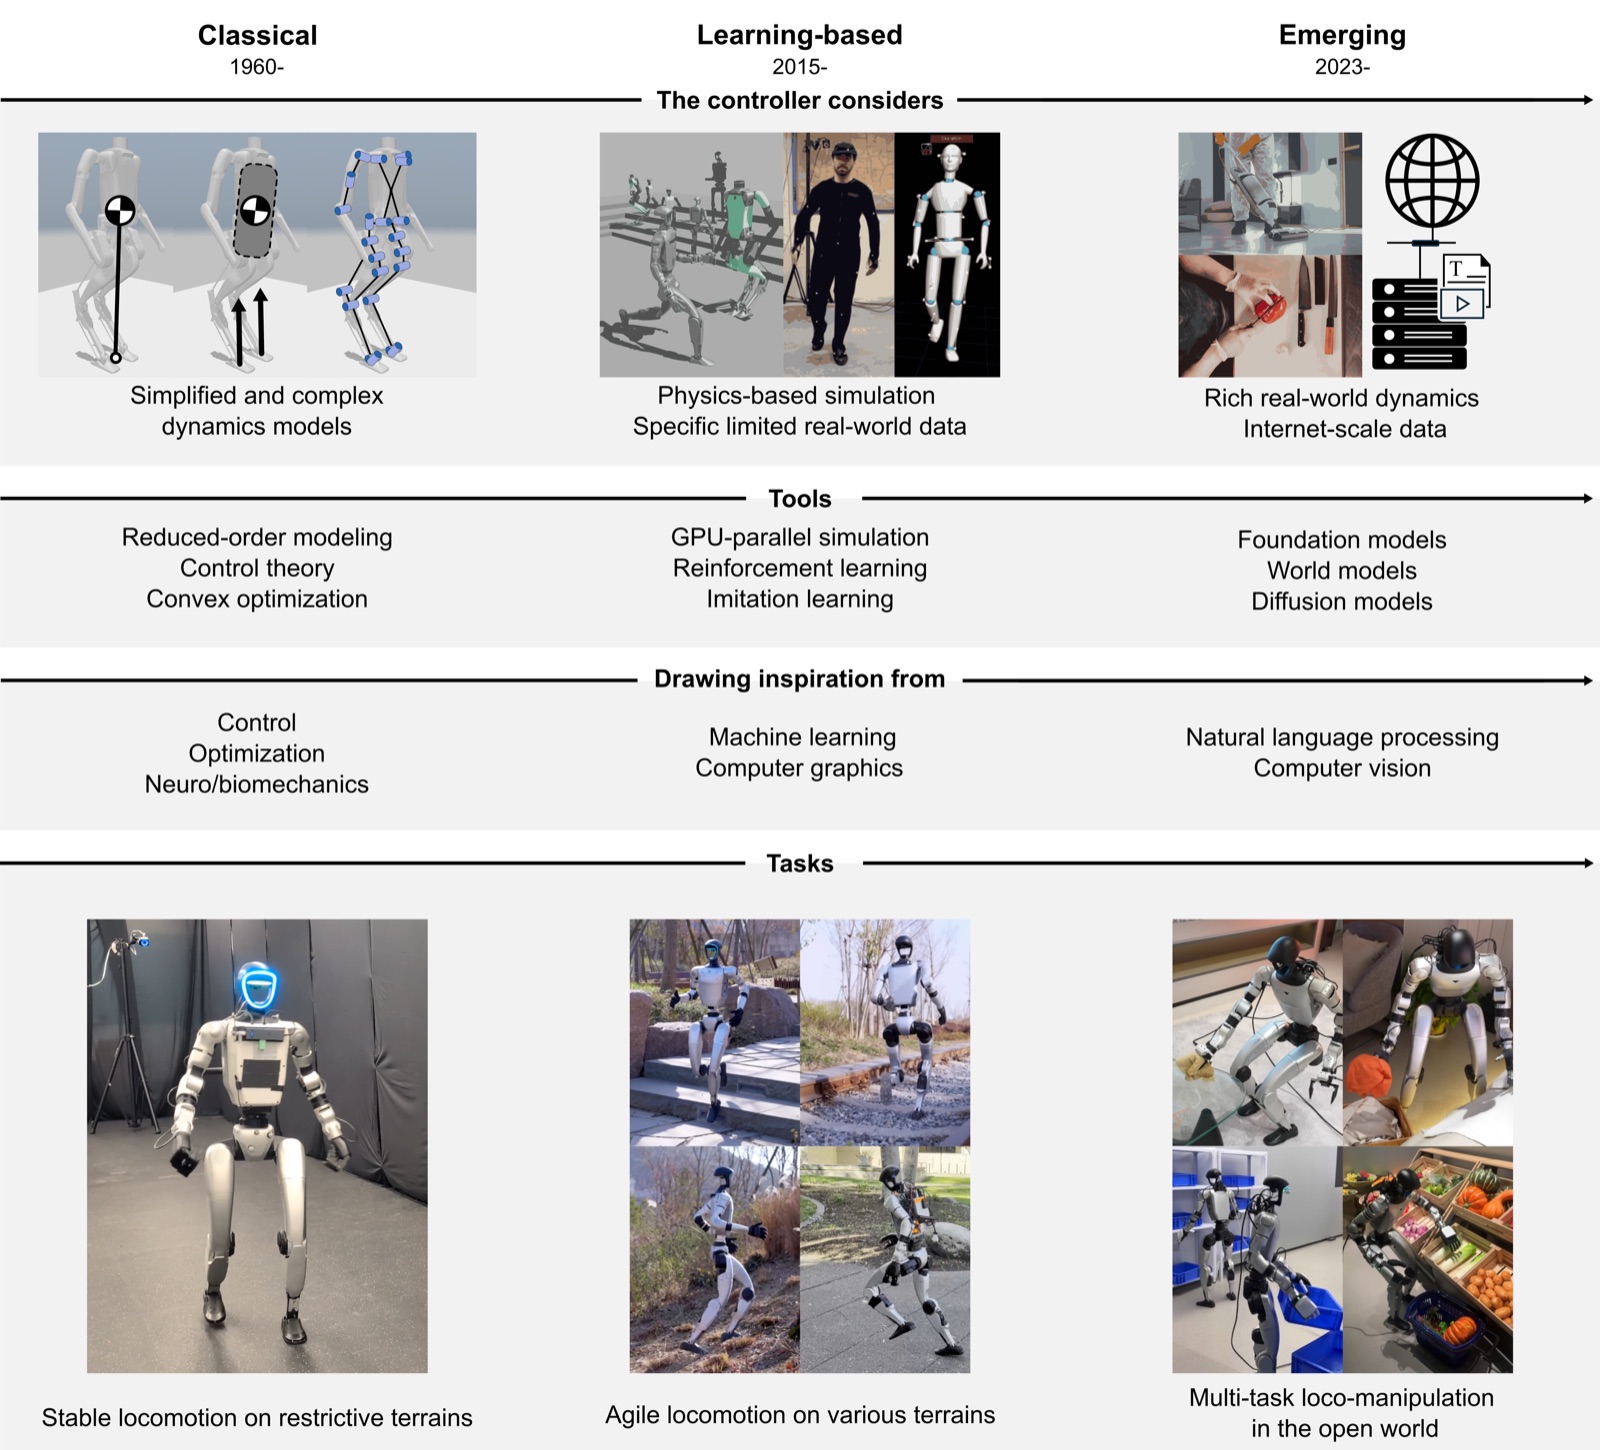
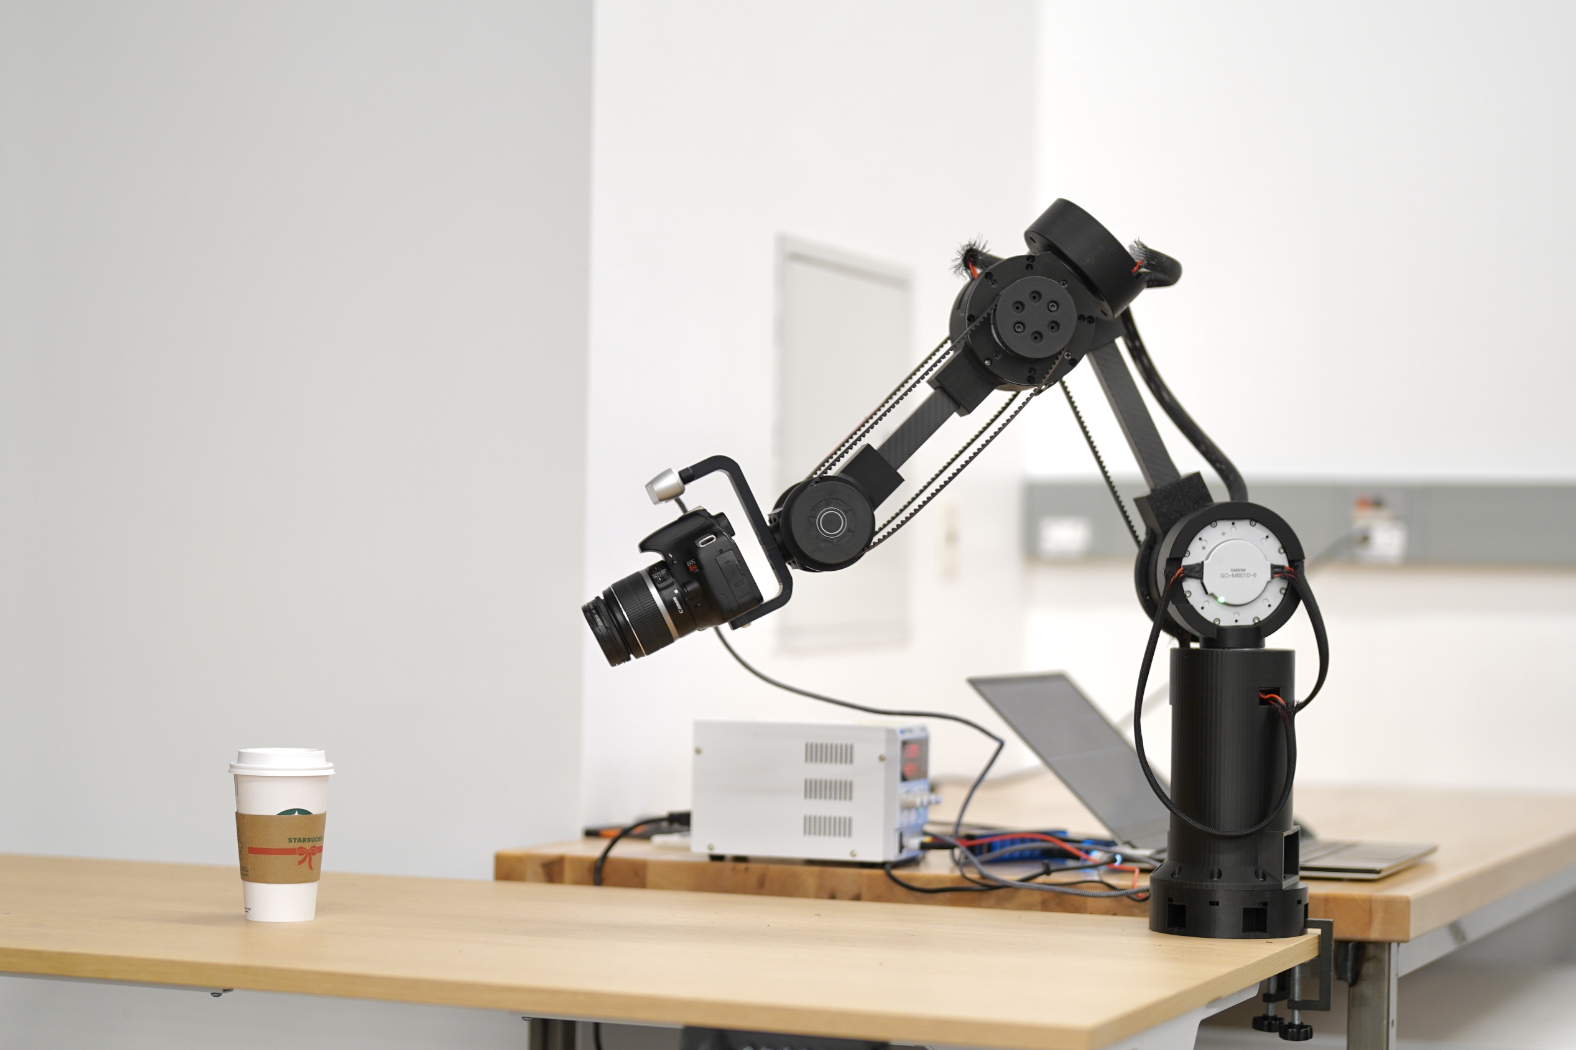
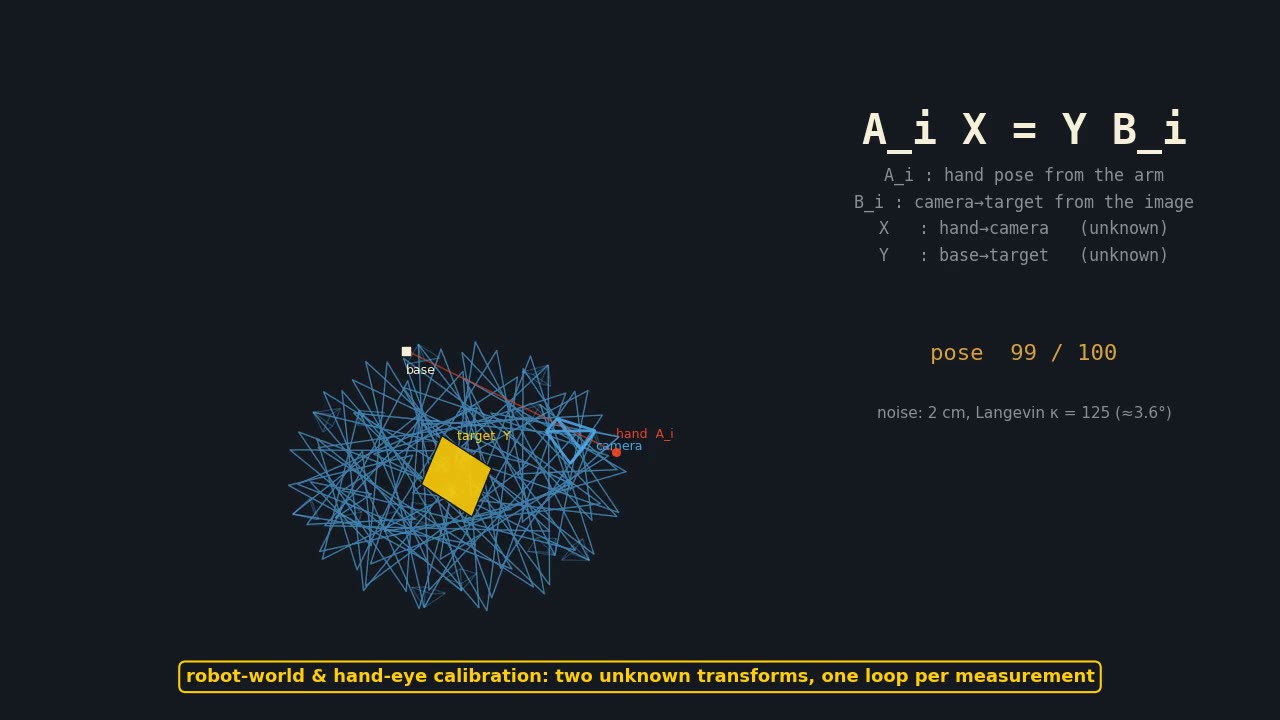
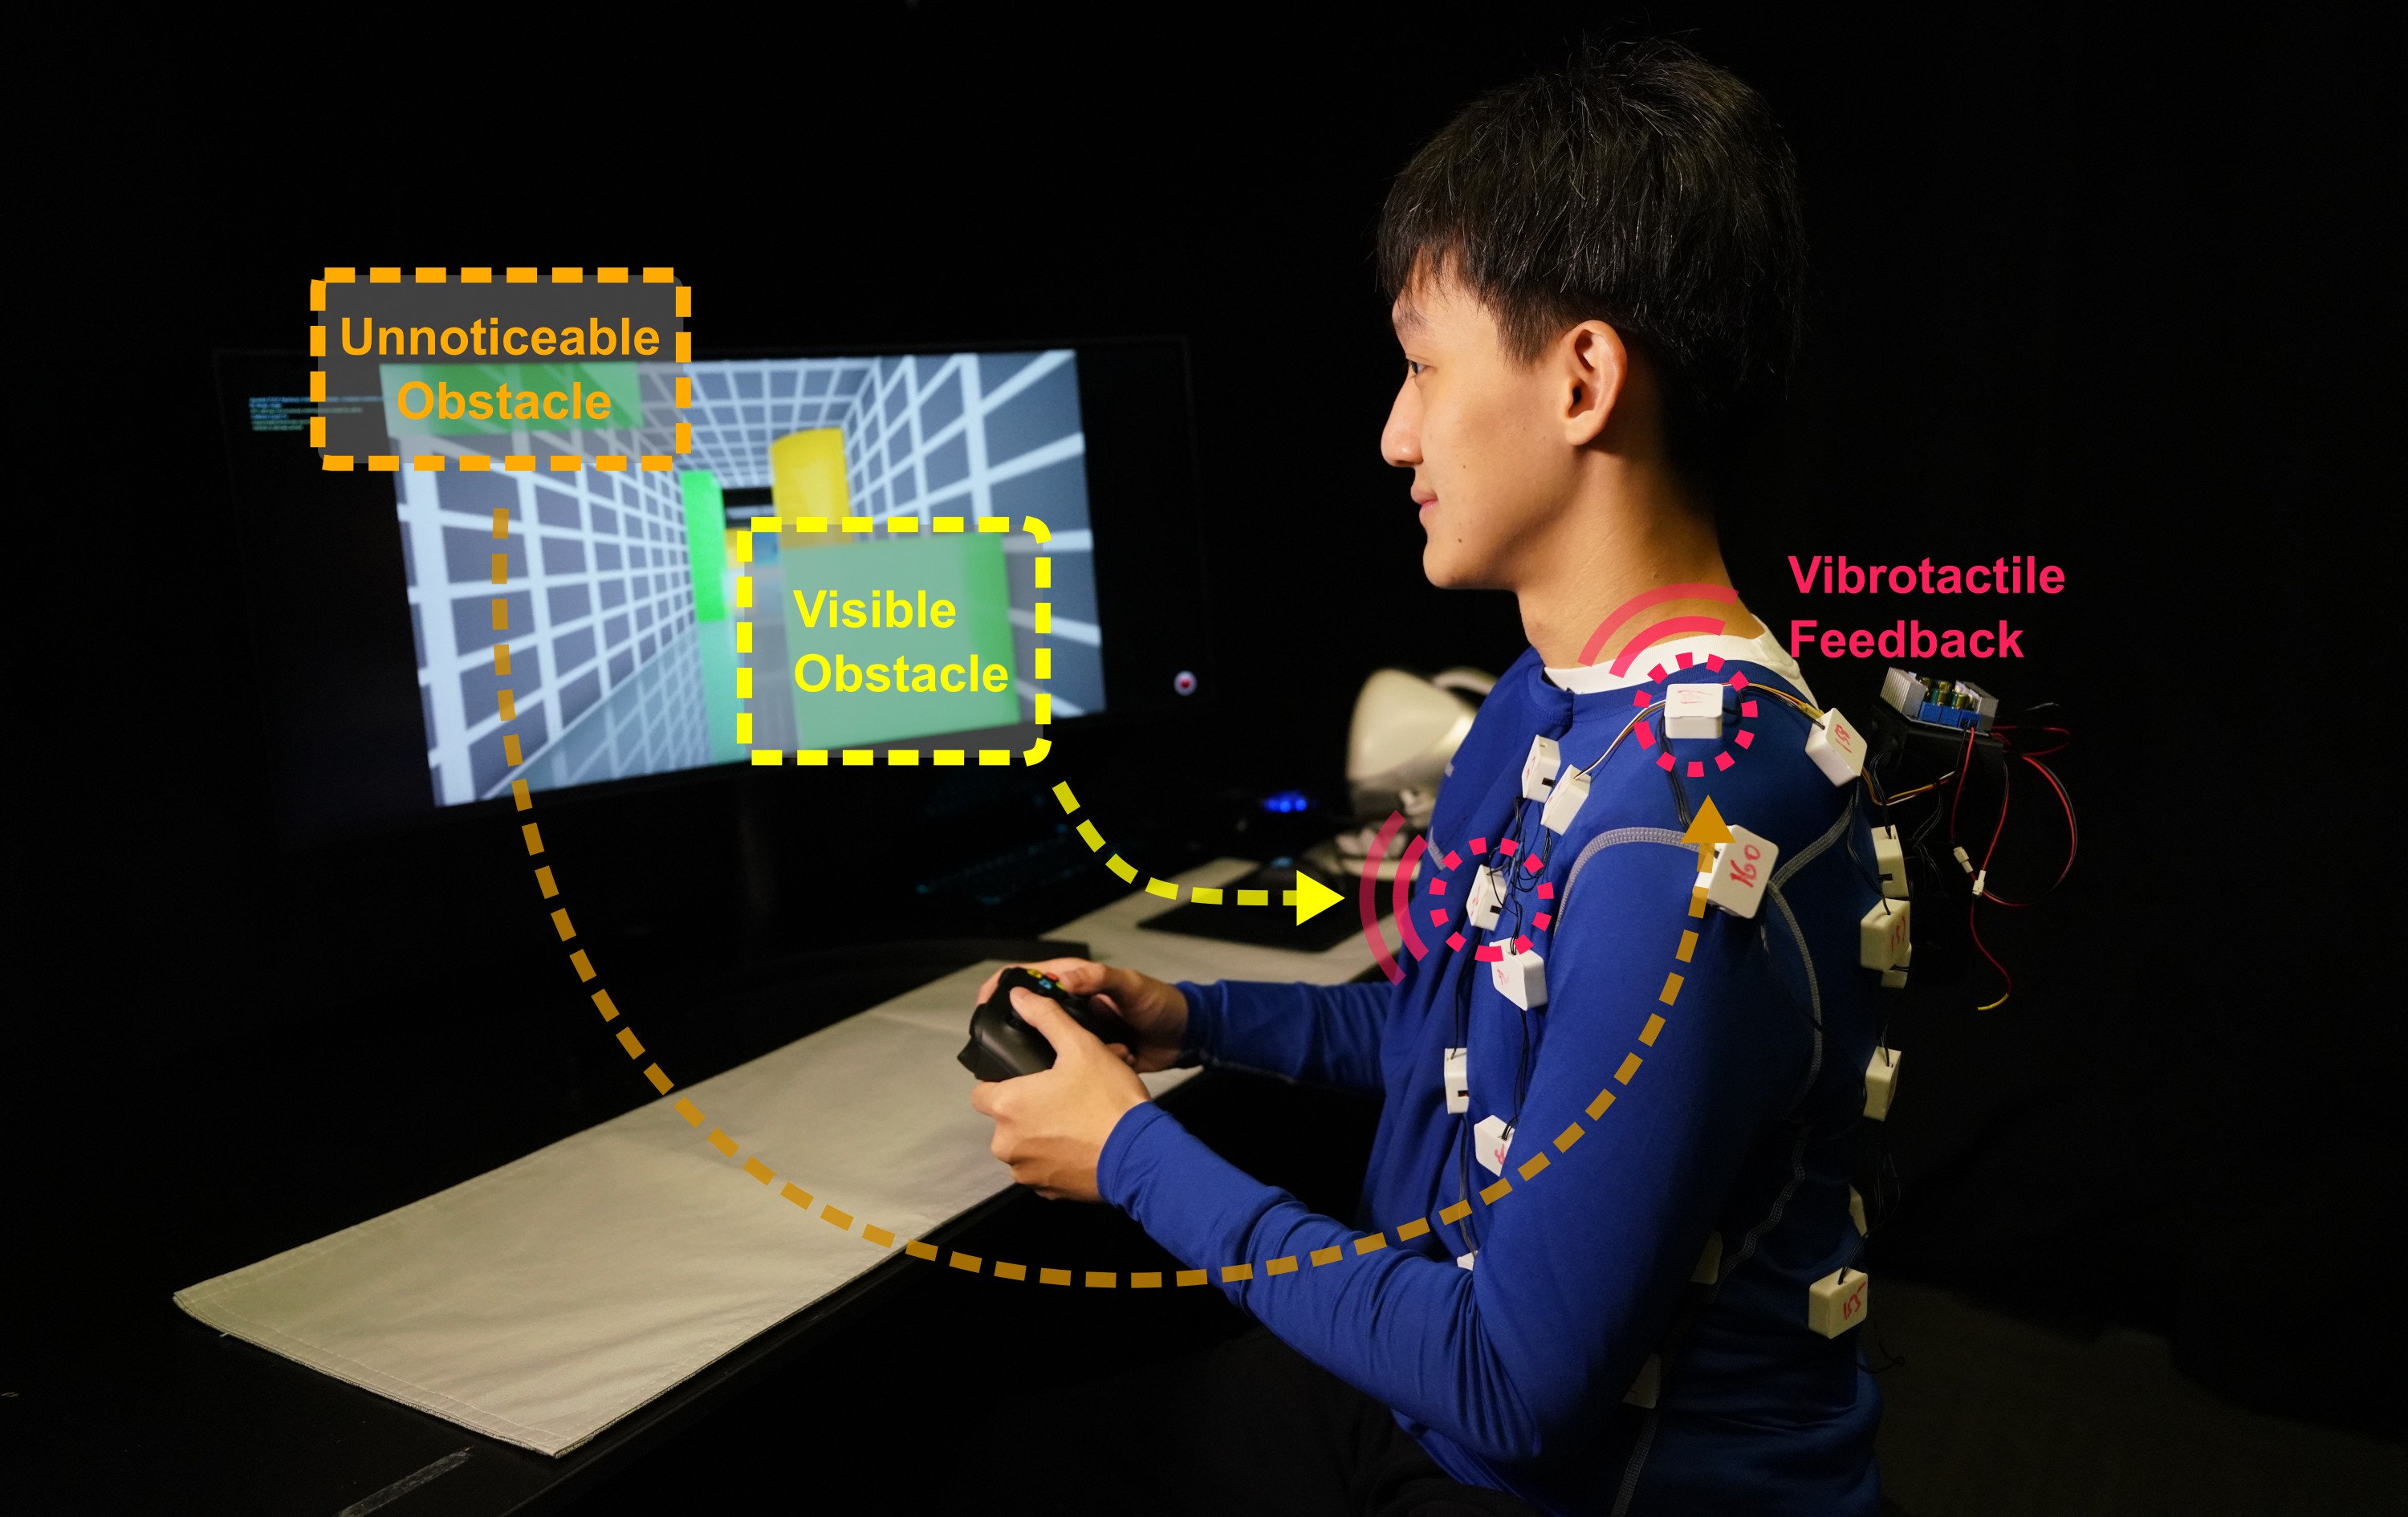
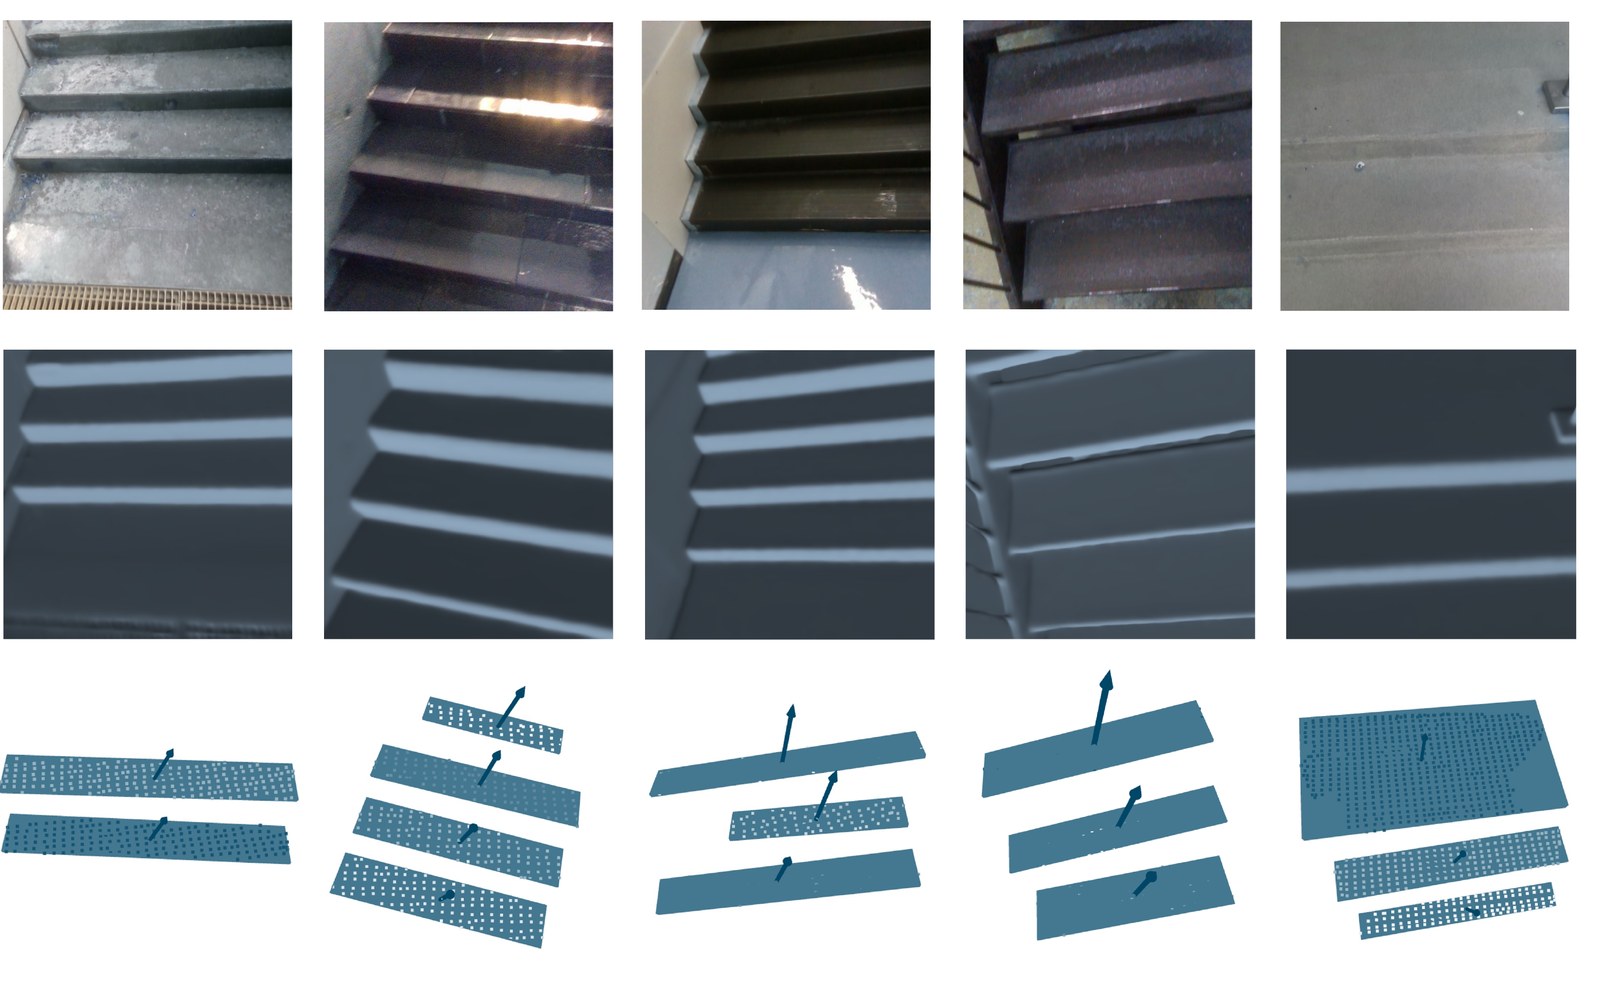
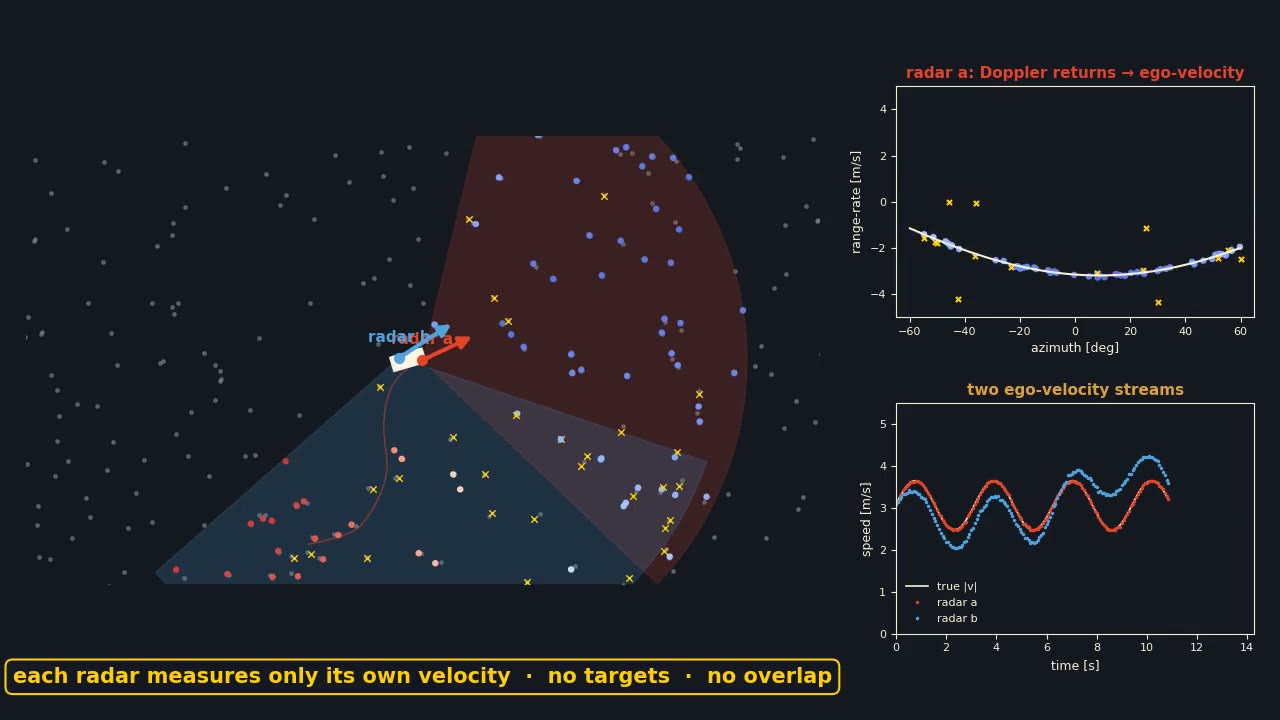
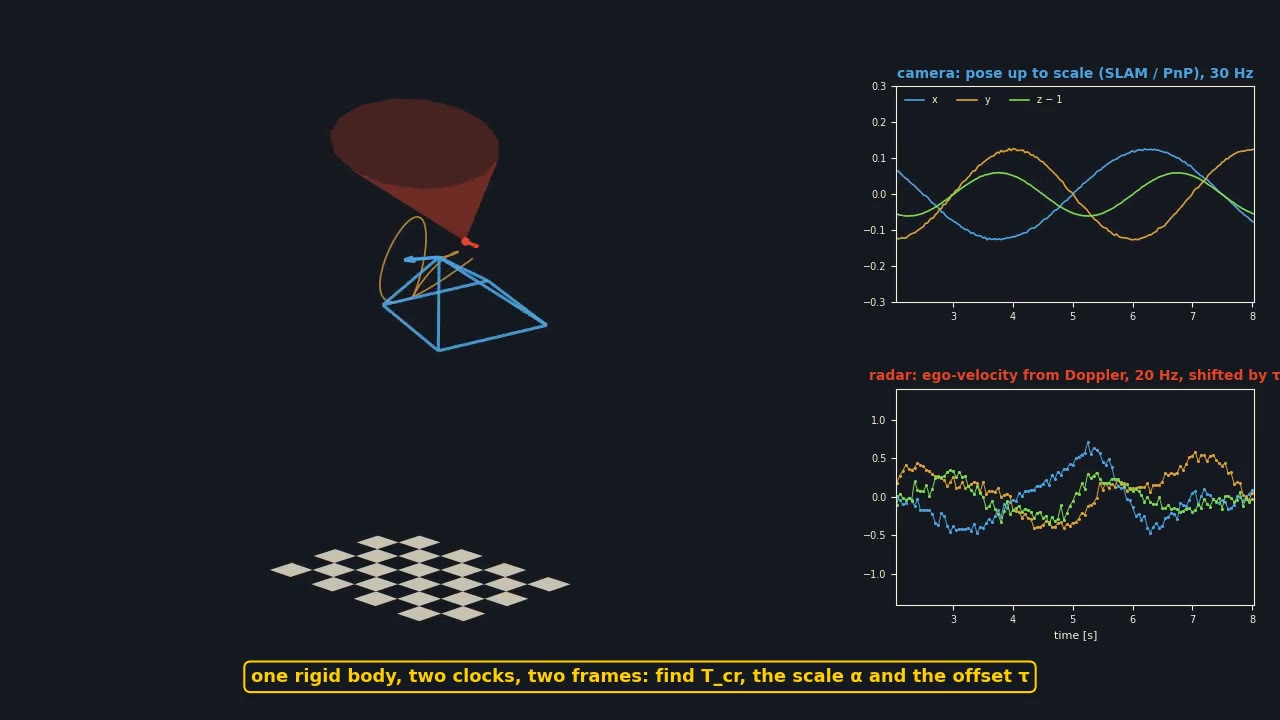
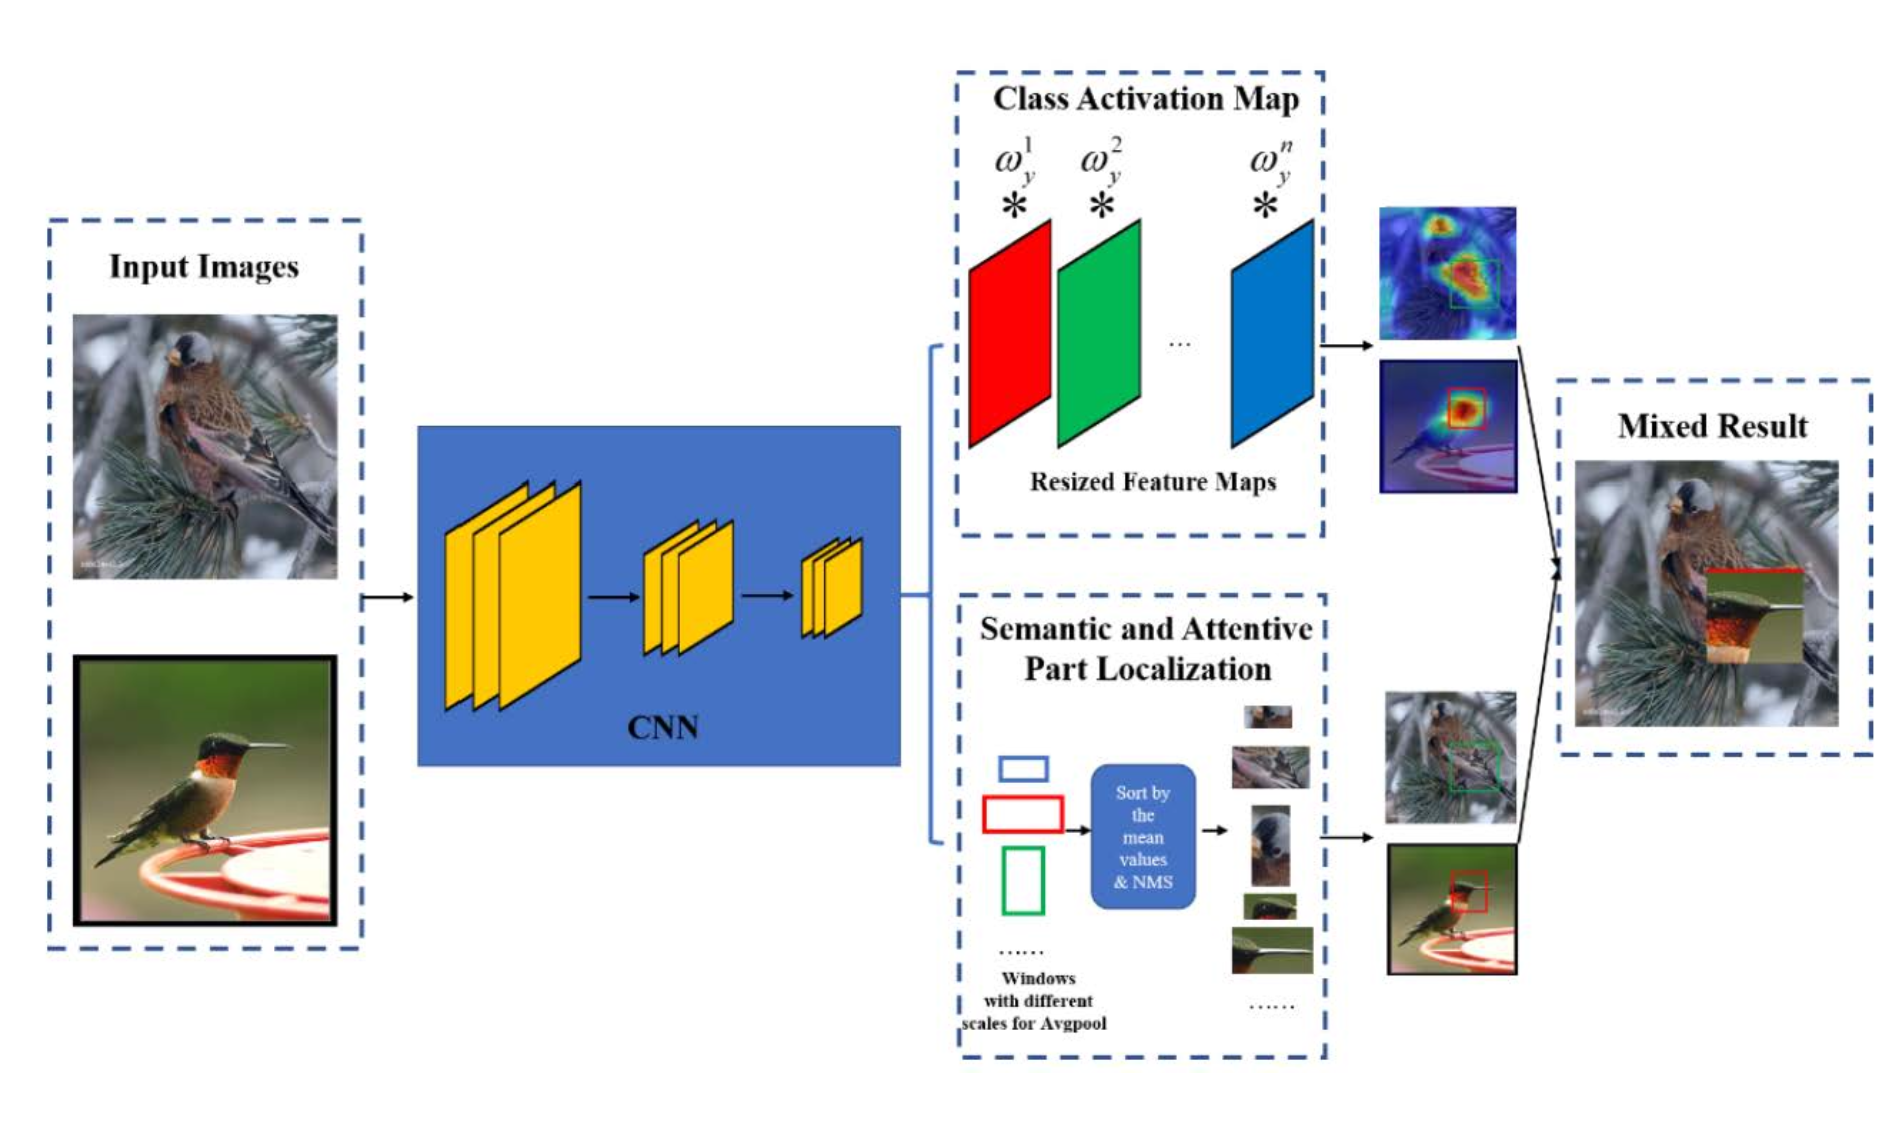
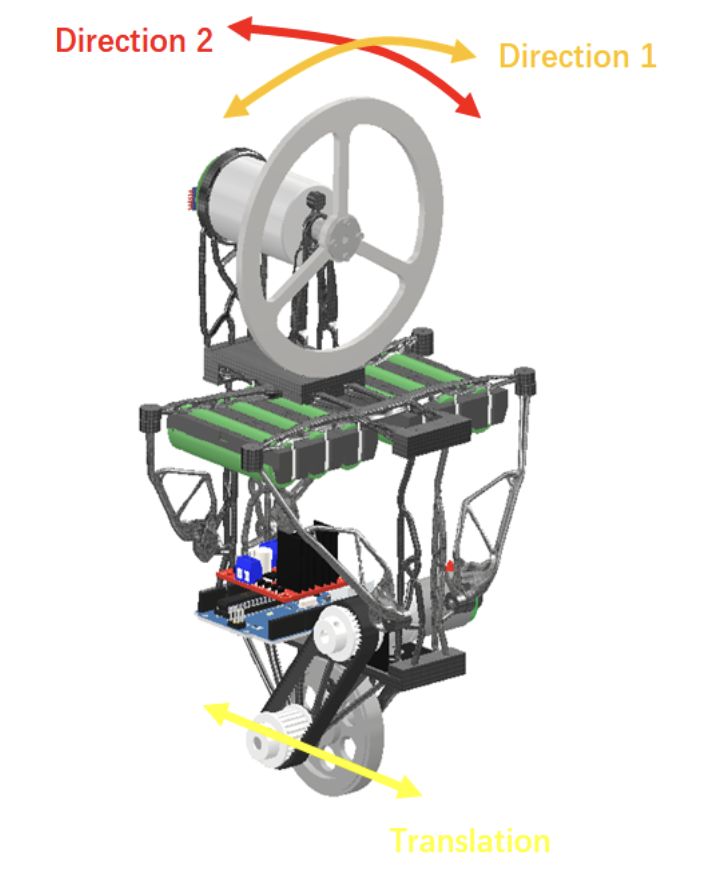
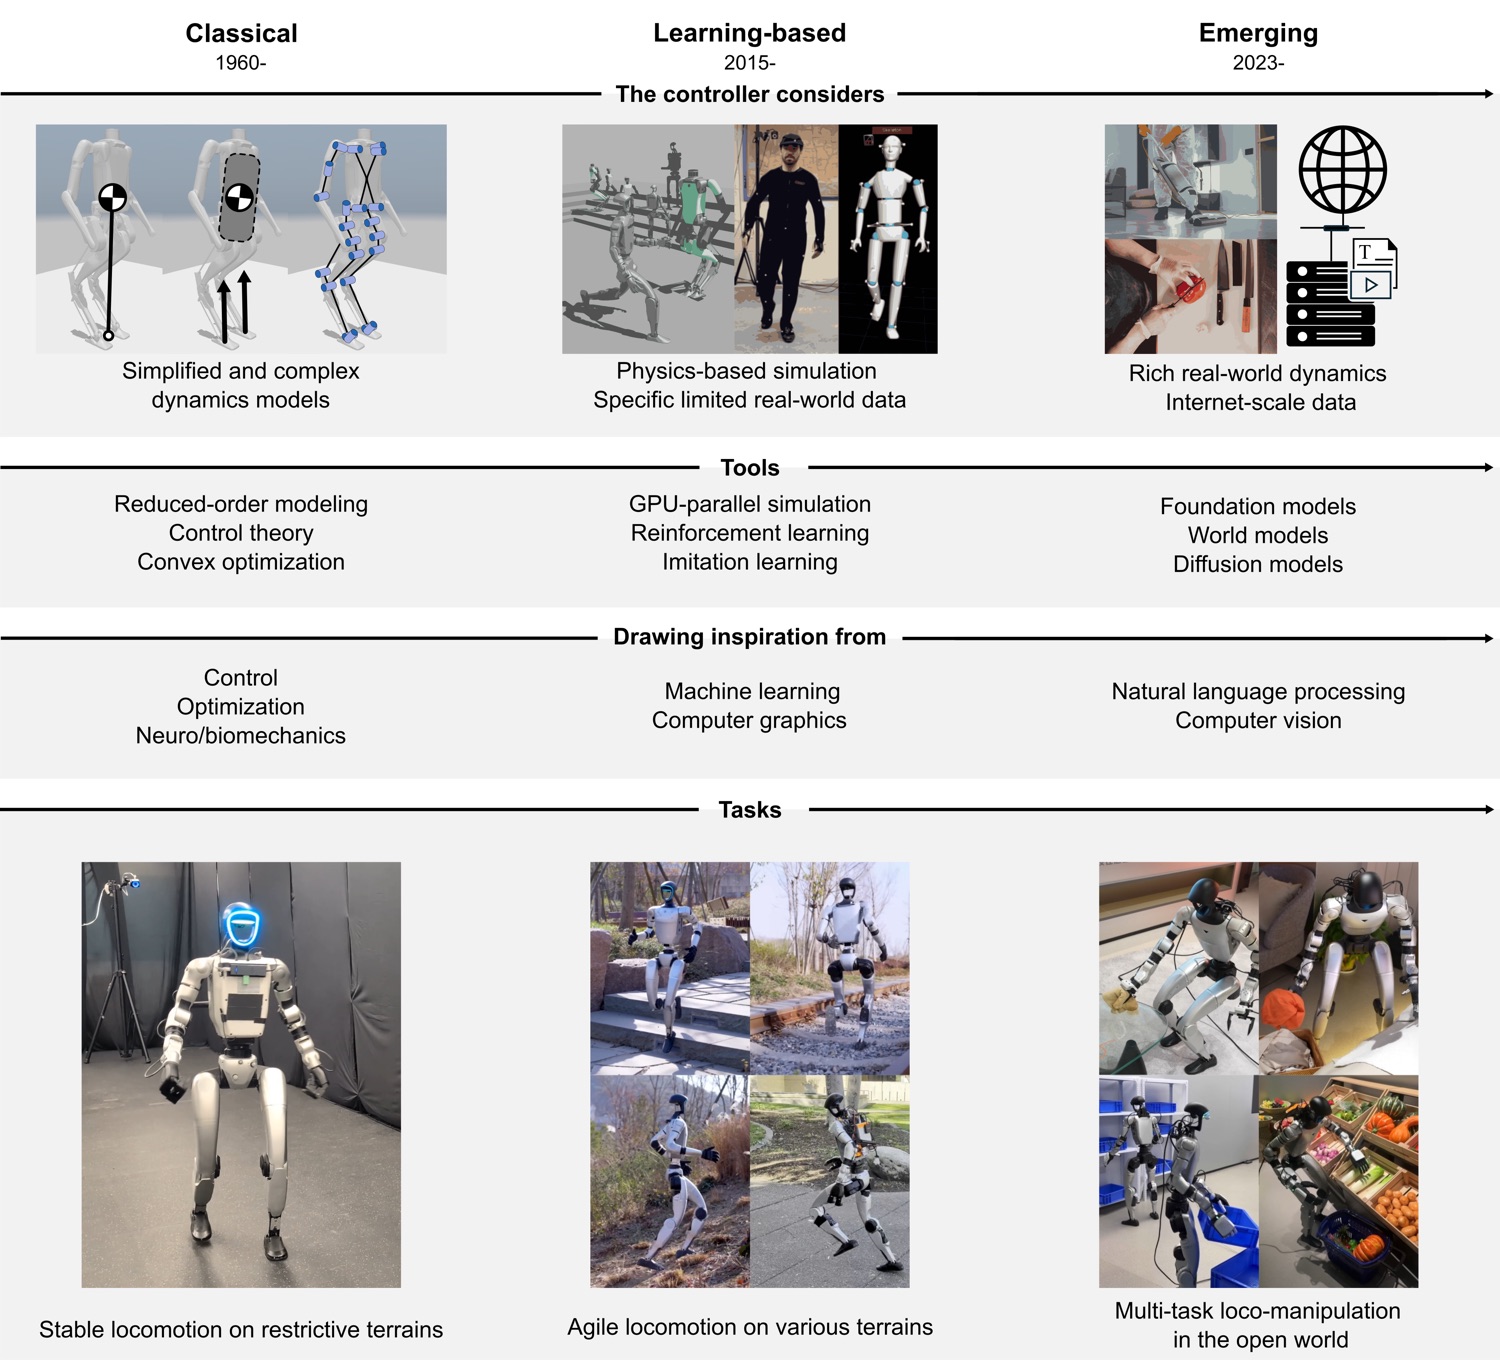
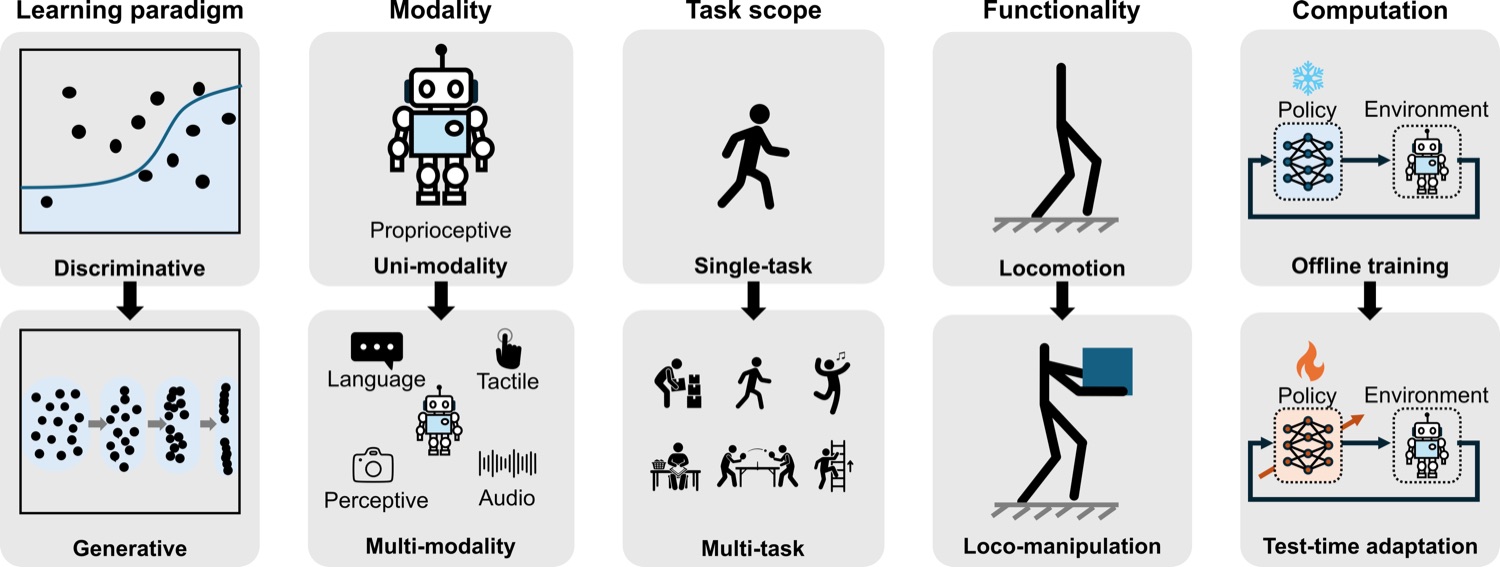
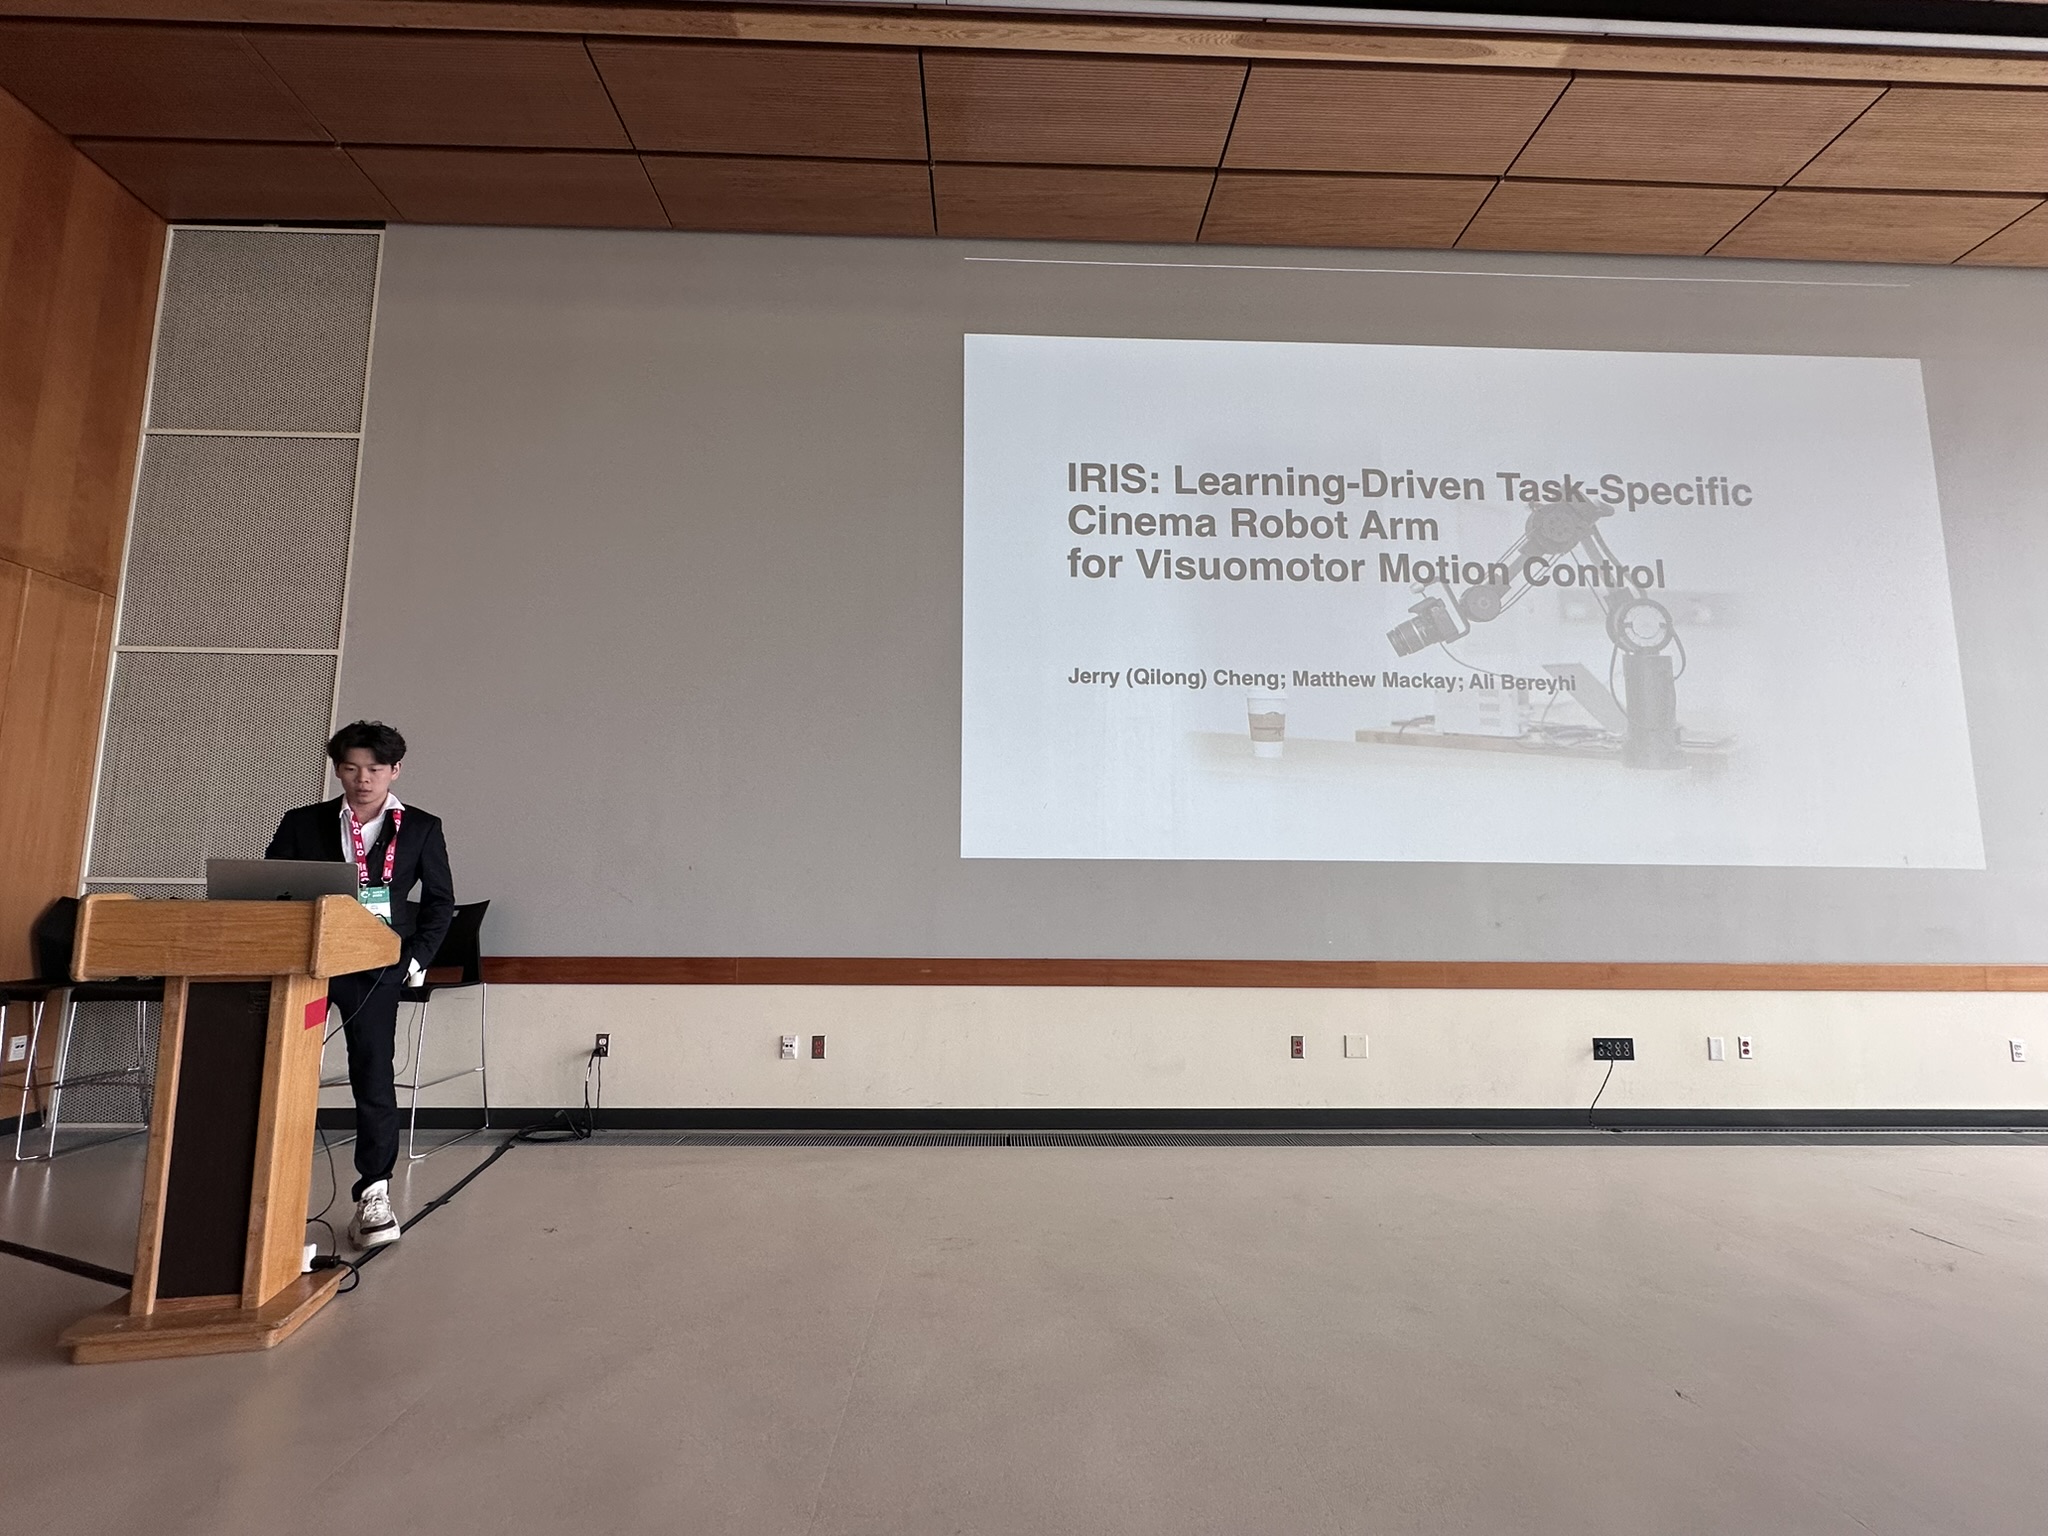
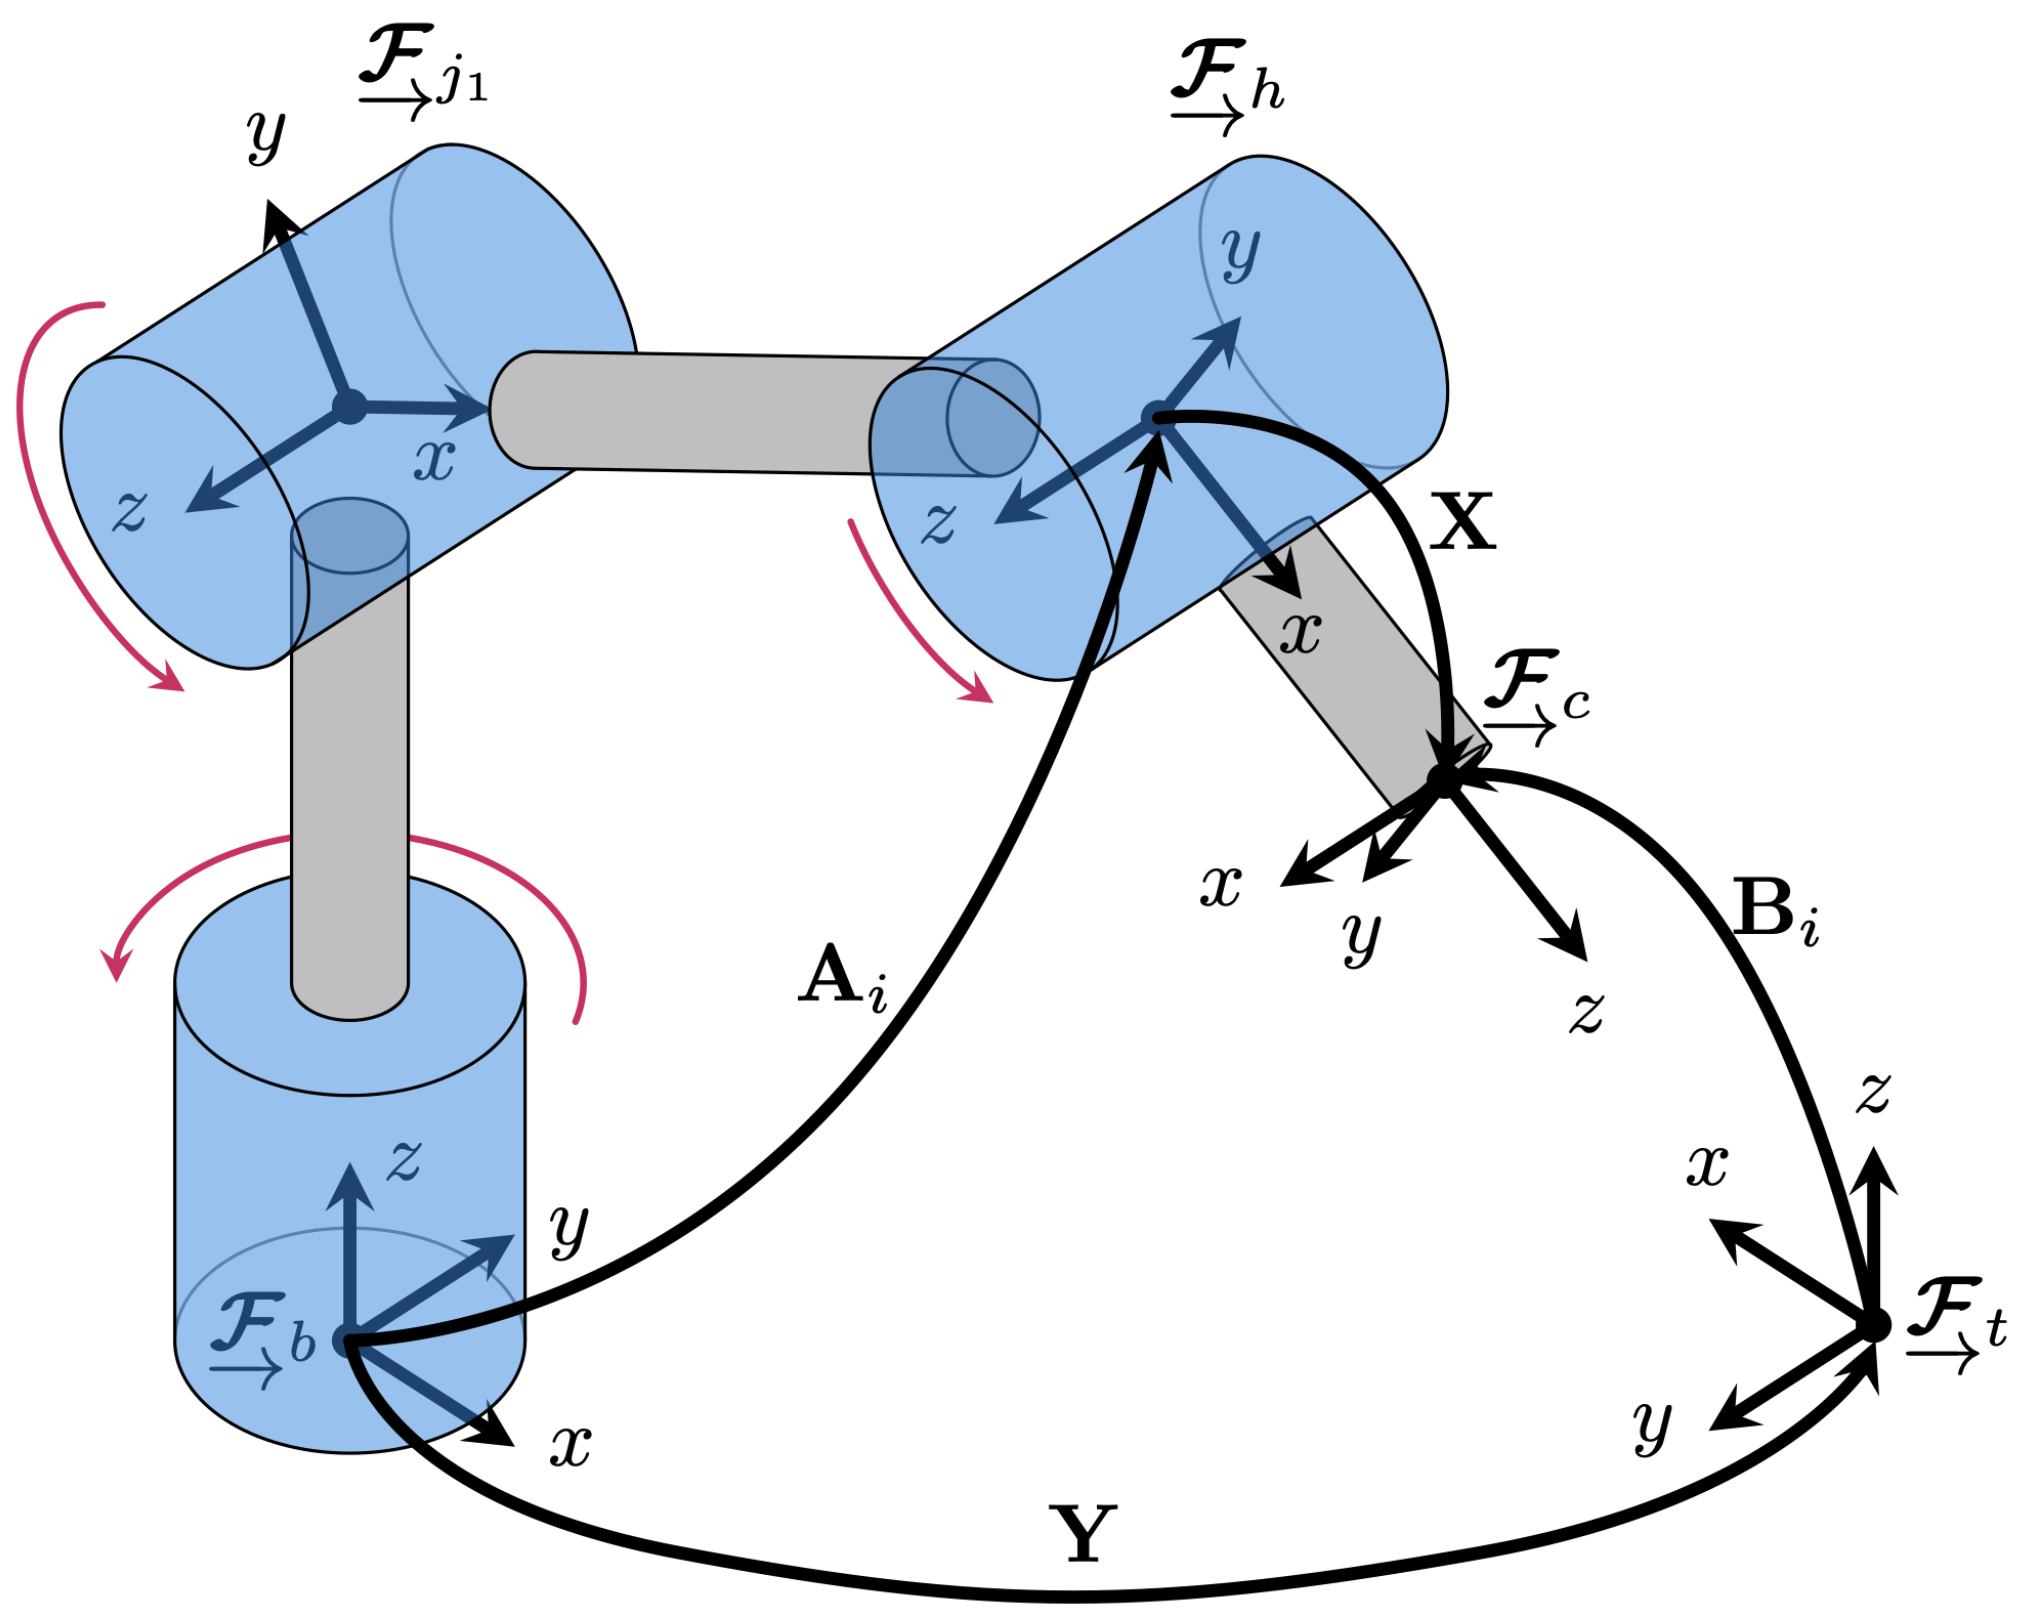
Fig. 1 — Evolution of humanoid locomotion control across classical, learning-based, and emerging eras Science Robotics 2026 Evolution of Humanoid Locomotion Control Y. Gu, G. Shi, F. Shi, I. Chang, Y. Wang, Q. Cheng, Z. Olkin, I. Lopez-Sanchez, Y. Feng, J. Zhang, A. D. Ames, H. Su, and K. Sreenath Quick look IRIS cinema robot arm CRV (Oral, top 10%) 2026 IRIS: Learning-Driven Task-Specific Cinema Robot Arm for Visuomotor Motion Control Q. Cheng, M. Mackay and A. Bereyhi Quick look A camera orbiting an AprilTag target: the AX = YB kinematic loop IJRR 2025 Certifiably correct hand-eye calibration E. Wise, P. Kaveti, Q. Cheng, W. Wang, H. Singh, J. Kelly, D. M. Rosen, and M. Giamou Quick look IRIS cinema robot arm thesis cover M.Eng. Thesis 2025 IRIS: A Low-Cost, 3D-Printed Cinema Robot Arm (M.Eng. Thesis) Q. Cheng, M. Mackay, A. Bereyhi Quick look VibraForge toolkit CHI 2025 VibraForge: A Scalable Prototyping Toolkit For Creating Spatialized Vibrotactile Feedback Systems B. Huang, S. Ren, Y. Luo, Q. Cheng, H. Cai, Y. Sang, M. Sousa, P. H. Dietz, and D. Wigdor Quick look AeroHaptix UAV teleoperation IEEE RA-L 2024 AeroHaptix: A Wearable Vibrotactile Feedback System for Enhancing Collision Avoidance in UAV Teleoperation B. Huang, Z. Wang, Q. Cheng, S. Ren, H. Cai, A. Alvarez Valdivia, K. Mahadevan, and D. Wigdor Quick look Stair scenes: RGB, estimated normals, extracted tread planes TRC Poster 2024 BipedNav: stair geometry from one image, then walked A. Qiu, A. Narayanan, Q. Cheng, and B. Laschowski Quick look Two radars on a vehicle with Doppler returns and ego-velocity arrows IEEE AIM 2023 Radar-to-radar calibration from ego-velocity Q. Cheng, E. Wise, and J. Kelly Quick look Handheld radar-camera rig flying along a continuous-time B-spline IEEE TRO 2022 Radar-camera spatiotemporal calibration E. Wise, Q. Cheng, and J. Kelly Quick look Weakly supervised augmentation overview IEEE Access 2022 Weakly Supervised Semantic and Attentive Data Mixing Augmentation for Fine-Grained Visual Categorization M. He, Q. Cheng, and G. Qi Quick look Generative design for a unicycle robot SPIE ACAIB 2022 Generative Design for Self-Balancing Unicycle Robot in Additive Manufacturing J. Chen, Q. Cheng, and M. Han Quick look

Projects

All projects
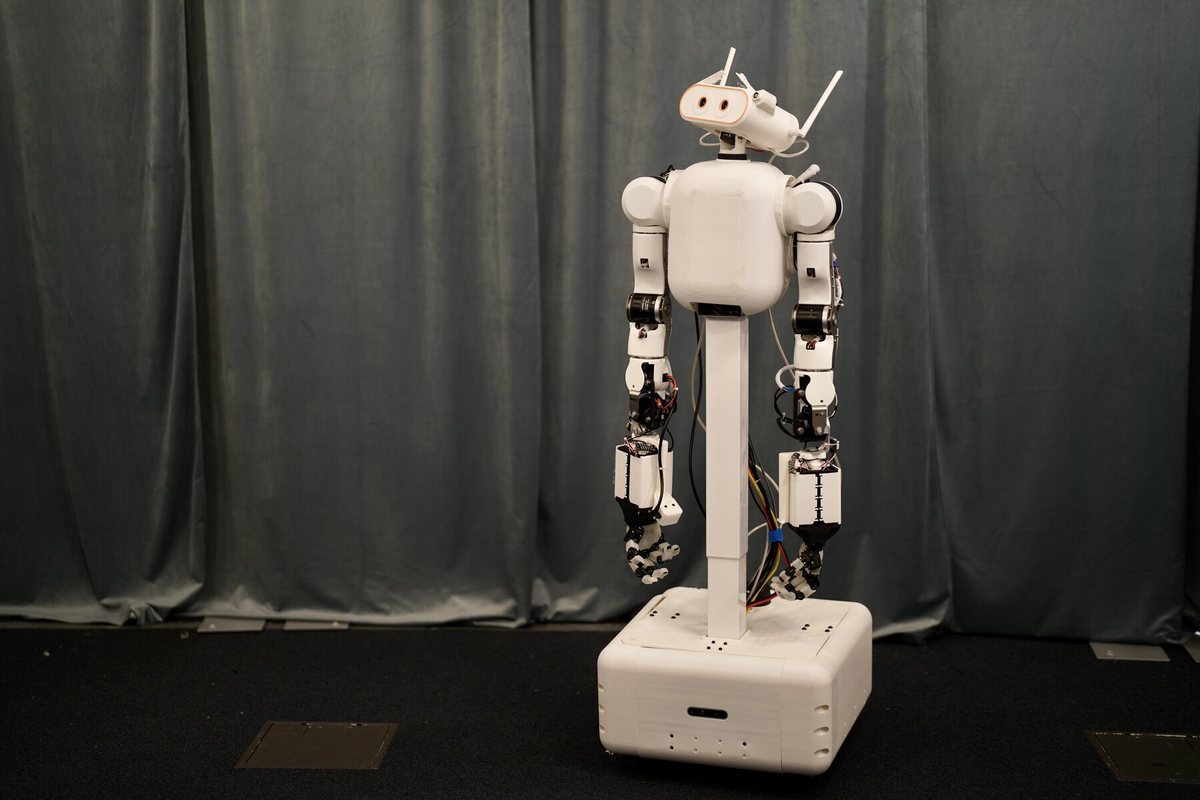
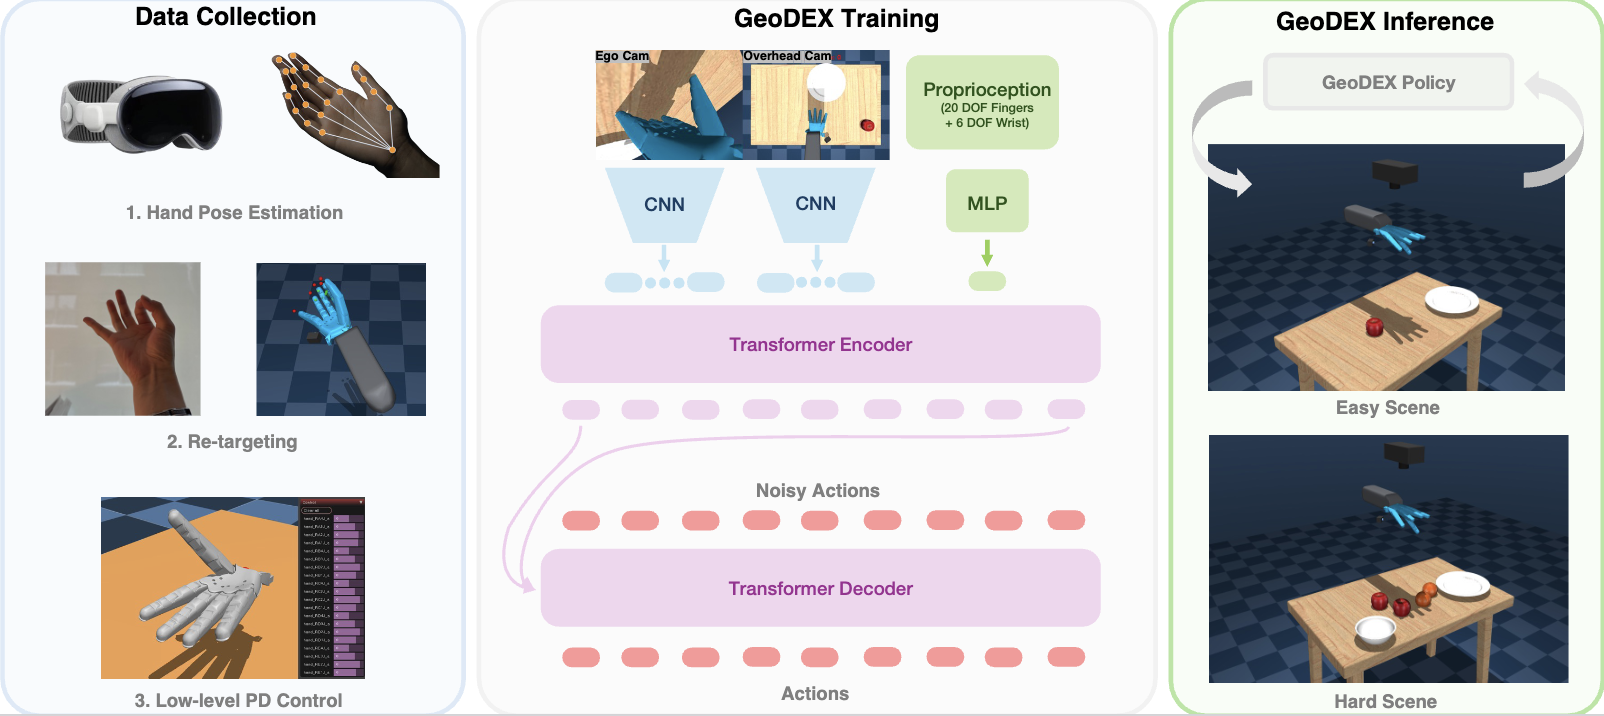
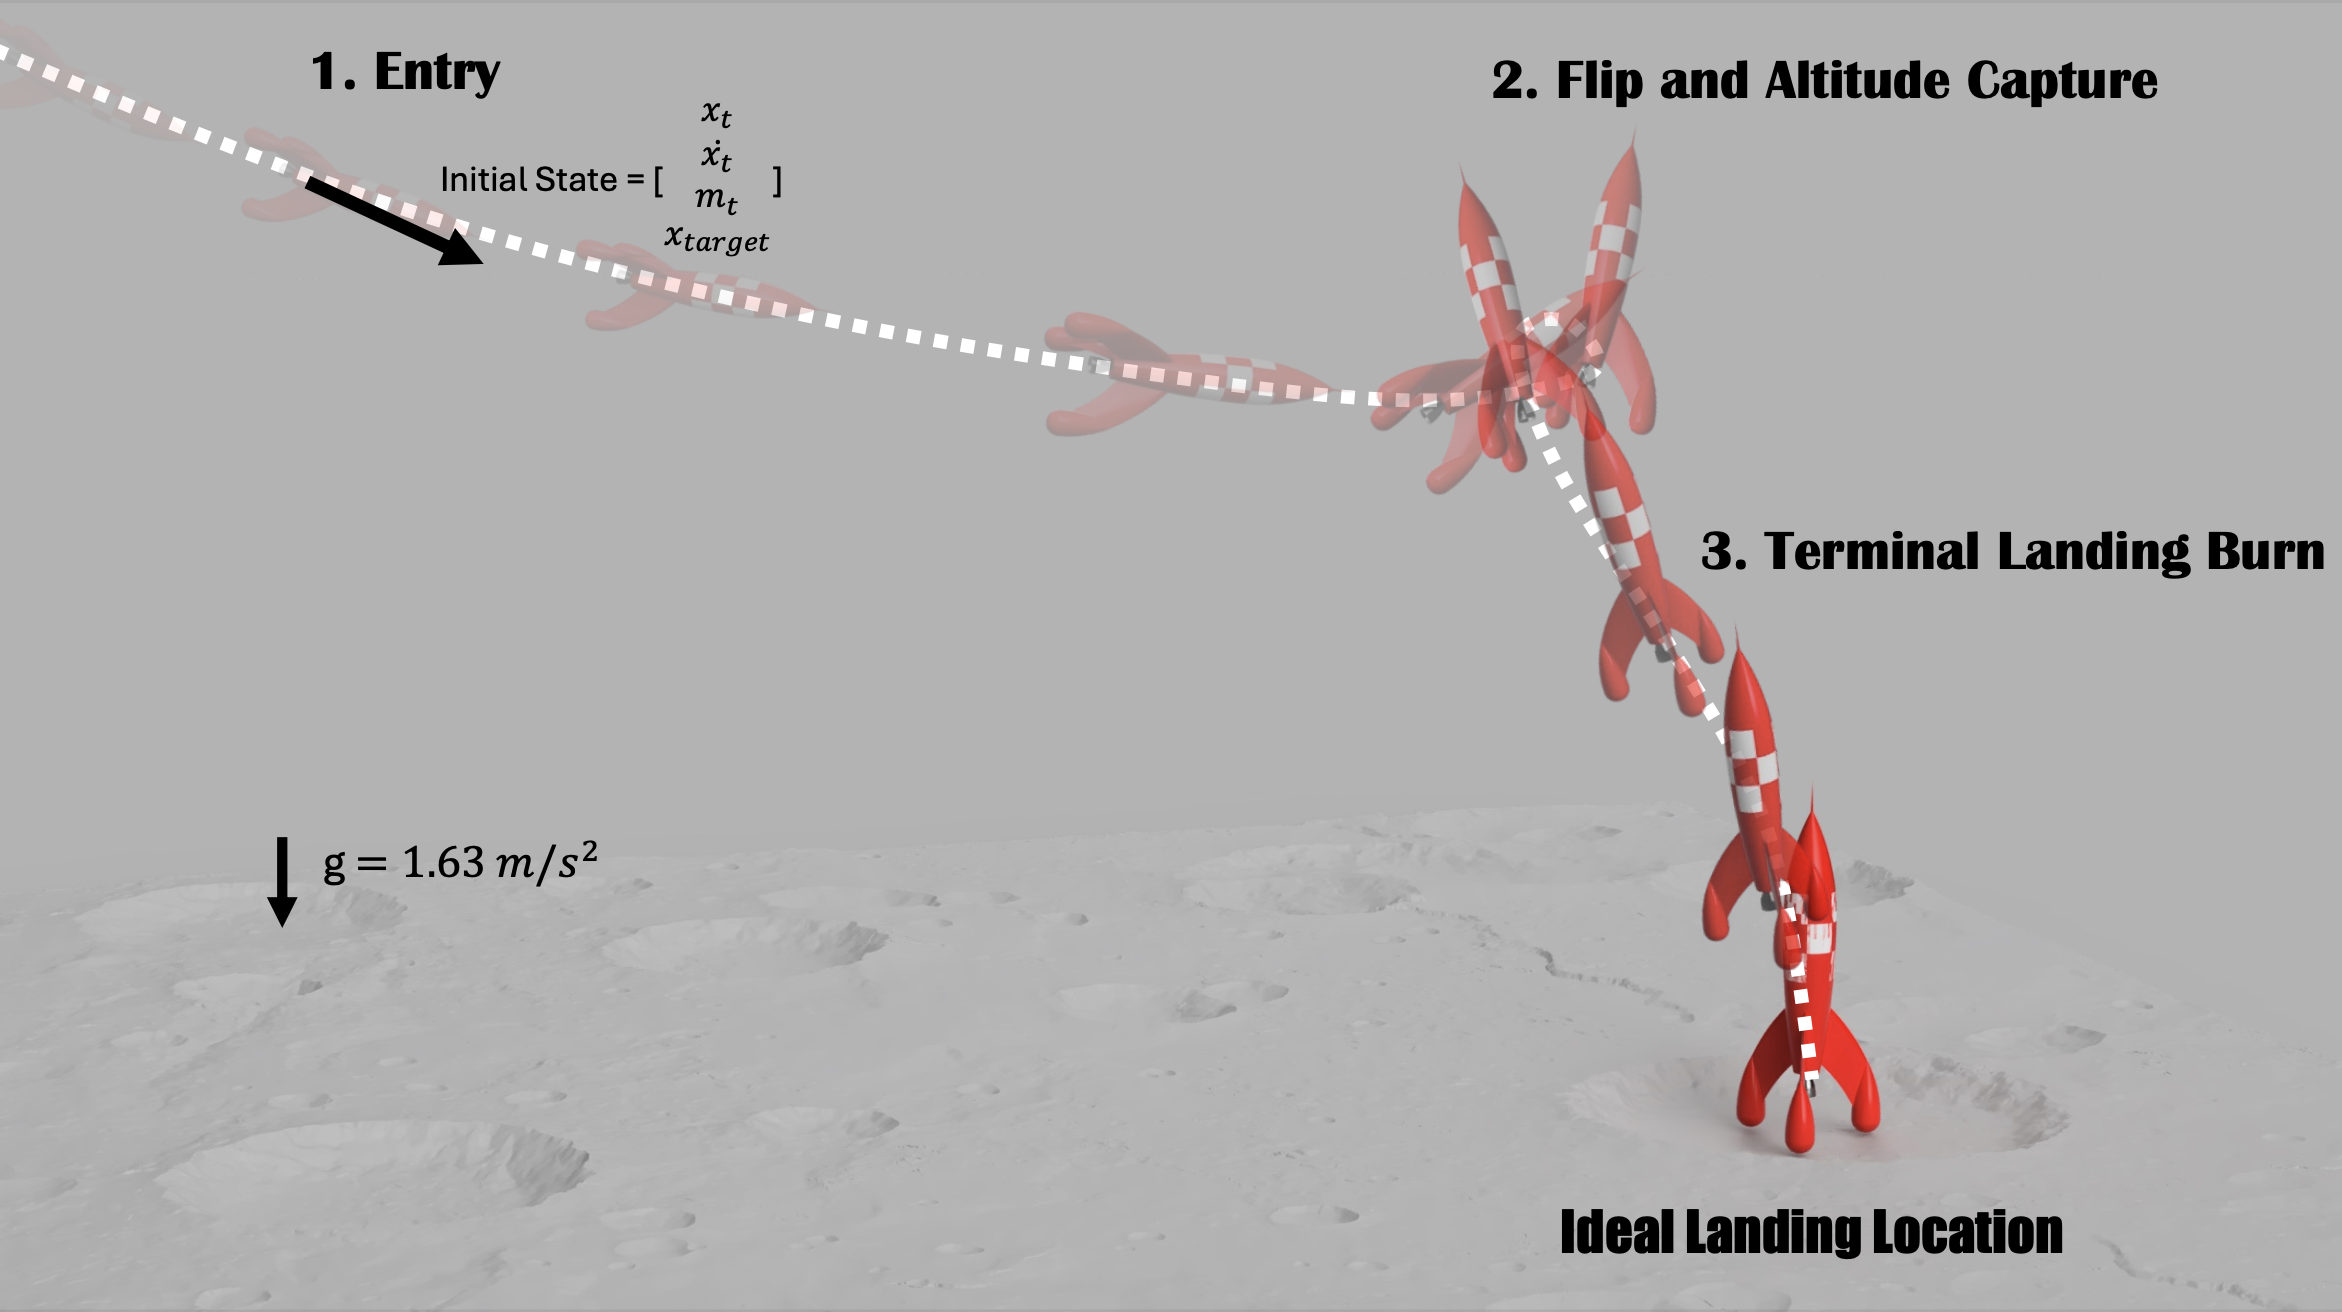
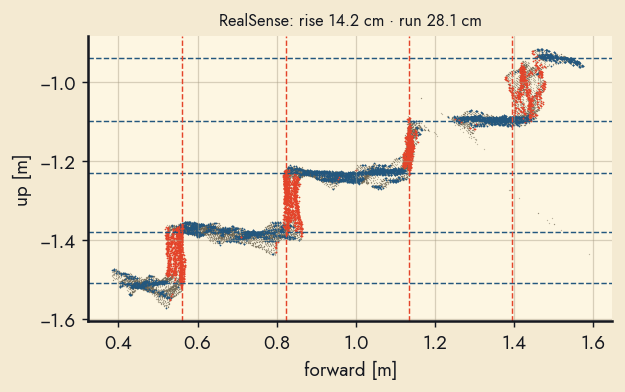
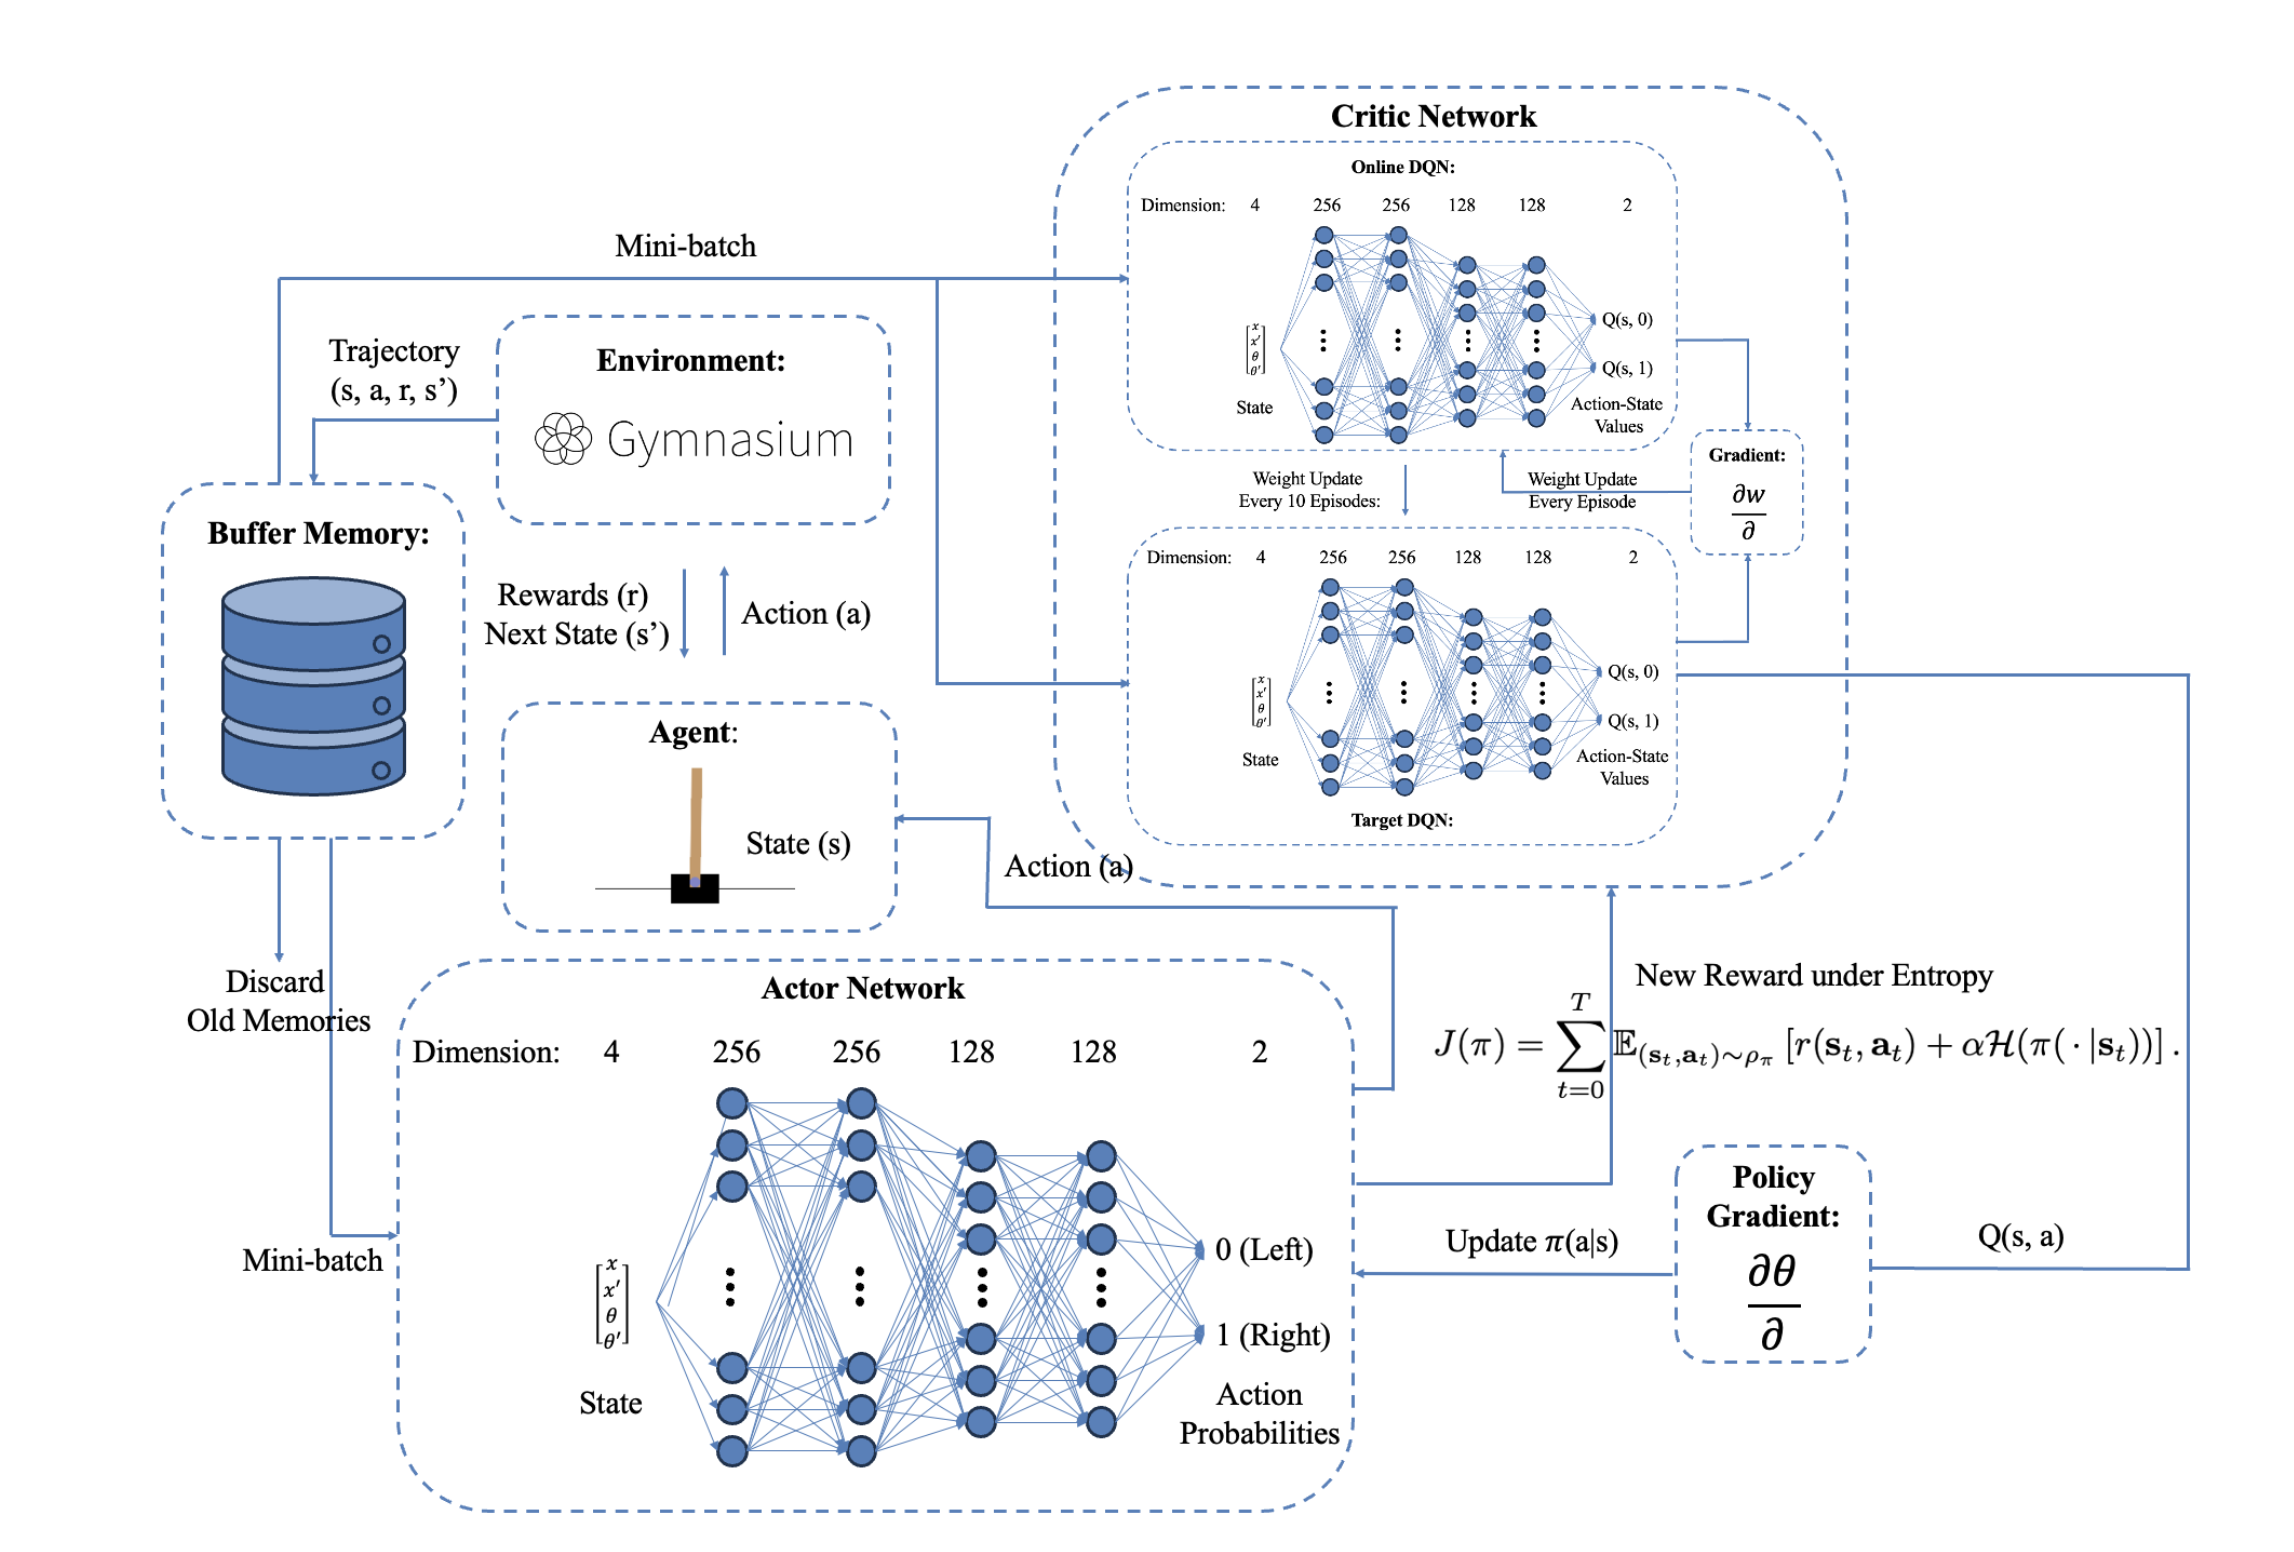
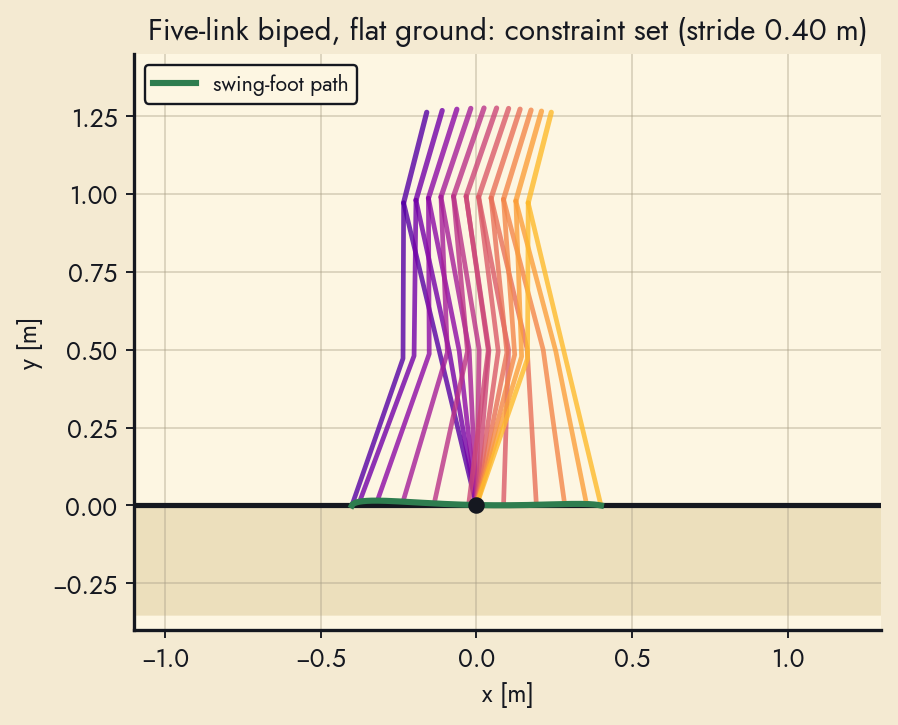
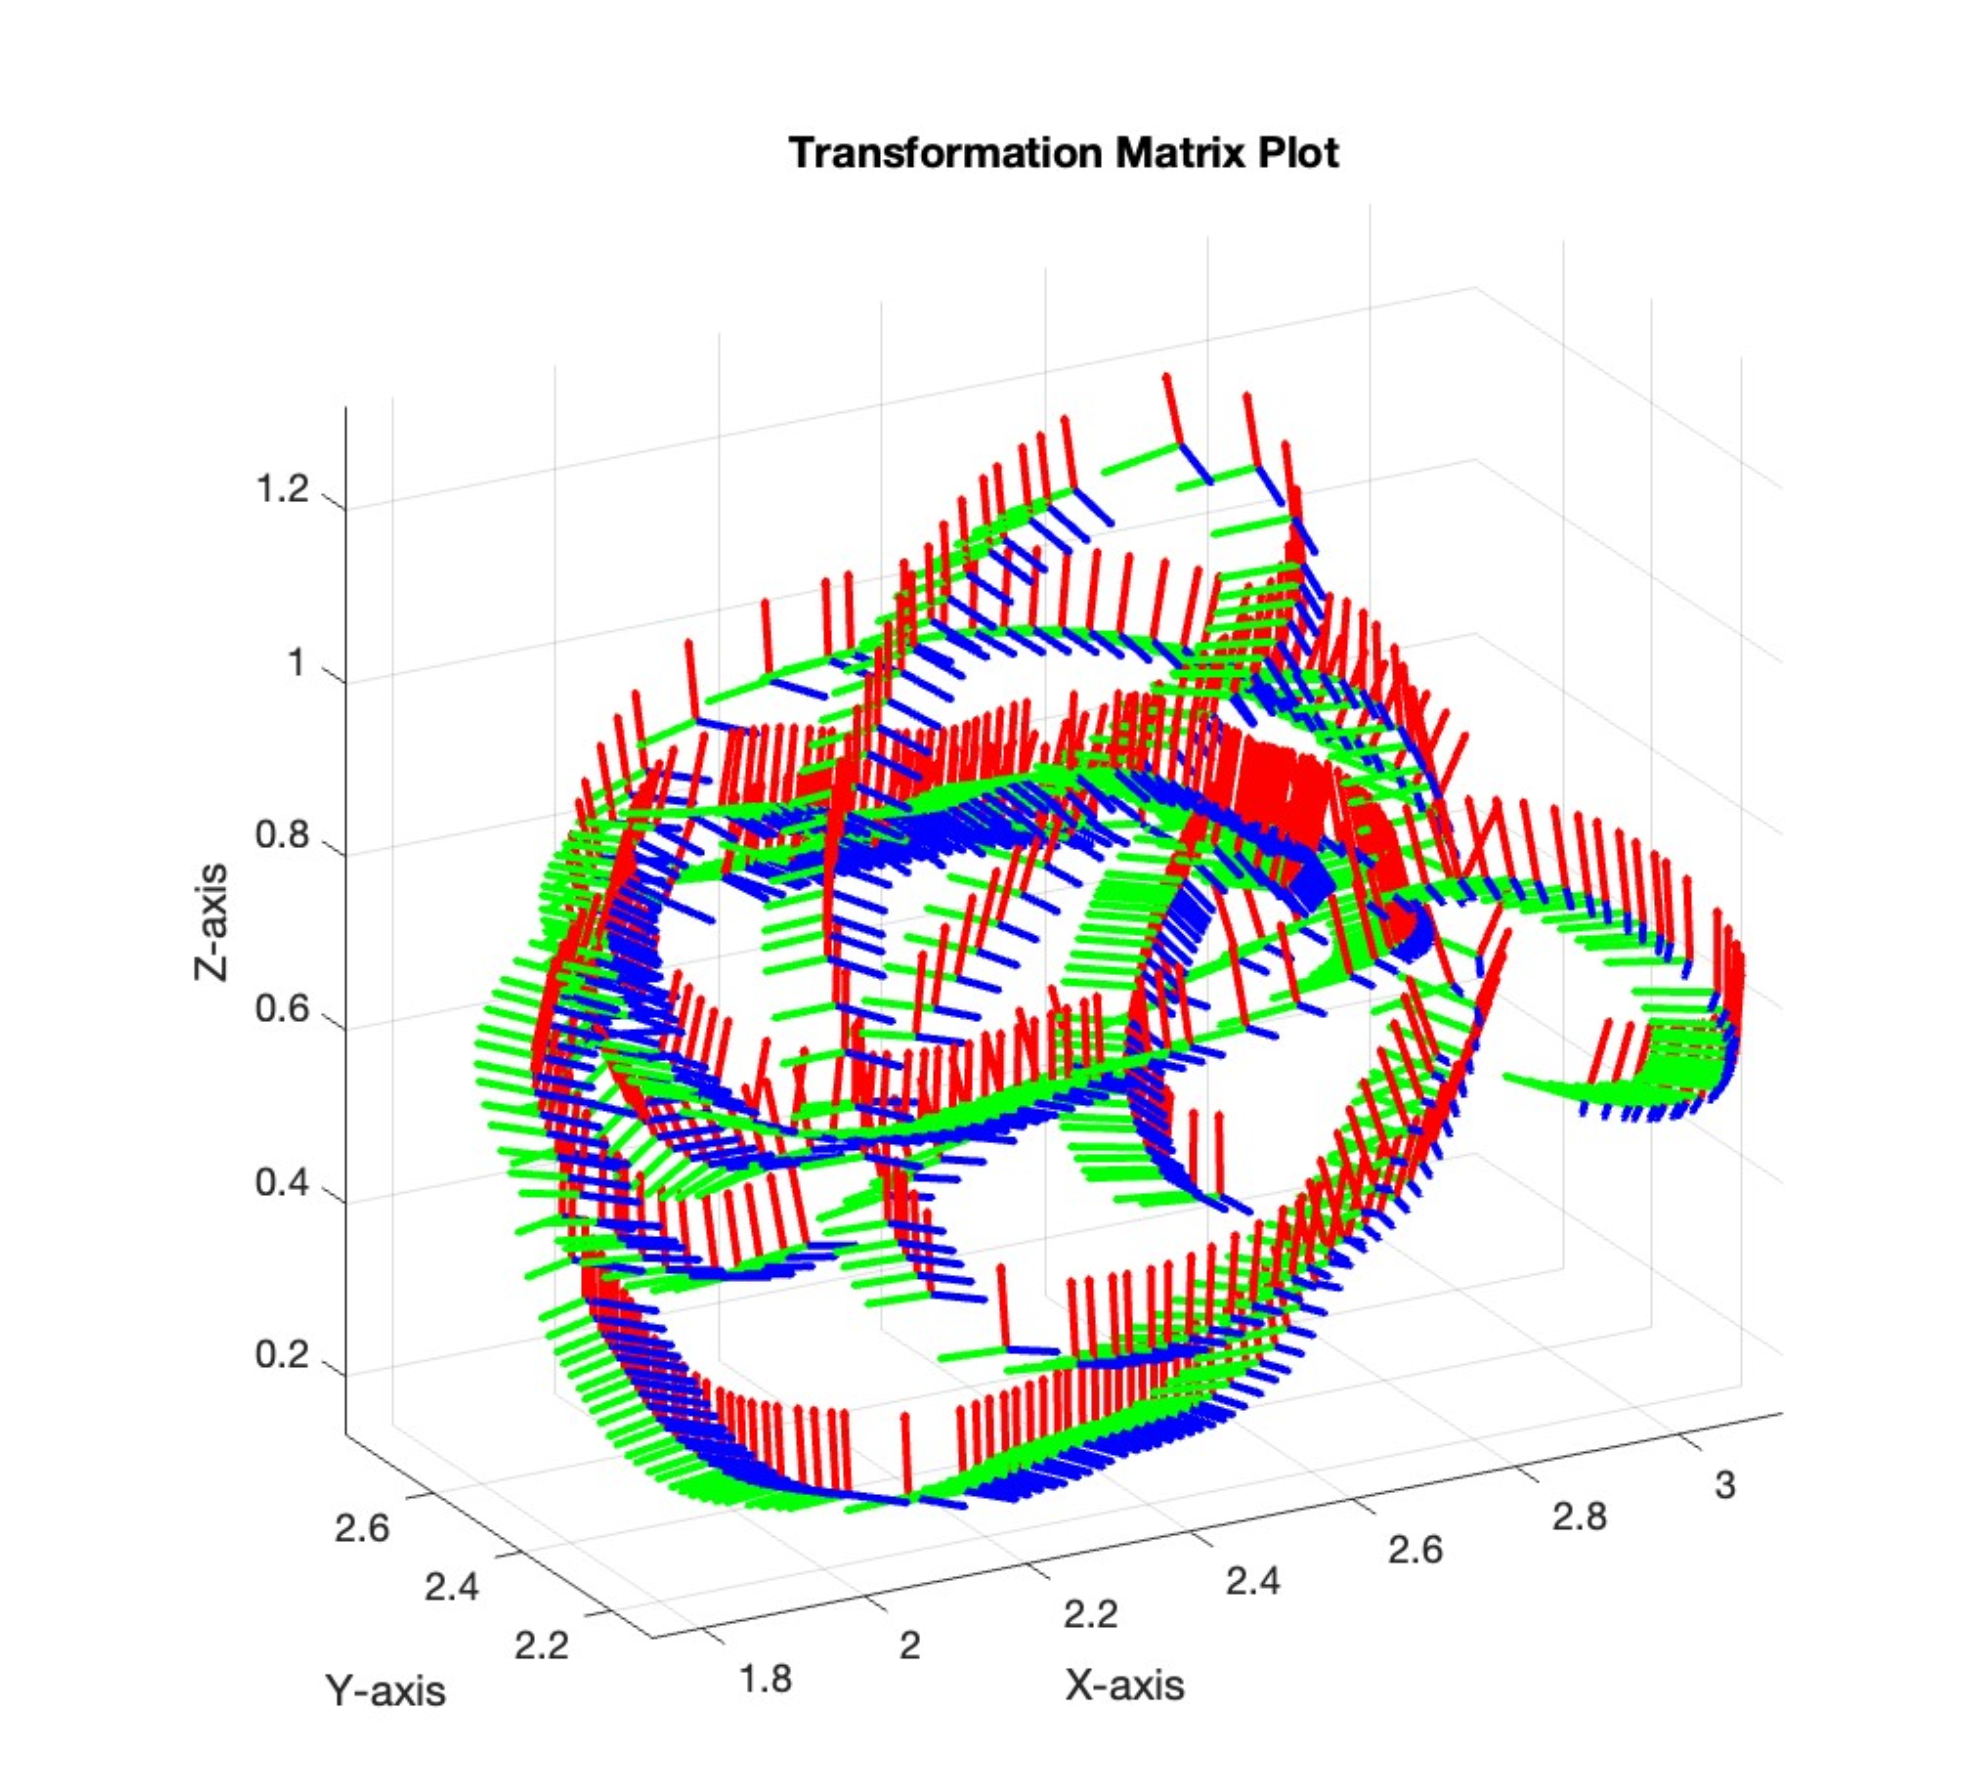
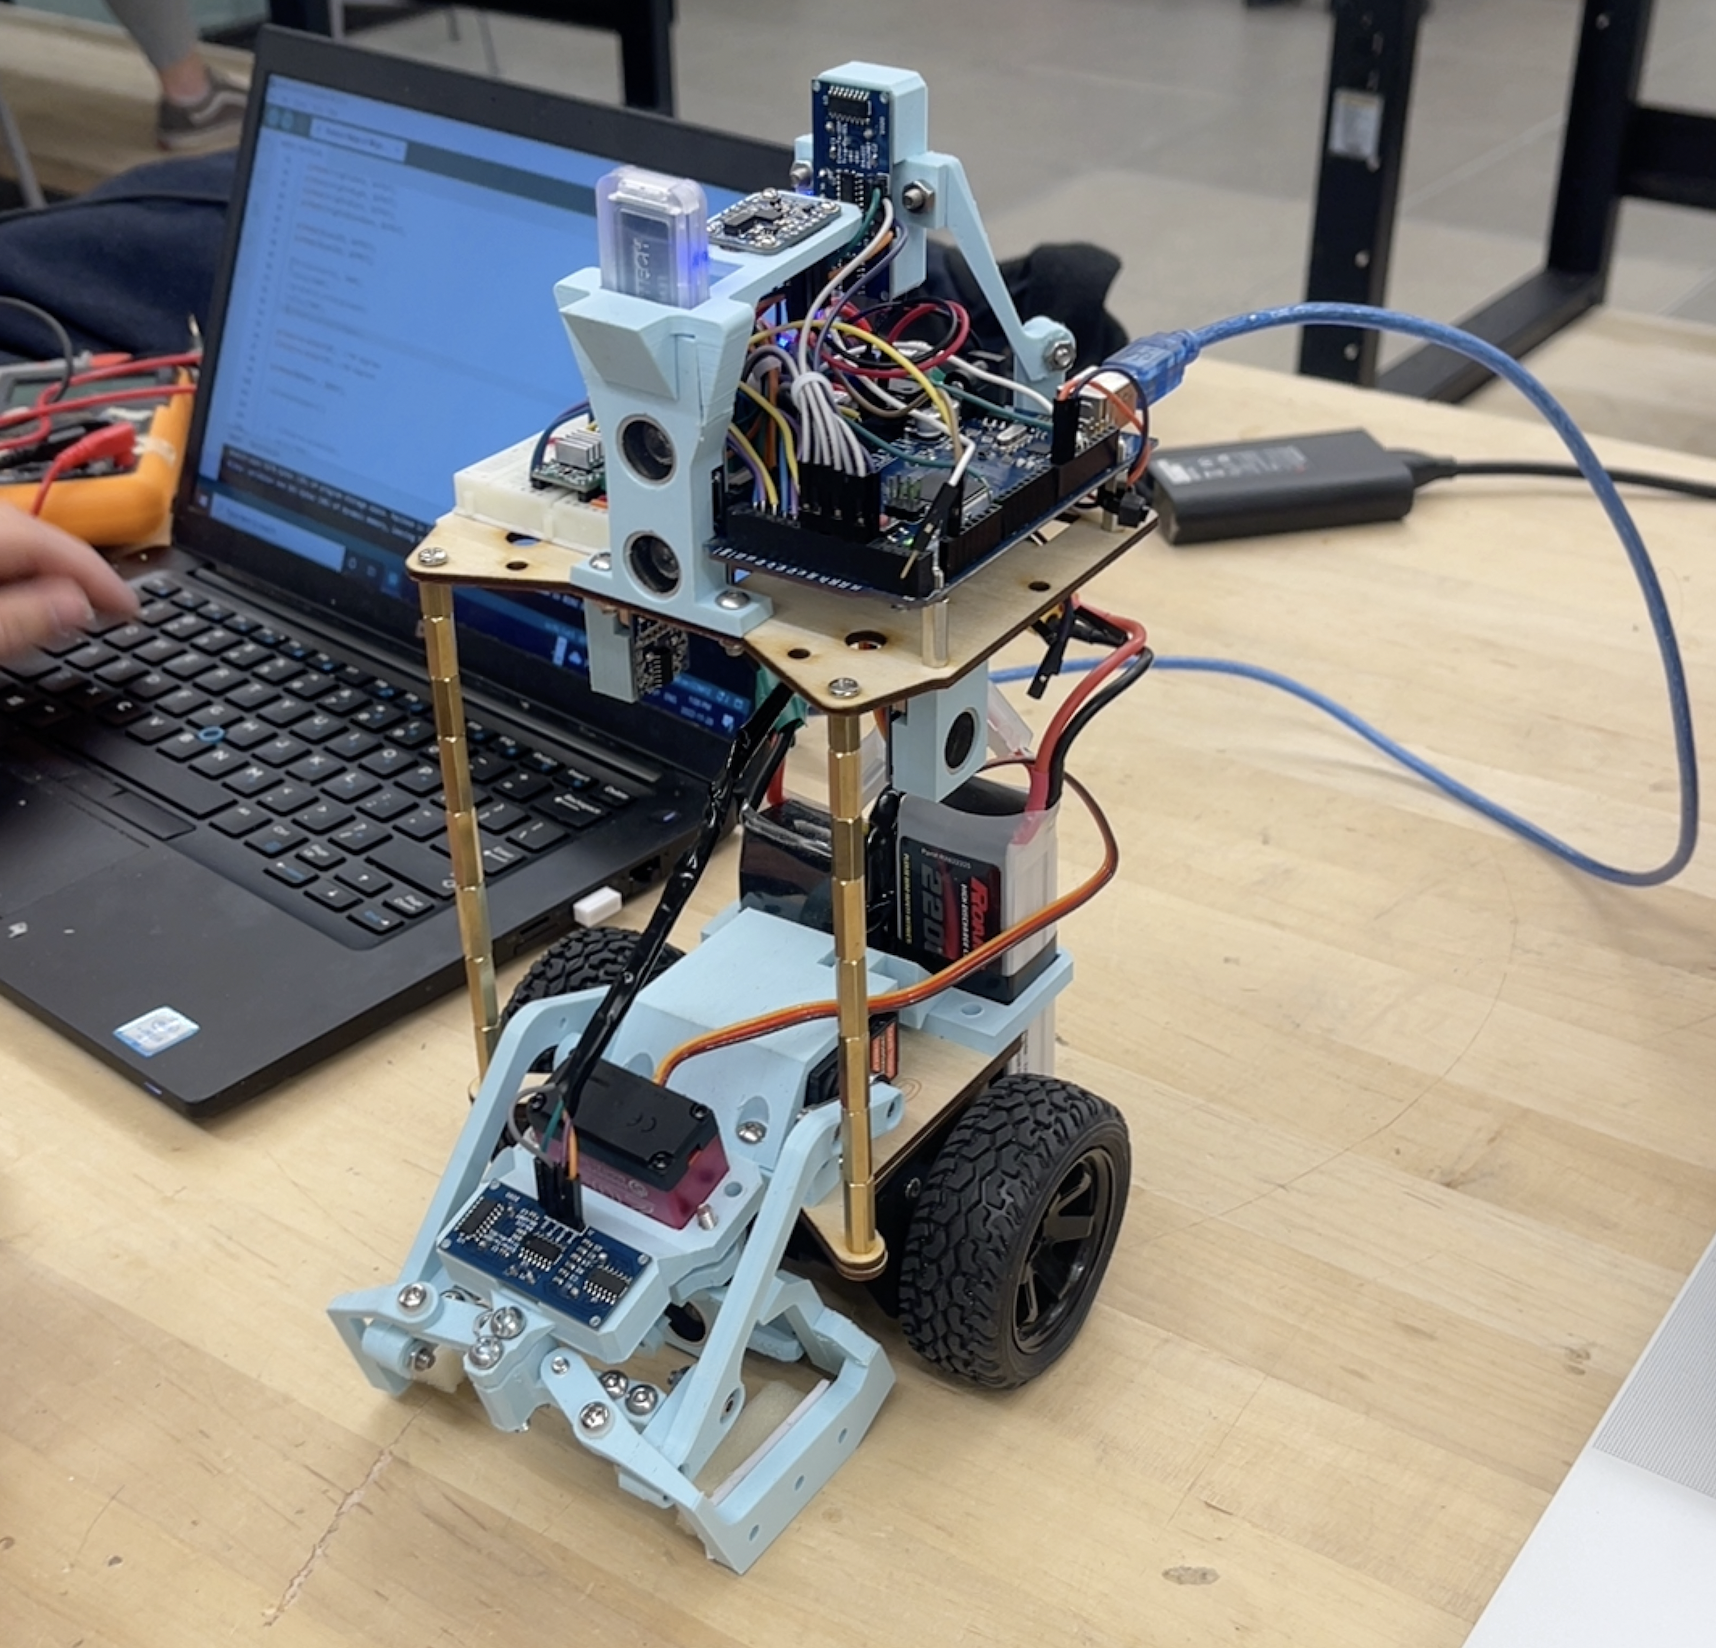
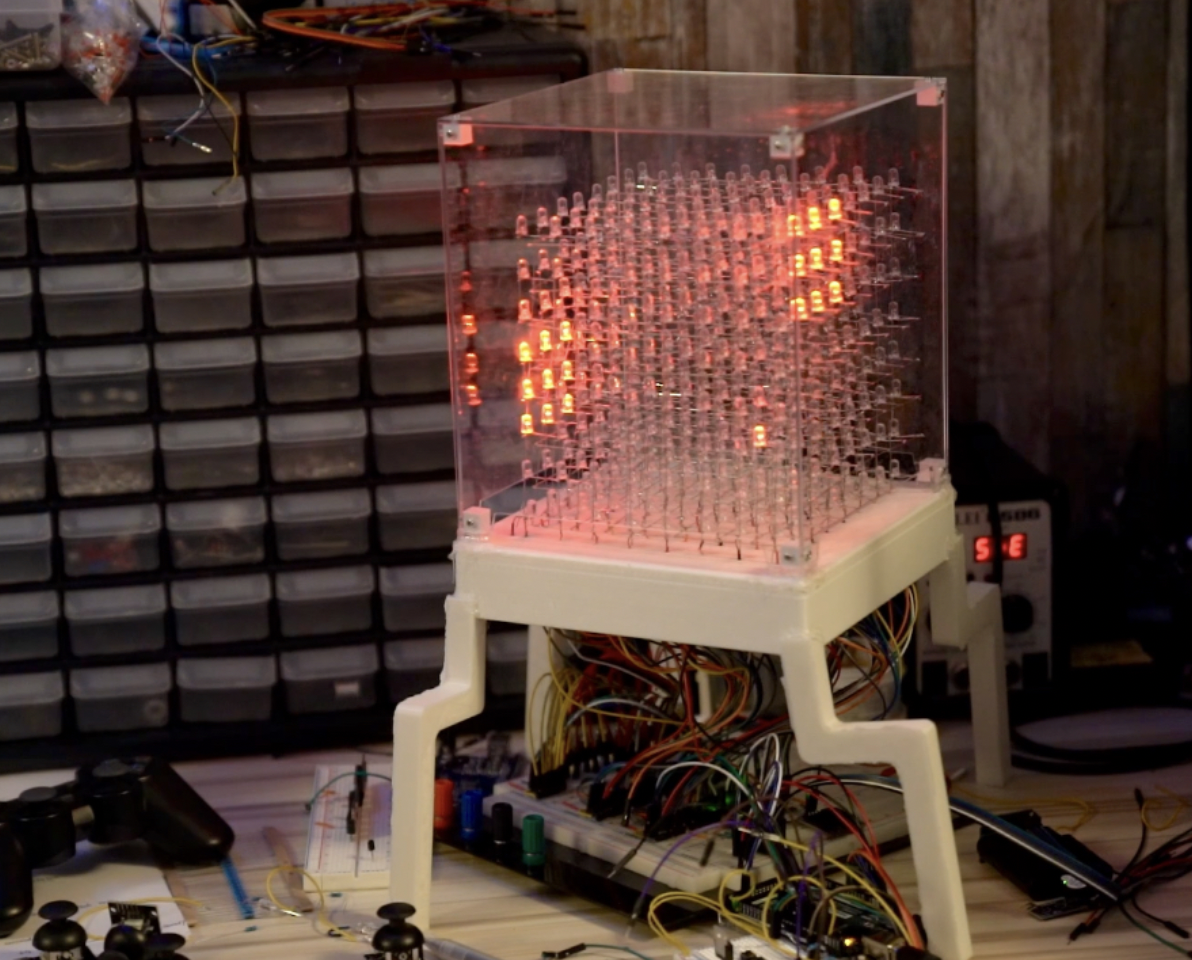
MABEL, an open-source anthropomorphic mobile bimanual robot (paper Figure 1) Open hardware 2026 MABEL: Open Mobile Bimanual Robot Open-source (MIT) whole-body robot: a 3-module holonomic swerve base, a 0.635 m lift with actuated torso, two 7-DOF arms, two 17-DOF ORCA hands, and a 3-DOF active head. 56 DOF from $8,722, with no machine shop. Teleoperated from Apple Vision Pro, iPhone, browser, or gamepad; full MuJoCo digital twin; demonstration-to-policy pipeline (ACT, Diffusion Policy, π0) deployed onboard. System paper under review. Quick look GeoDEX dexterous manipulation Robot learning 2026 GeoDEX: Diffusion Transformers for Dexterous Hands Diffusion-transformer policy for 26-DOF dexterous pick-and-place. Maps dual-view RGBD and proprioception to action chunks with SE(3) geometric regularization. Includes Vision Pro-based human retargeting in MuJoCo. Quick look TINTIN lunar landing RL Reinforcement learning 2025 TINTIN: RL-Based Lunar Rocket Landing 6-DoF variable-mass lander in MuJoCo with 2-DoF gimbaled thrust; PID baseline vs PPO policy; pose-targeted touchdown and fuel-efficiency metrics. Quick look Stair point-cloud profile with fitted tread and riser planes Perception 2024 Monocular Depth Estimation for Human-Robot Locomotion Monocular depth pipeline for human-robot walking environments: Metric3D v2 fine-tuned on 16,780 RGB-D stair images, metric reprojection to 3D point clouds, and plane extraction for stair rise and run. Re-run in 2026 on the archived scenes: 1.7 cm rise / 2.5 cm run mean error against a tape measure. Quick look CLEAR-Net cart-pole reinforcement learning Reinforcement learning 2024 CLEAR-Net: Noise-Robust Cart-Pole RL Compared tabular Q-learning, DQN, PPO, and SAC on noisy Cart-Pole; designed noise-robust wrappers, tuned hyperparameters, and analyzed robustness under disturbances and varying noise levels. Quick look Five-link biped with knees walking under virtual holonomic constraints Perception + Control 2024 BipedNav: see the stairs once, then walk Monocular stair/obstacle geometry from one image feeds a five-link biped with knees walking by virtual holonomic constraints (hybrid limit cycles, verified against their return maps). From one view of an obstacle the planner schedules the approach and two step-over gaits chained through the impact map. Includes the re-test of the two-link ECE1658 design and an in-browser demo. Quick look Aerospace vehicle localization State estimation 2023 Localization for Aerospace Vehicles (IMU + Stereo) Batch Gauss-Newton fusion with EKF; compared batch vs sliding-window estimators for trajectory accuracy. Quick look Arduino mobile robot Mechatronics 2023 Mobile Robot Mechatronics Design Project MATLAB, SolidWorks — Designed a 3D-printed Arduino-based mobile robot in Fusion 360; implemented localization and obstacle-avoidance for maze navigation in MATLAB; commanded the robot via Bluetooth. Quick look 8x8x8 LED cube Embedded 2022 8×8×8 LED Cube Embedded System ESP32-based driver with SPI multiplexing; API control; interactive 3D Snake and Pong demos. Quick look Turtlebot2 SLAM and navigation SLAM 2022 Turtlebot2 SLAM, Navigation & Perception Gmapping, frontier exploration, PID control; OpenCV perception and a CNN for 7-class emotion recognition. Quick look Formula racing car drivetrain Mechanical design 2022 Electric Formula Racing Car Drive-train Planetary gearbox quadrupling torque at >90% efficiency; kinematics, stress, thermal, and vibration analyses. Quick look

News

[09/2026] Transferring my Ph.D. to the University of Toronto to work with Prof. Jonathan Kelly at the STARS Laboratory (UTIAS) — building dexterous manipulation on the road to solving robotics.

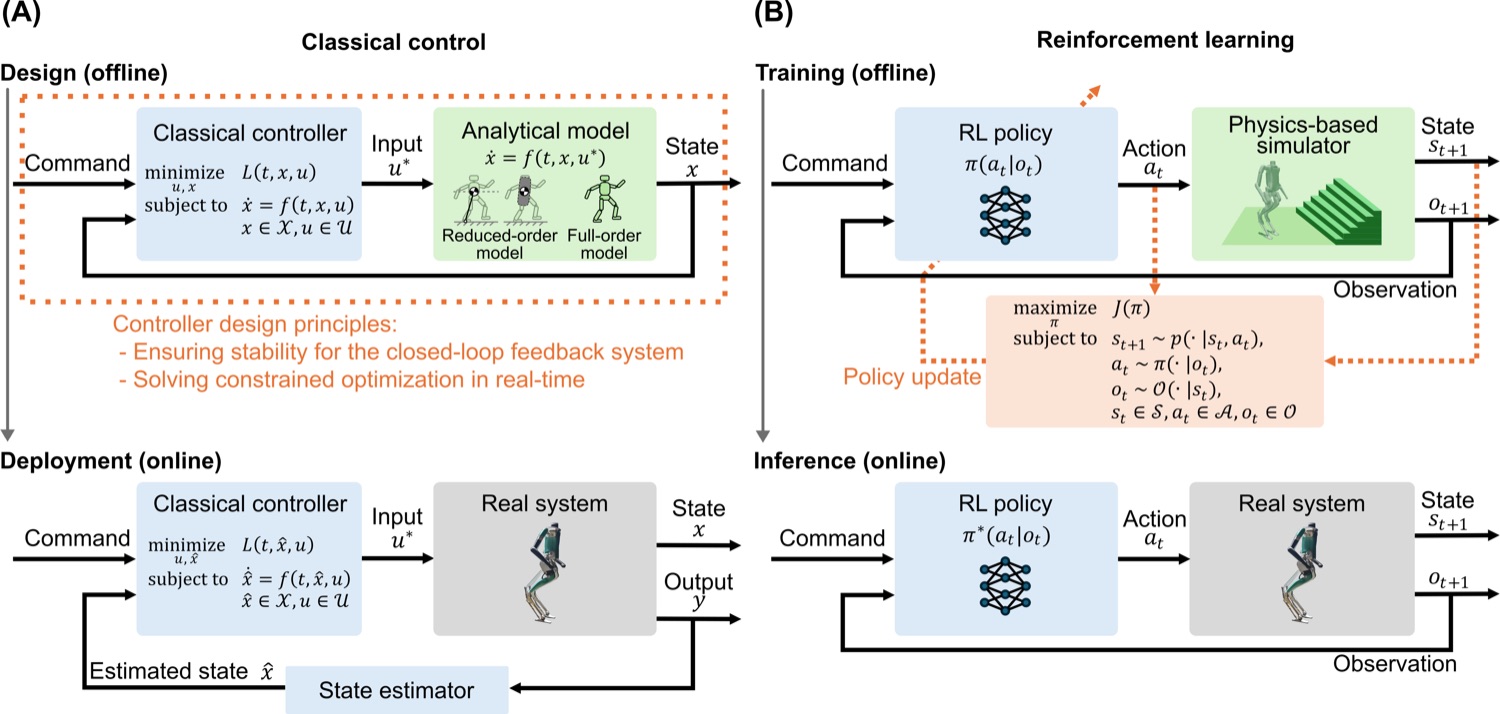
[08/2026] Our review “Evolution of Humanoid Locomotion Control” was published in Science Robotics (Vol. 11, Issue 117) — from classical control through learning to foundation and world models. Reading list on GitHub.

[05/2026] Our paper IRIS was accepted to CRV 2026 (Conference on Robots and Vision) — I attended and gave an oral presentation at Simon Fraser University, Vancouver.

[11/2025] Graduated with a Master of Engineering (MEng) in Electrical & Computer Engineering (ECE) at the University of Toronto.

[10/2025] Attended IROS 2025 in Hangzhou, China and presented “AeroHaptix”.

[09/2025] Started my Ph.D. in Mechanical Engineering at New York University, joining Prof. Ludovic Righetti's Machines in Motion Lab — working with Ludovic and Katsuo.

[07/2025] Our paper on certifiably correct robot–world & hand-eye calibration was accepted to the International Journal of Robotics Research (IJRR).

[04/2025] Attended CHI 2025 in Yokohama, Japan and presented “VibraForge”.

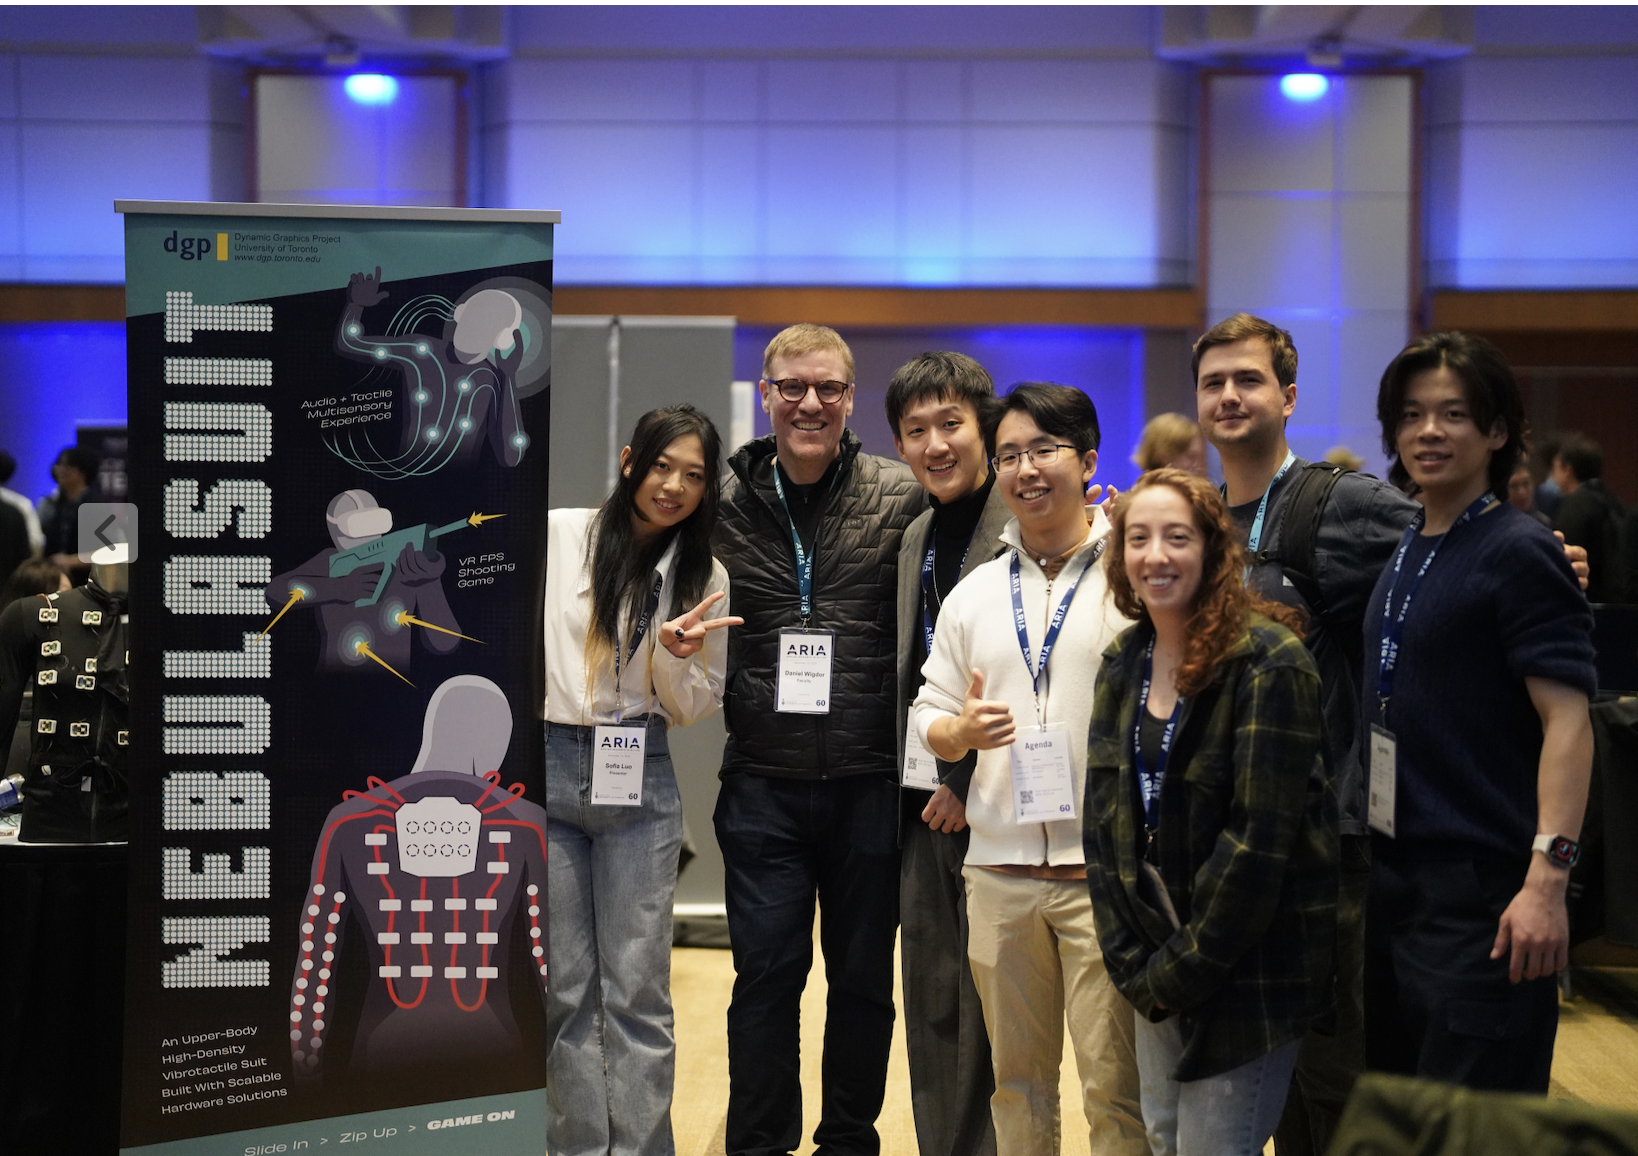
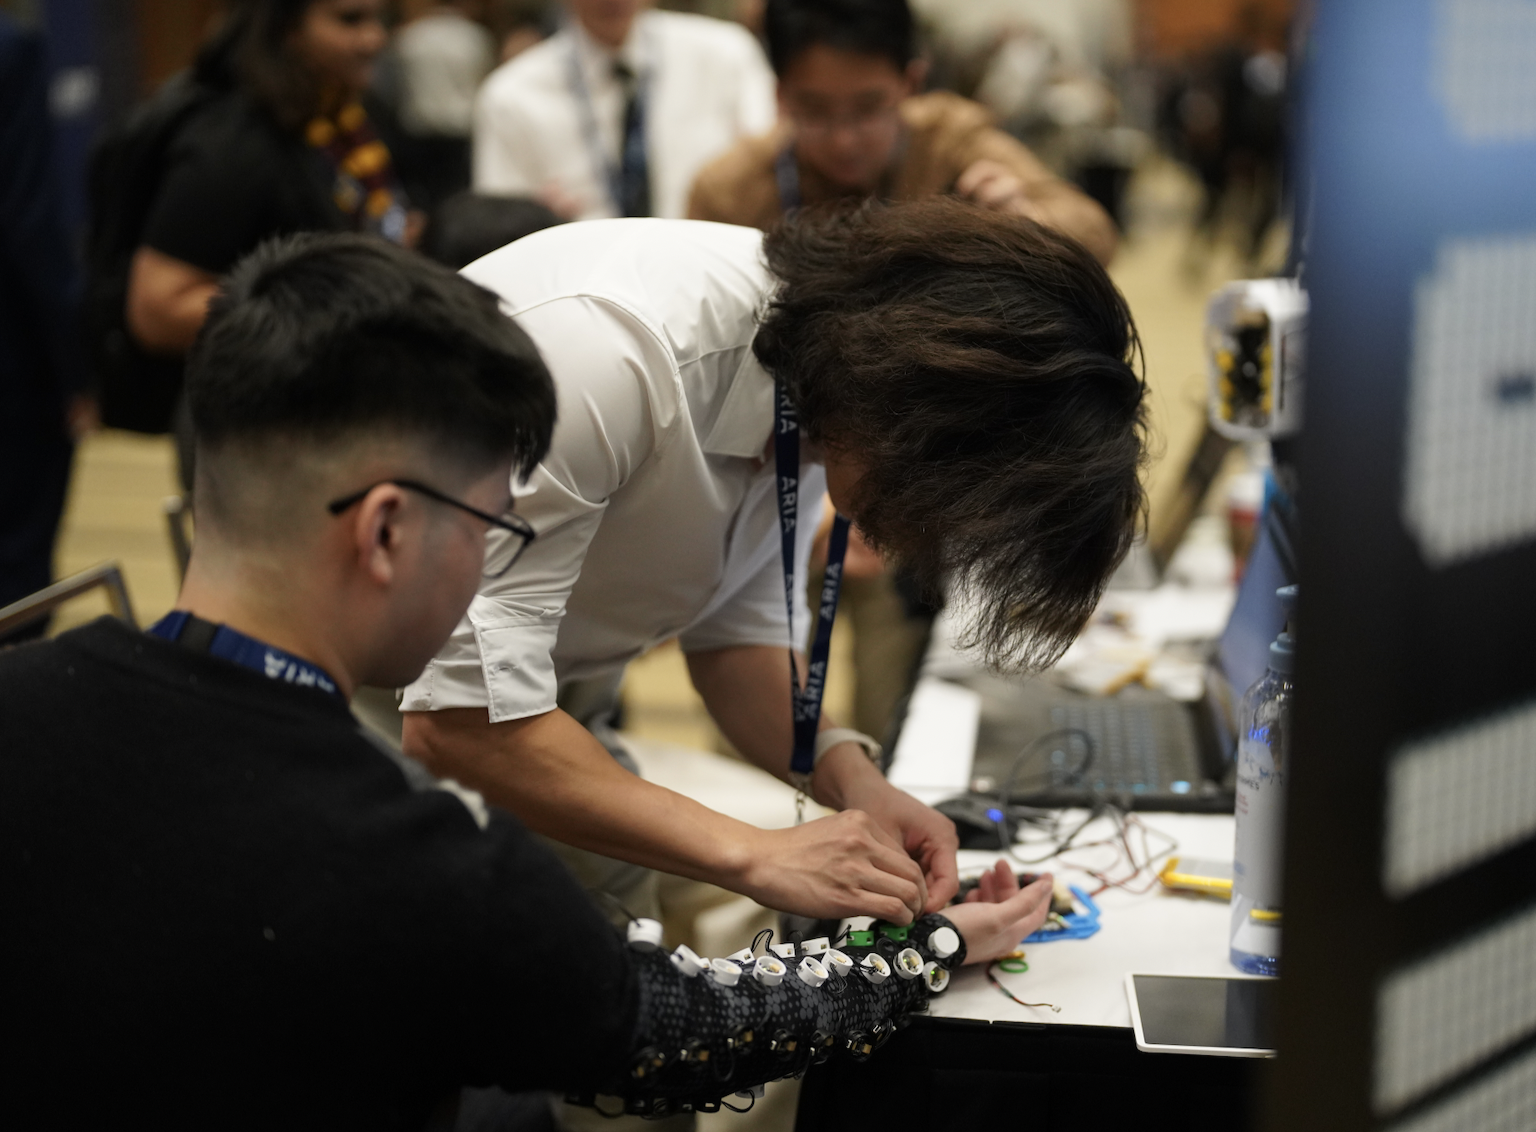
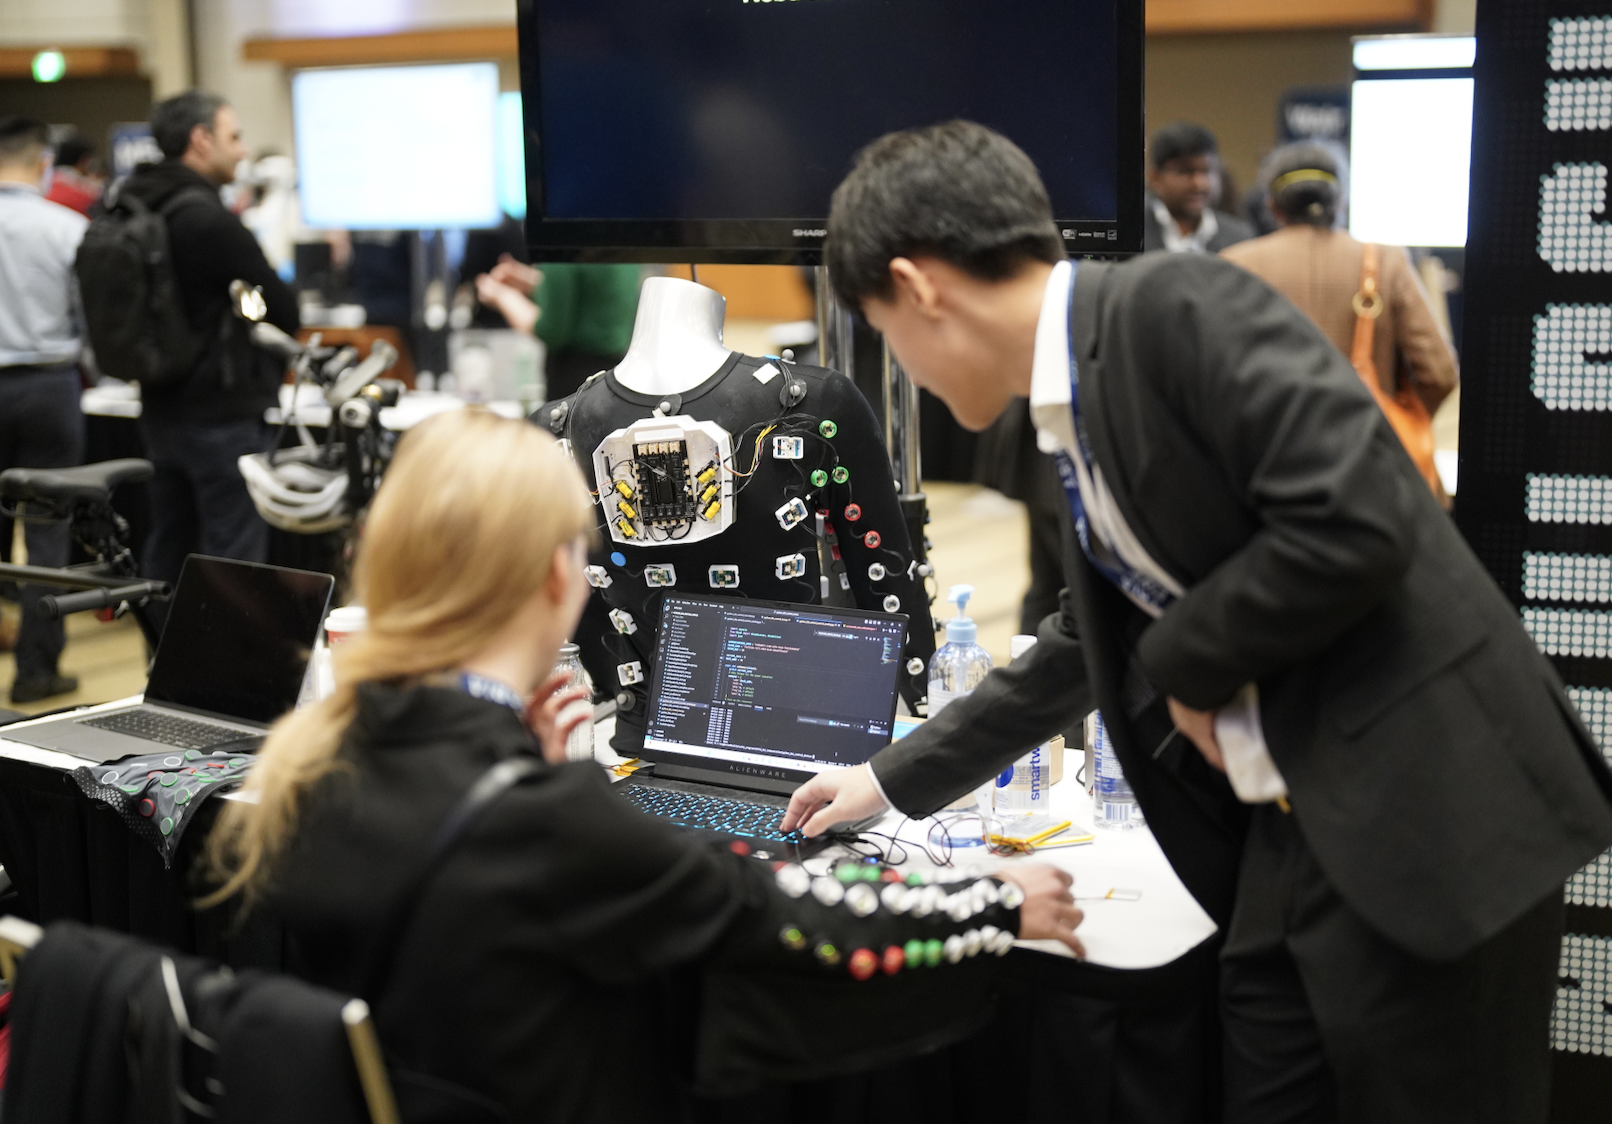
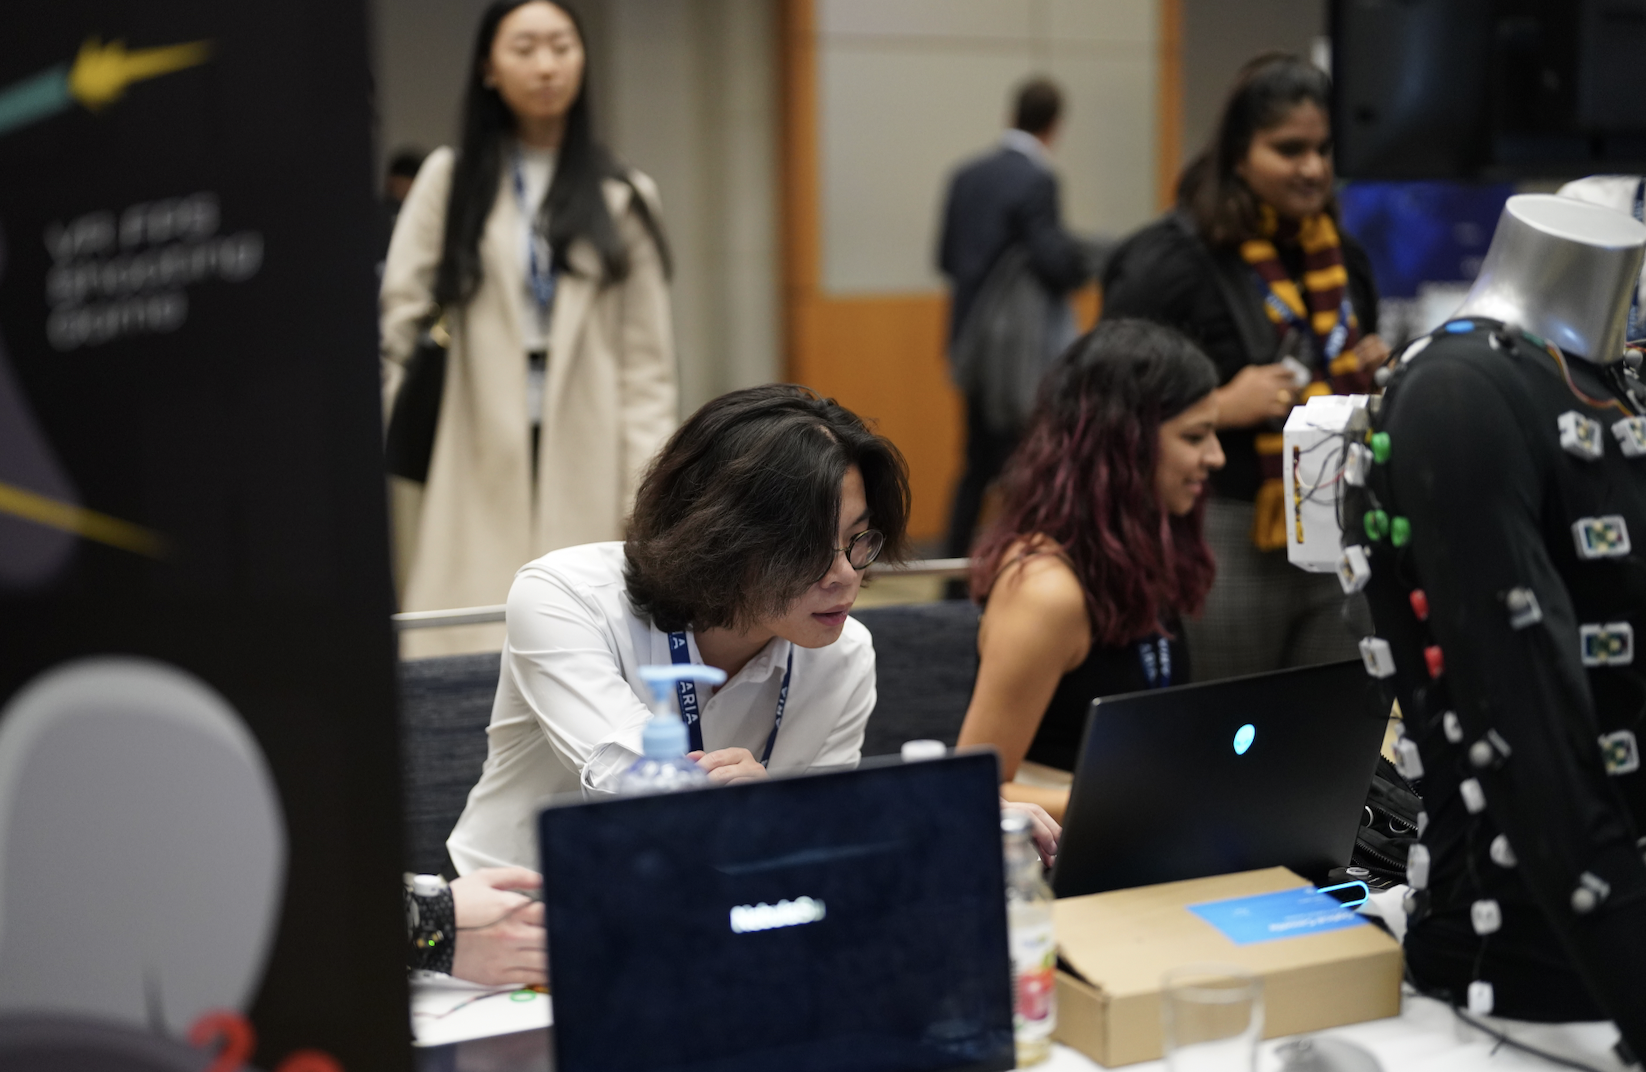
[11/2024] Presented at ARIA 2024 in Toronto with our VibraForge toolkits.

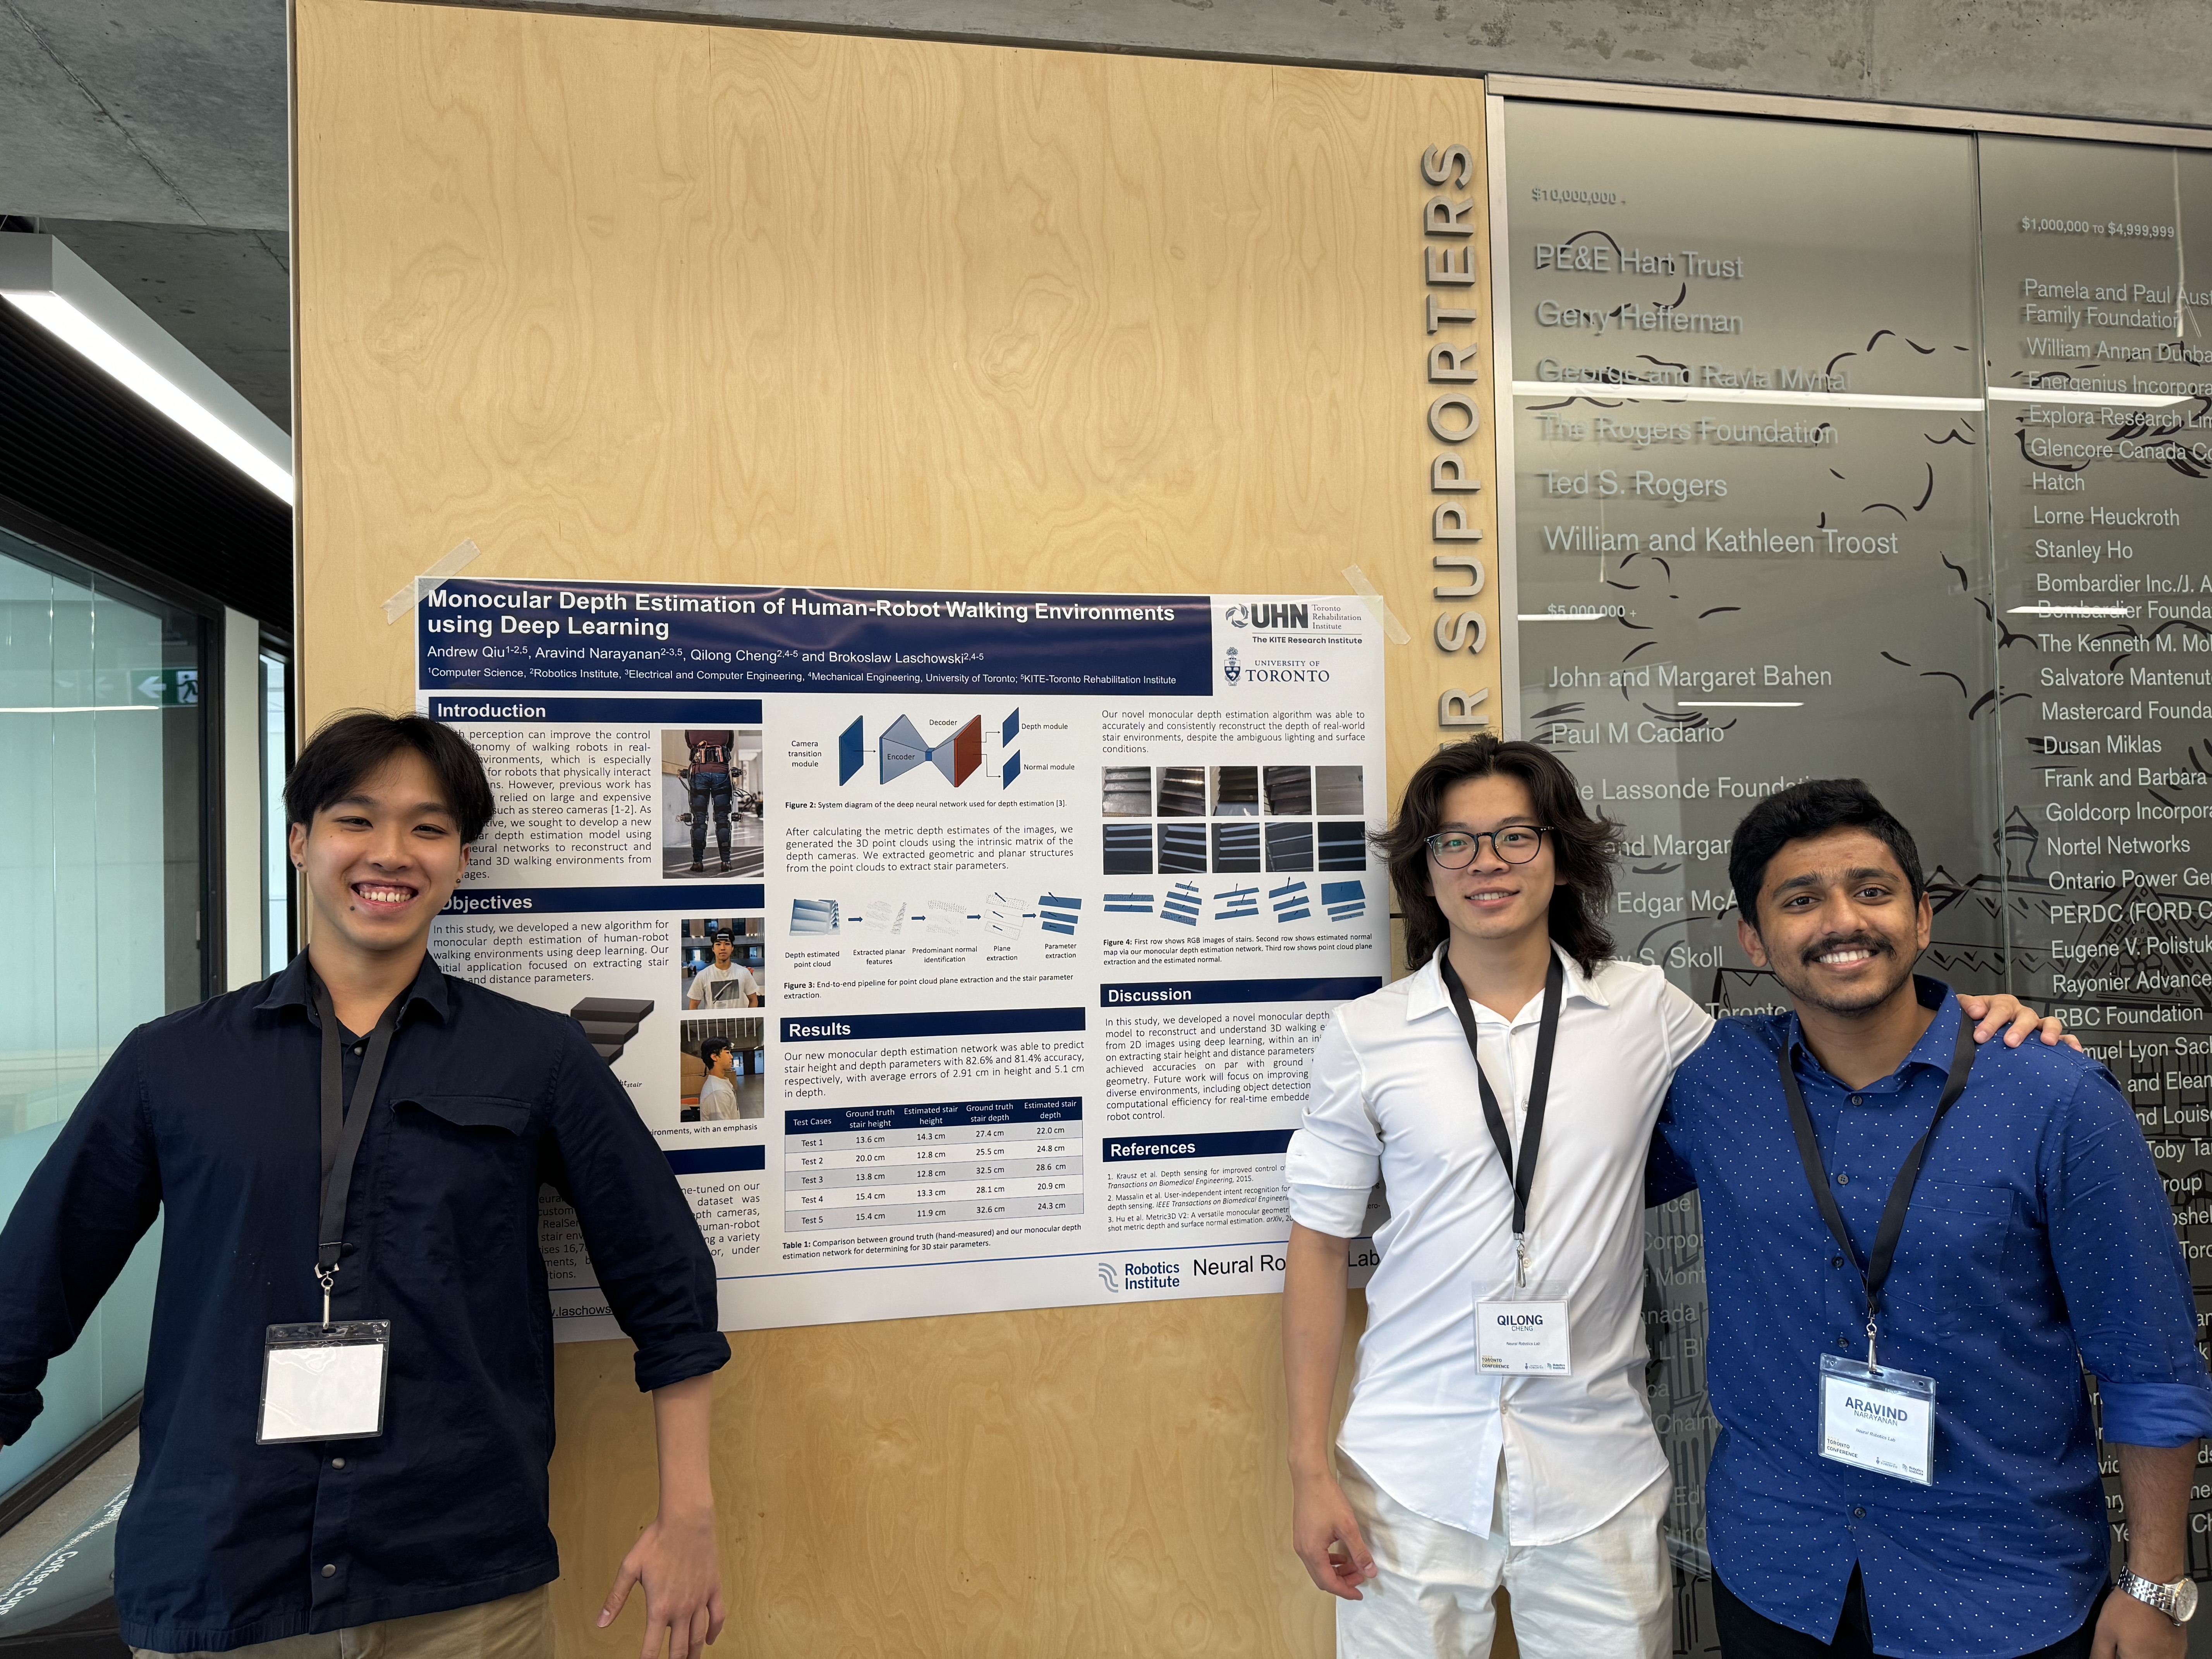
[07/2024] Presented monocular depth estimation work at the Toronto Robotics Conference 2024.

[11/2023] Demonstrated “VibraForge” at ARIA 2023 in Toronto.

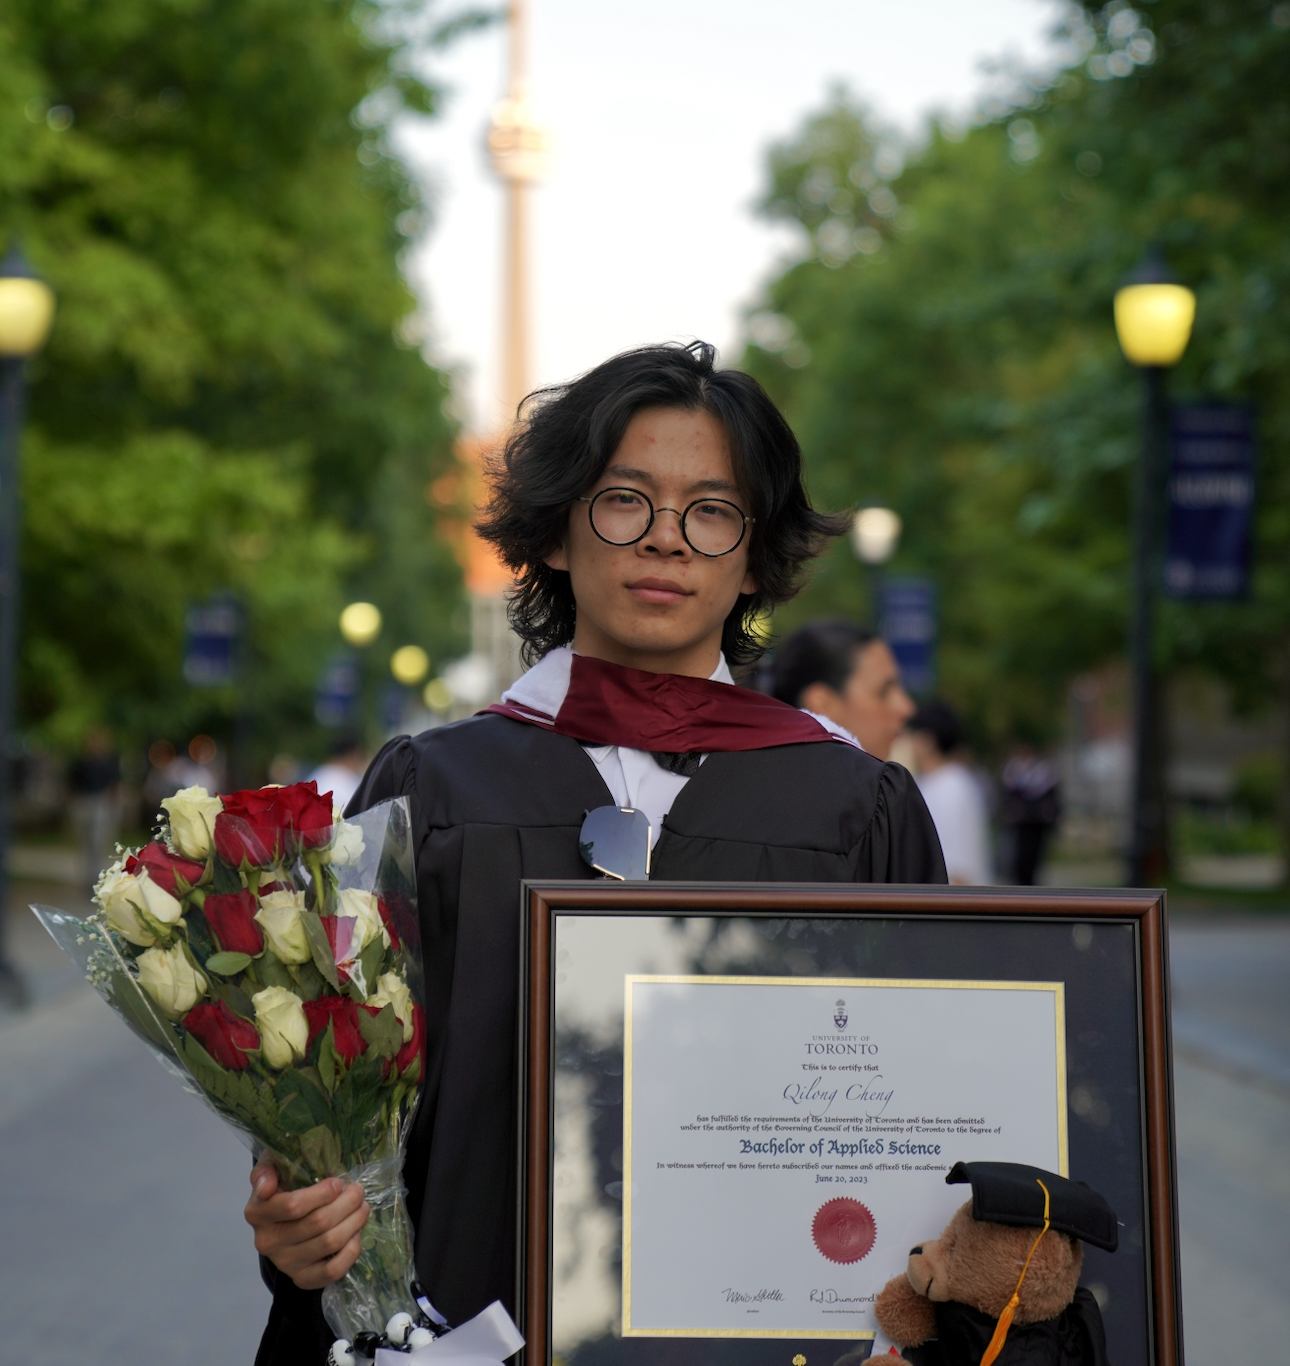
[06/2023] Graduated from the University of Toronto with a Bachelor of Applied Science (BASc) in Mechanical Engineering — mechatronics & robotics focus.

Coffee Chat

I'm always open to chatting about Robotics, Research, Startups, or just connecting! Feel free to grab a time on my calendar below.

Location: Any Cafe with Enough Clearance for a 6-DOF Robot Arm

Schedule a Coffee
Total Visitor Analytics